OrcaHand v2.1 Base
ORCA Dexterity OrcaHand v2.1 Base is a robot hand from Switzerland, first released 2026.
Sources retrieved: 19 November 2026 (A, B)
- Status
- In production
- Applications
- Intended use, per the manufacturer
- “We are already supporting labs across four continents for research in dexterous manipulation.”Source and note: Intended use, per the manufacturerB orcahand.com · Retrieved 19 November 2026
- Indicative price
- at least 3,500USDSource and note: Indicative priceB orcahand.com · Retrieved 19 November 2026
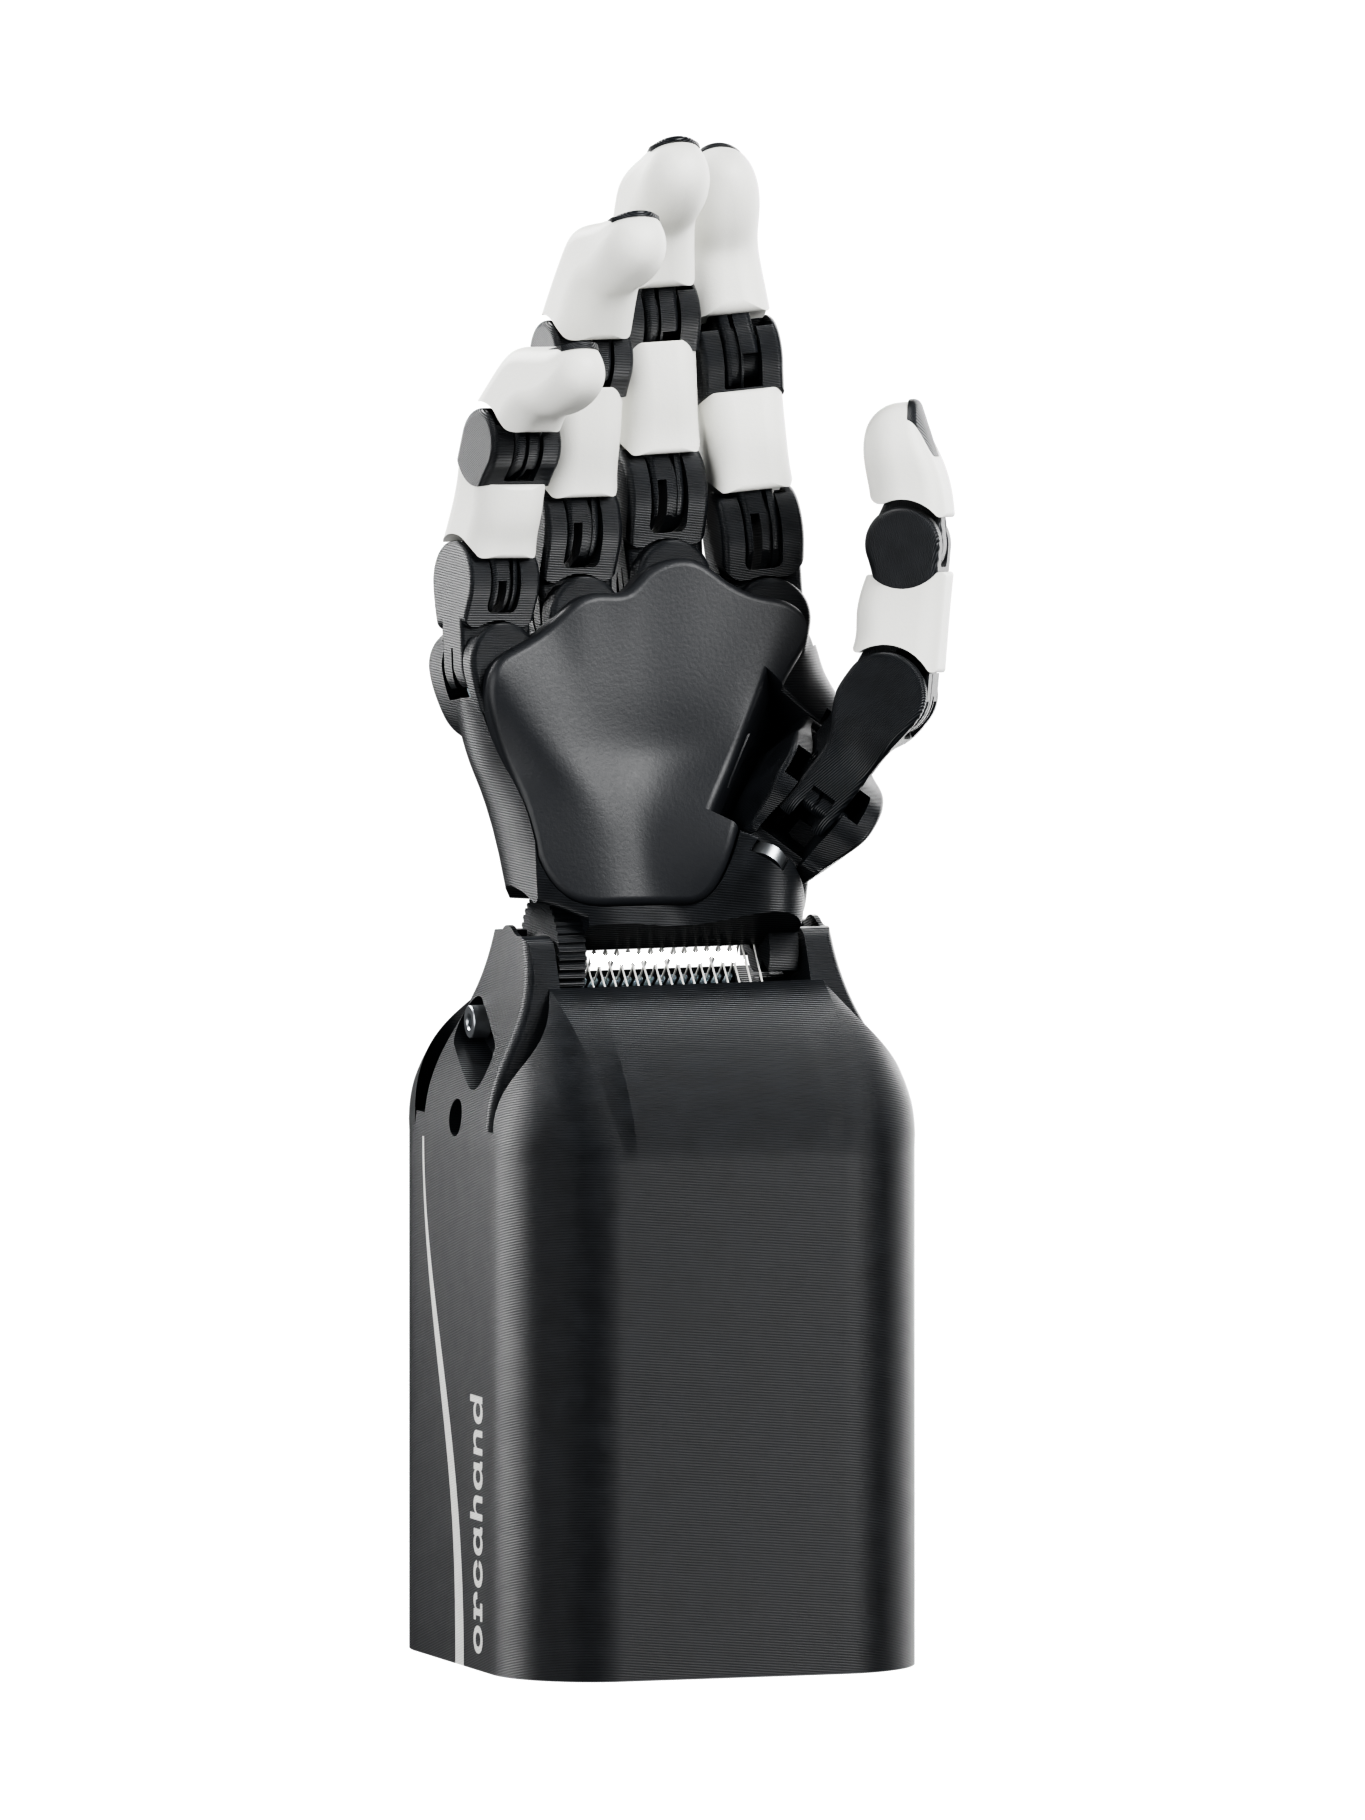
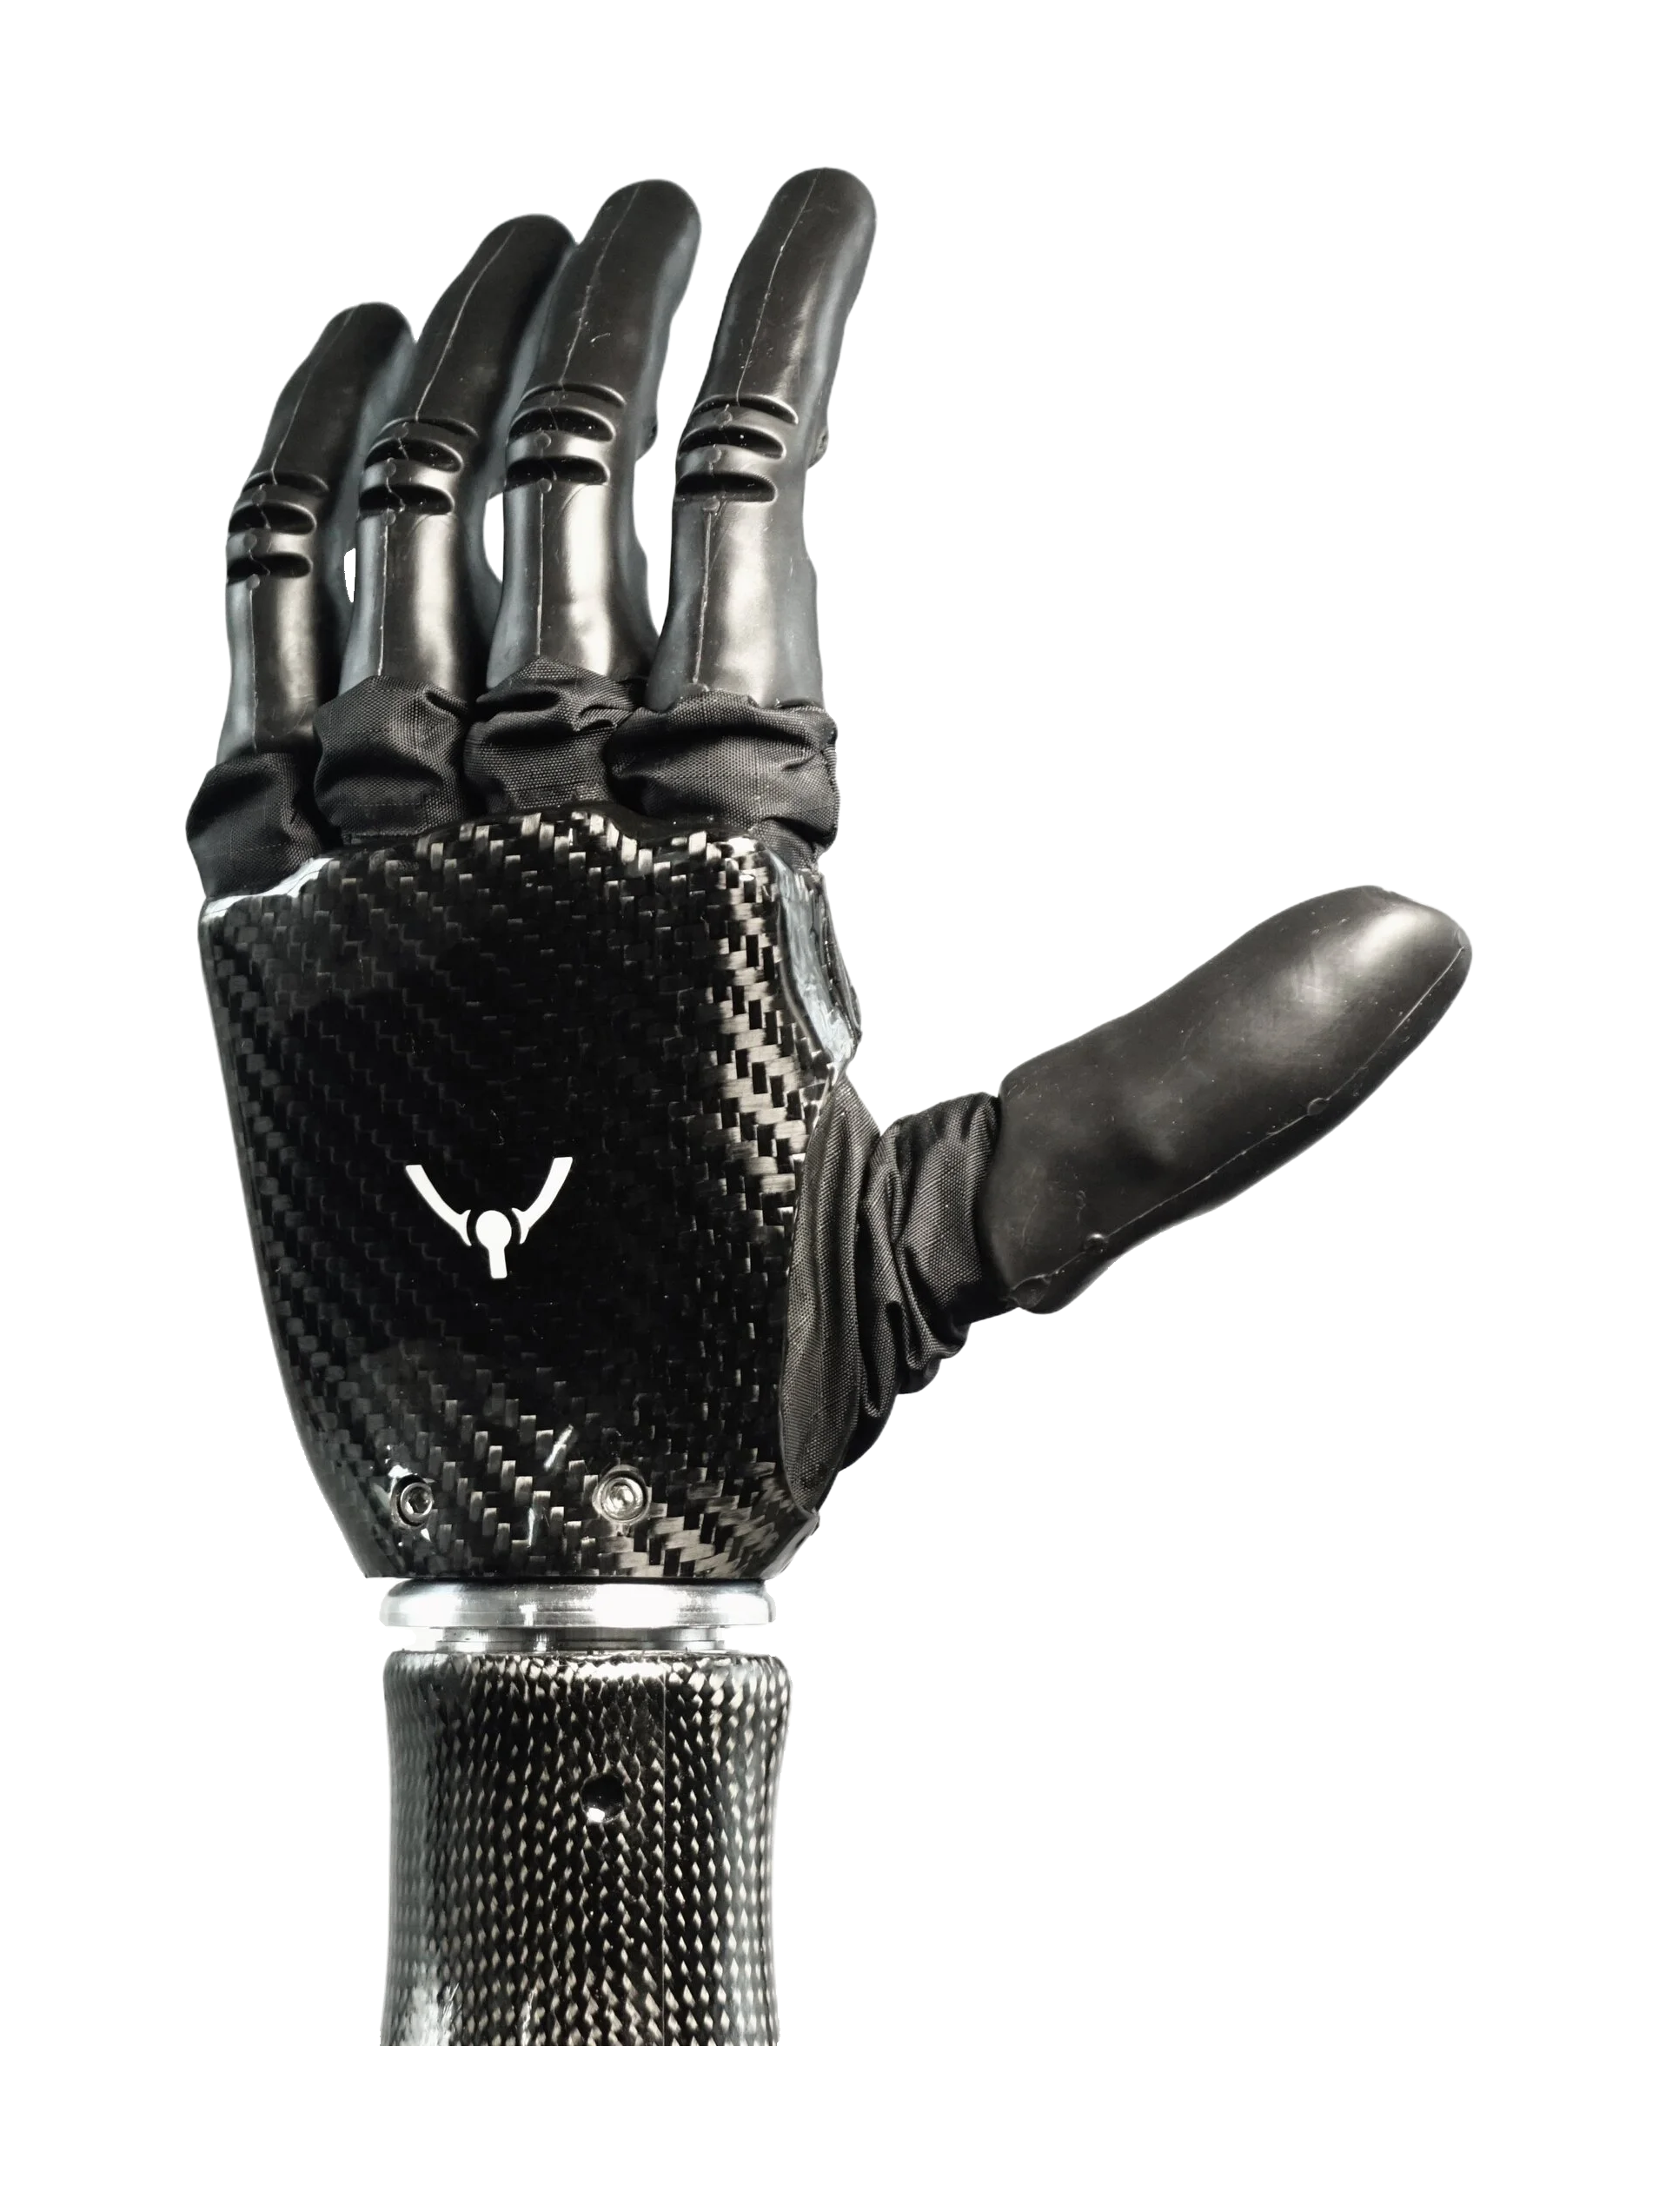
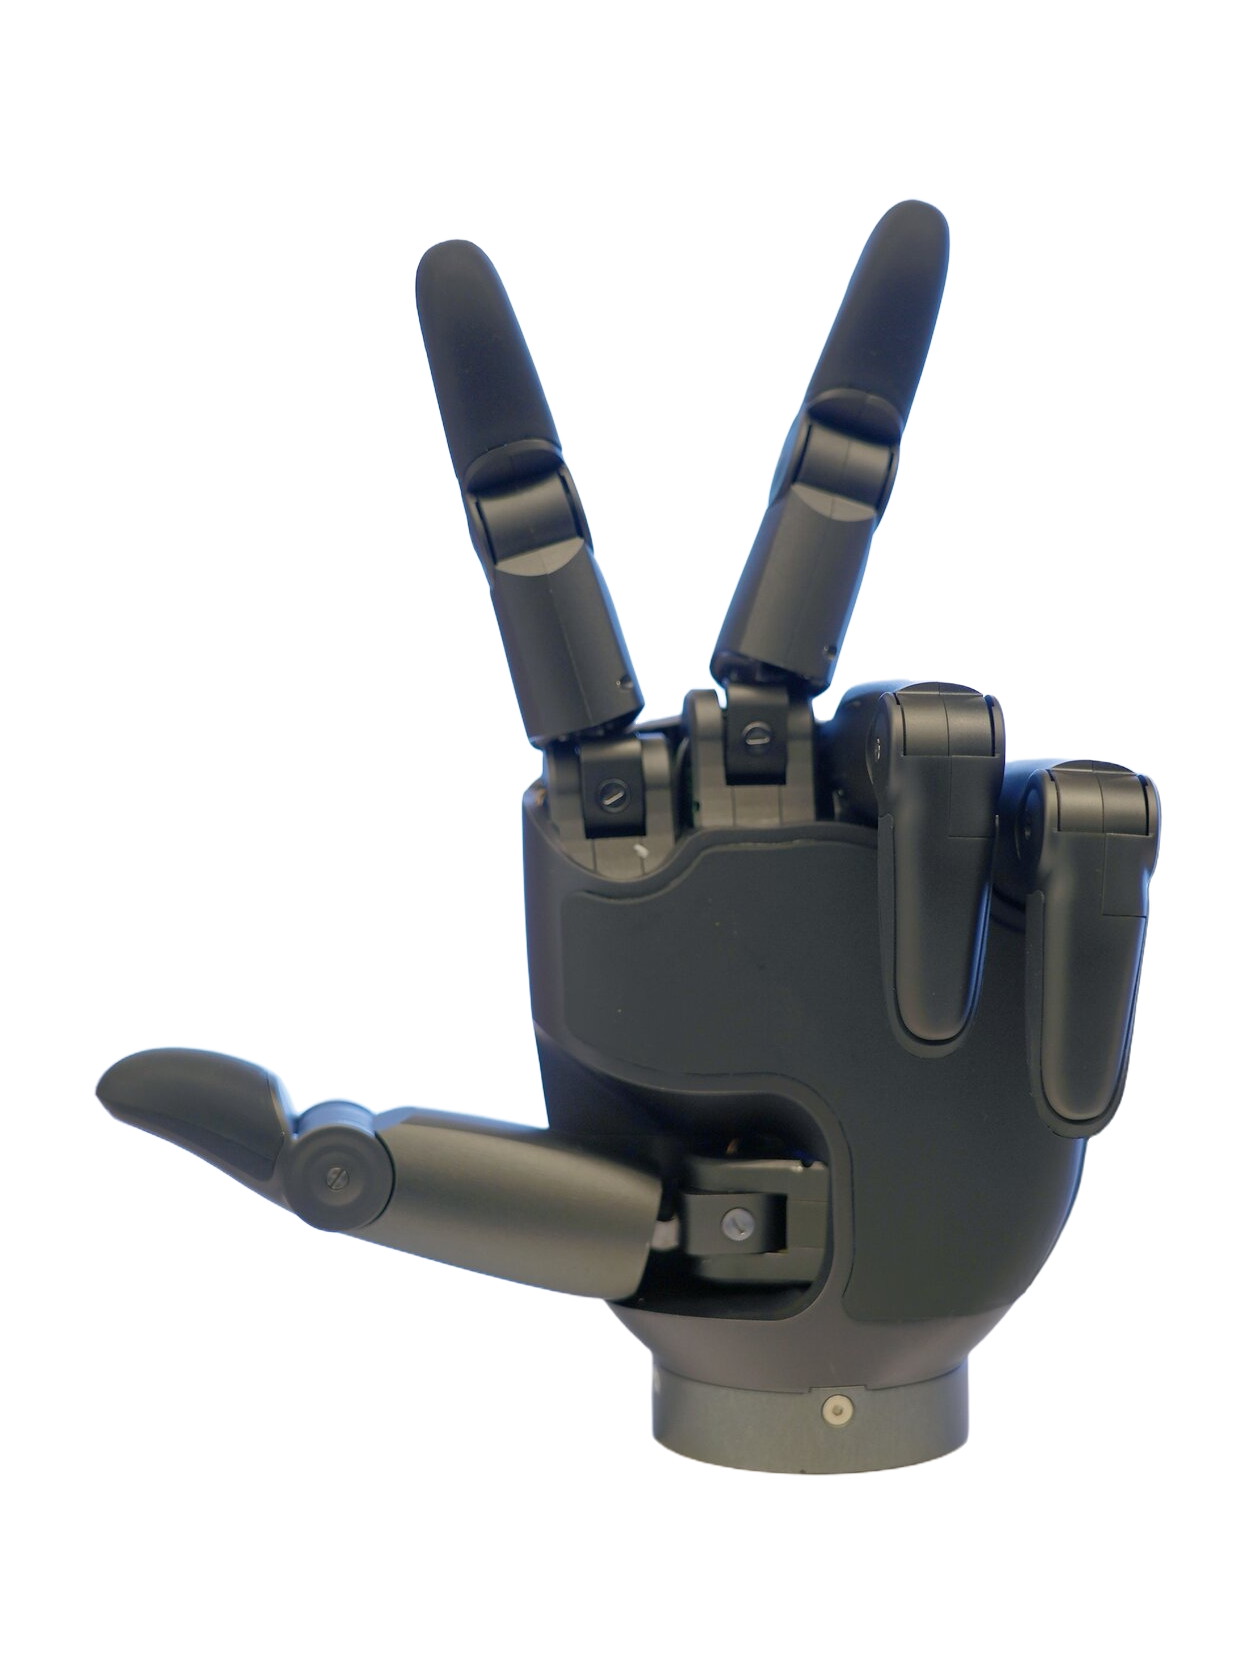
Manufacturer's own photo. Press photo: ORCA Dexterity (orcahand.com), OrcaHand product image.
Specifications
8 of 18 stated 10 not stated
10 fields hidden
How to read the figuresShow guideClose
- not statedNo source
- noStated by a source
- 0Reported as zero
- ASource
- A*Source with a caveat (select it)
- CERecords only what the manufacturer states regarding CE marking.
Select a source marker for source details and notes.
The hand2/4 disclosed
Performance1/4 disclosed
Physical2/2 disclosed
Sensing and connectivity2/3 disclosed
Commercial1/1 disclosed
Compliance & certifications0/4 disclosed
Against the field
Each strip holds every robot of this type in the guide that states the figure, one bar per group of values. Further right means a larger figure, not a better robot. A taller bar means more robots in that group.
Weight
1.3kg2.87lbOur conversion from 1.3 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
62 robot hands state a weight
5 state a higher figure, 51 a lower one. 1 more states exactly the same figure. 4 state only a bound (≥ or ≤) and are not ranked. Log scale: each step along the axis multiplies the value.
Active degrees of freedom
17DoF
69 robot hands state degrees of freedom
21 state a higher figure, 44 a lower one. 3 more state exactly the same figure.
Indicative price
at least 3,500USD
27 robot hands state a public price
OrcaHand v2.1 Base states a lower limit, not one figure, so it is shown open-ended and not ranked against the others. 1 states only a bound (≥ or ≤) and is not ranked. Log scale: each step along the axis multiplies the value.
Notes
ORCA Dexterity lists v2.1 as now shipping in left and right configurations with Dynamixel or Feetech servos.
Conceptuel (16 March 2026) reports that the ORCA Hand was open-sourced by ETH Zurich's Soft Robotics Lab.
Sources
One line per source, not per figure: a source has one retrieval date.
- Aorcahand.com/docs/orcahand-v2.1-base-datasheet.pdfSecondary. Retrieved 19 November 2026
- Borcahand.comMain source. Retrieved 19 November 2026
More robots
Same manufacturer
All robots from ORCA Dexterity