NVIDIA · robot AI model
Long-WAM
United States · 2026
Runs on G1 by Unitree RoboticsSource and note: G1B arxiv.org/abs/2610.10528 · Retrieved 19 November 2026
Sources retrieved: 19 November 2026 (A, B, C)
- Model type
- World action modelSource and note: Model typeB arxiv.org/abs/2610.10528 · Retrieved 19 November 2026Note. “We present Long-WAM, a model-system framework for scaling the context of causal world-action models under real-time control constraints.”
- What it controls
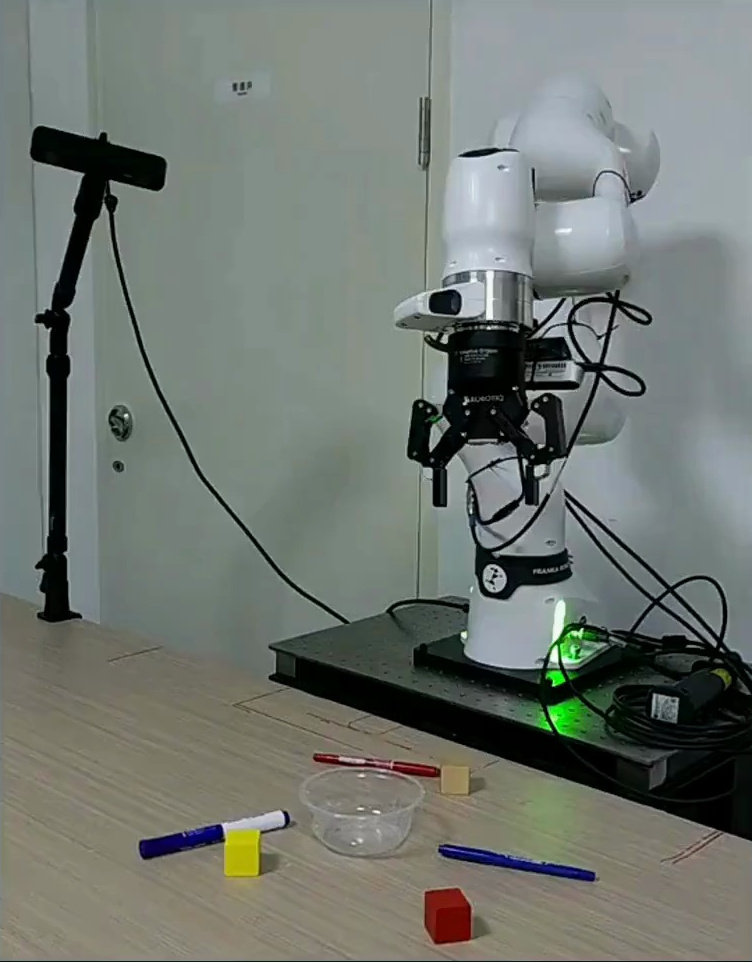
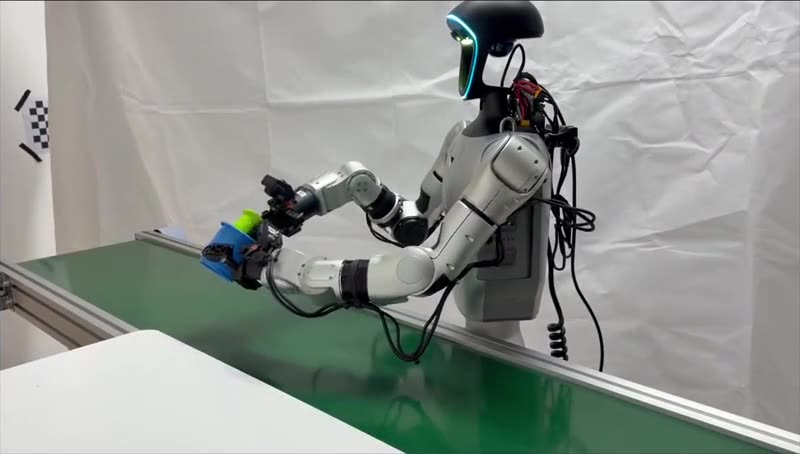
- Arms and handsSource and note: What it controlsB arxiv.org/abs/2610.10528 · Retrieved 19 November 2026Note. “Real-time deployment on Unitree G1 and YAM supports dynamic and long-horizon manipulation”. “Generate two future-video latents using 4 steps (imagination sigma 0.9), then predict a 32-step action chunk using 10 action steps.”
- Inputs
- CameraSource and note: InputsA nvlabs.github.io/LongLive/Long-WAM/ · Retrieved 19 November 2026Note. Processes “Observed video history”: “P48 context uses 48 past control steps plus the current observation: **2.4 seconds at 20 Hz**, encoded into four clean latent frames.”
- Access
- Open weights (download)Source and note: AccessC huggingface.co/Efficient-Large-Model/Long-WAM-RoboCasa365 · Retrieved 19 November 2026Note. “Long-WAM policy weights for RoboCasa365.”
- Base model
- LongLive2.0-RobotSource and note: Base modelA nvlabs.github.io/LongLive/Long-WAM/ · Retrieved 19 November 2026Note. Video expert is “initialized from LongLive2.0-Robot”.
Specifications
8 of 14 stated 6 not stated
4 fields hidden 2 not-stated fields with a note stay ·
How to read the figuresShow guideClose
- not statedNo source
- yesStated by a source
- 0Reported as zero
- ASource
Select a source marker for source details and notes.
Release1/1 disclosed
Released7 October 2026
Source and note: ReleasedB arxiv.org/abs/2610.10528 · Retrieved 19 November 2026Note. arXiv submission date: “Submitted on 7 Oct 2026”.
Input and output3/4 disclosed
Model typeWorld action model
Source and note: Model typeB arxiv.org/abs/2610.10528 · Retrieved 19 November 2026Note. “We present Long-WAM, a model-system framework for scaling the context of causal world-action models under real-time control constraints.”
InputsCamera
Source and note: InputsA nvlabs.github.io/LongLive/Long-WAM/ · Retrieved 19 November 2026Note. Processes “Observed video history”: “P48 context uses 48 past control steps plus the current observation: **2.4 seconds at 20 Hz**, encoded into four clean latent frames.”
What it controlsArms and hands
Source and note: What it controlsB arxiv.org/abs/2610.10528 · Retrieved 19 November 2026Note. “Real-time deployment on Unitree G1 and YAM supports dynamic and long-horizon manipulation”. “Generate two future-video latents using 4 steps (imagination sigma 0.9), then predict a 32-step action chunk using 10 action steps.”
Degrees of freedom controlledNot stated
Size and speed1/2 disclosed
ParametersNot stated
Control rate20Hz
Source and note: Control rateC huggingface.co/Efficient-Large-Model/Long-WAM-RoboCasa365 · Retrieved 19 November 2026Note. Control-step rate for P48 context: “P48 context uses 48 past control steps plus the current observation: **2.4 seconds at 20 Hz**, encoded into four clean latent frames.”
Where it runs and what it is built on1/2 disclosed
On robot or cloudNot stated
Source and note: On robot or cloudB arxiv.org/abs/2610.10528 · Retrieved 19 November 2026Note. “Streaming observation encoding, asynchronous execution, and hardware-specific acceleration enable deployment on RTX 5090, DGX Spark, and Jetson AGX Thor without dropping future prediction; on RTX 5090, each action chunk, including future-video latent prediction, takes 107.4 ms.”
Base modelLongLive2.0-Robot
Source and note: Base modelA nvlabs.github.io/LongLive/Long-WAM/ · Retrieved 19 November 2026Note. Video expert is “initialized from LongLive2.0-Robot”.
Openness1/3 disclosed
AccessOpen weights (download)
Source and note: AccessC huggingface.co/Efficient-Large-Model/Long-WAM-RoboCasa365 · Retrieved 19 November 2026Note. “Long-WAM policy weights for RoboCasa365.”
Licence documentNot stated
Source and note: Licence documentC huggingface.co/Efficient-Large-Model/Long-WAM-RoboCasa365 · Retrieved 19 November 2026Note. Hugging Face model card header lists “license: other” without naming a specific license.
Licence typeNot stated
The developer’s own claims1/2 disclosed
Learns new tasksNot stated
Works across robotsYes
Source and note: Works across robotsB arxiv.org/abs/2610.10528 · Retrieved 19 November 2026Note. “Real-time deployment on Unitree G1 and YAM supports dynamic and long-horizon manipulation”Yes only if the developer itself says the model runs on different robot models, for example robots from two manufacturers or two of one manufacturer’s models. Several units of the same robot do not count.
Notes
Developed by researchers from NVIDIA, MIT, HKU, and UCSD.
Described by the authors as “We present Long-WAM, a model-system framework for scaling the context of causal world-action models under real-time control constraints.”
Sources
One line per source, not per figure: a source has one retrieval date.
- Anvlabs.github.io/LongLive/Long-WAM/Main source. Retrieved 19 November 2026
- Barxiv.org/abs/2610.10528Retrieved 19 November 2026
- Chuggingface.co/Efficient-Large-Model/Long-WAM-RoboCasa365Retrieved 19 November 2026
More models
Same developer
Cosmos 3NVIDIA
Cosmos PolicyNVIDIA
Cosmos Reason 2NVIDIA
- No photograph
DreamDojoNVIDIA
DreamZeroNVIDIA
- No photograph
GR00T 2NVIDIA