Linker Hand L20 Lite
A robot hand from China.
Sources retrieved: 4 November 2026 (A, B)
- Status
- In production
- Applications
- Intended use, per the manufacturer
- Simulates human hand fine operations such as precise gripping and flexible pinching, suitable for research and industrial scenarios requiring high precision.Source and note: Intended use, per the manufacturerA linkerbot.cn/details/LinkerHandL20Lite · Retrieved 4 November 2026
- Indicative price
- Not stated
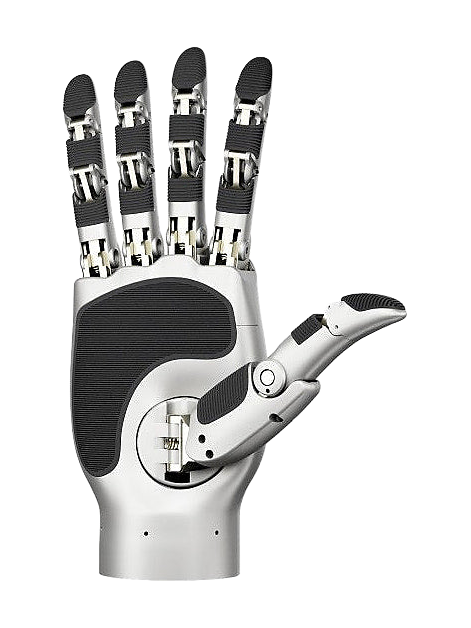
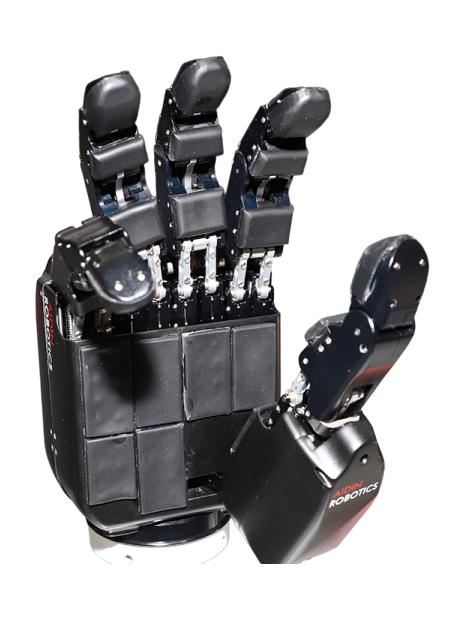
Product image from a reseller's page (openelab.io), not the manufacturer's own site.
Specifications
8 of 18 stated 10 not stated
10 fields hidden
How to read the figuresShow guideClose
- not statedNo source
- noStated by a source
- 0Reported as zero
- ASource
- A*Source with a caveat (select it)
- CERecords only what the manufacturer states regarding CE marking.
Select a source marker for source details and notes.
The hand3/4 disclosed
Performance3/4 disclosed
Physical2/2 disclosed
Sensing and autonomy0/3 disclosed
Commercial0/1 disclosed
Compliance & certifications0/4 disclosed
Against the field
Each strip holds every robot of this type in the guide that states the figure, one bar per group of values. Further right means a larger figure, not a better robot. A taller bar means more robots in that group.
Fingertip force
15N
38 robot hands state a fingertip force
13 state a higher figure, 8 a lower one. 4 more state exactly the same figure. 12 state only a bound (≥ or ≤) and are not ranked. DG-5F-M lies beyond the end of the axis and is drawn at its edge as an open bar.
Lifting capacity
25kg55.1lbOur conversion from 25 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
48 robot hands state a lifting capacity
12 state a higher figure, 26 a lower one. 2 more state exactly the same figure. 7 state only a bound (≥ or ≤) and are not ranked.
Weight
800g1.76lbOur conversion from 800 g. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
59 robot hands state a weight
24 state a higher figure, 29 a lower one. 1 more states exactly the same figure. 4 state only a bound (≥ or ≤) and are not ranked. Log scale: each step along the axis multiplies the value.
Active degrees of freedom
10DoF
66 robot hands state degrees of freedom
40 state a higher figure, 24 a lower one. 1 more states exactly the same figure.
Notes
Linkerbot's support FAQ, which covers the hand series in general, without naming a model, answers “How long does delivery and installation take?” with “7~15 working days.” and “What is the product warranty period?” with “1 year.”
The specification table gives the maximum five-finger grasp force: “Max Five-Finger Grasp Force. 80N.”
The specification table gives the repeat positioning accuracy “Repeat Positioning Accuracy. <±0.2mm.” and the opening and closing time “Open/Close Time. 1.2s.”
Sources
One line per source, not per figure: a source has one retrieval date.
- Alinkerbot.cn/details/LinkerHandL20LiteMain source. Retrieved 4 November 2026
- Blinkerbot.cn/supportRetrieved 4 November 2026
More robots
Same manufacturer
Linker Hand L20Linkerbot
Linker Hand L30 ProLinkerbot
Linker Hand L6Linkerbot
Linker Hand O30Linkerbot
Linker Hand O6Linkerbot
- No photograph
Linker Hand O20Linkerbot