Key figures as stated by the manufacturer
2 of 6 stated · 4 gaps- Weight not stated
- Payload, moving not stated
- Runtime not stated
- Max speed A 5.4km/h3.36mphOur conversion from 5.4 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- AI model BCB G0.5 LingBot-VLA G0Tiny
- Indicative price not stated
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Robots with several sources carry several letters.
- Payload, moving
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (1)
Max speed
Note Producer's own label is "chassis moving speed".
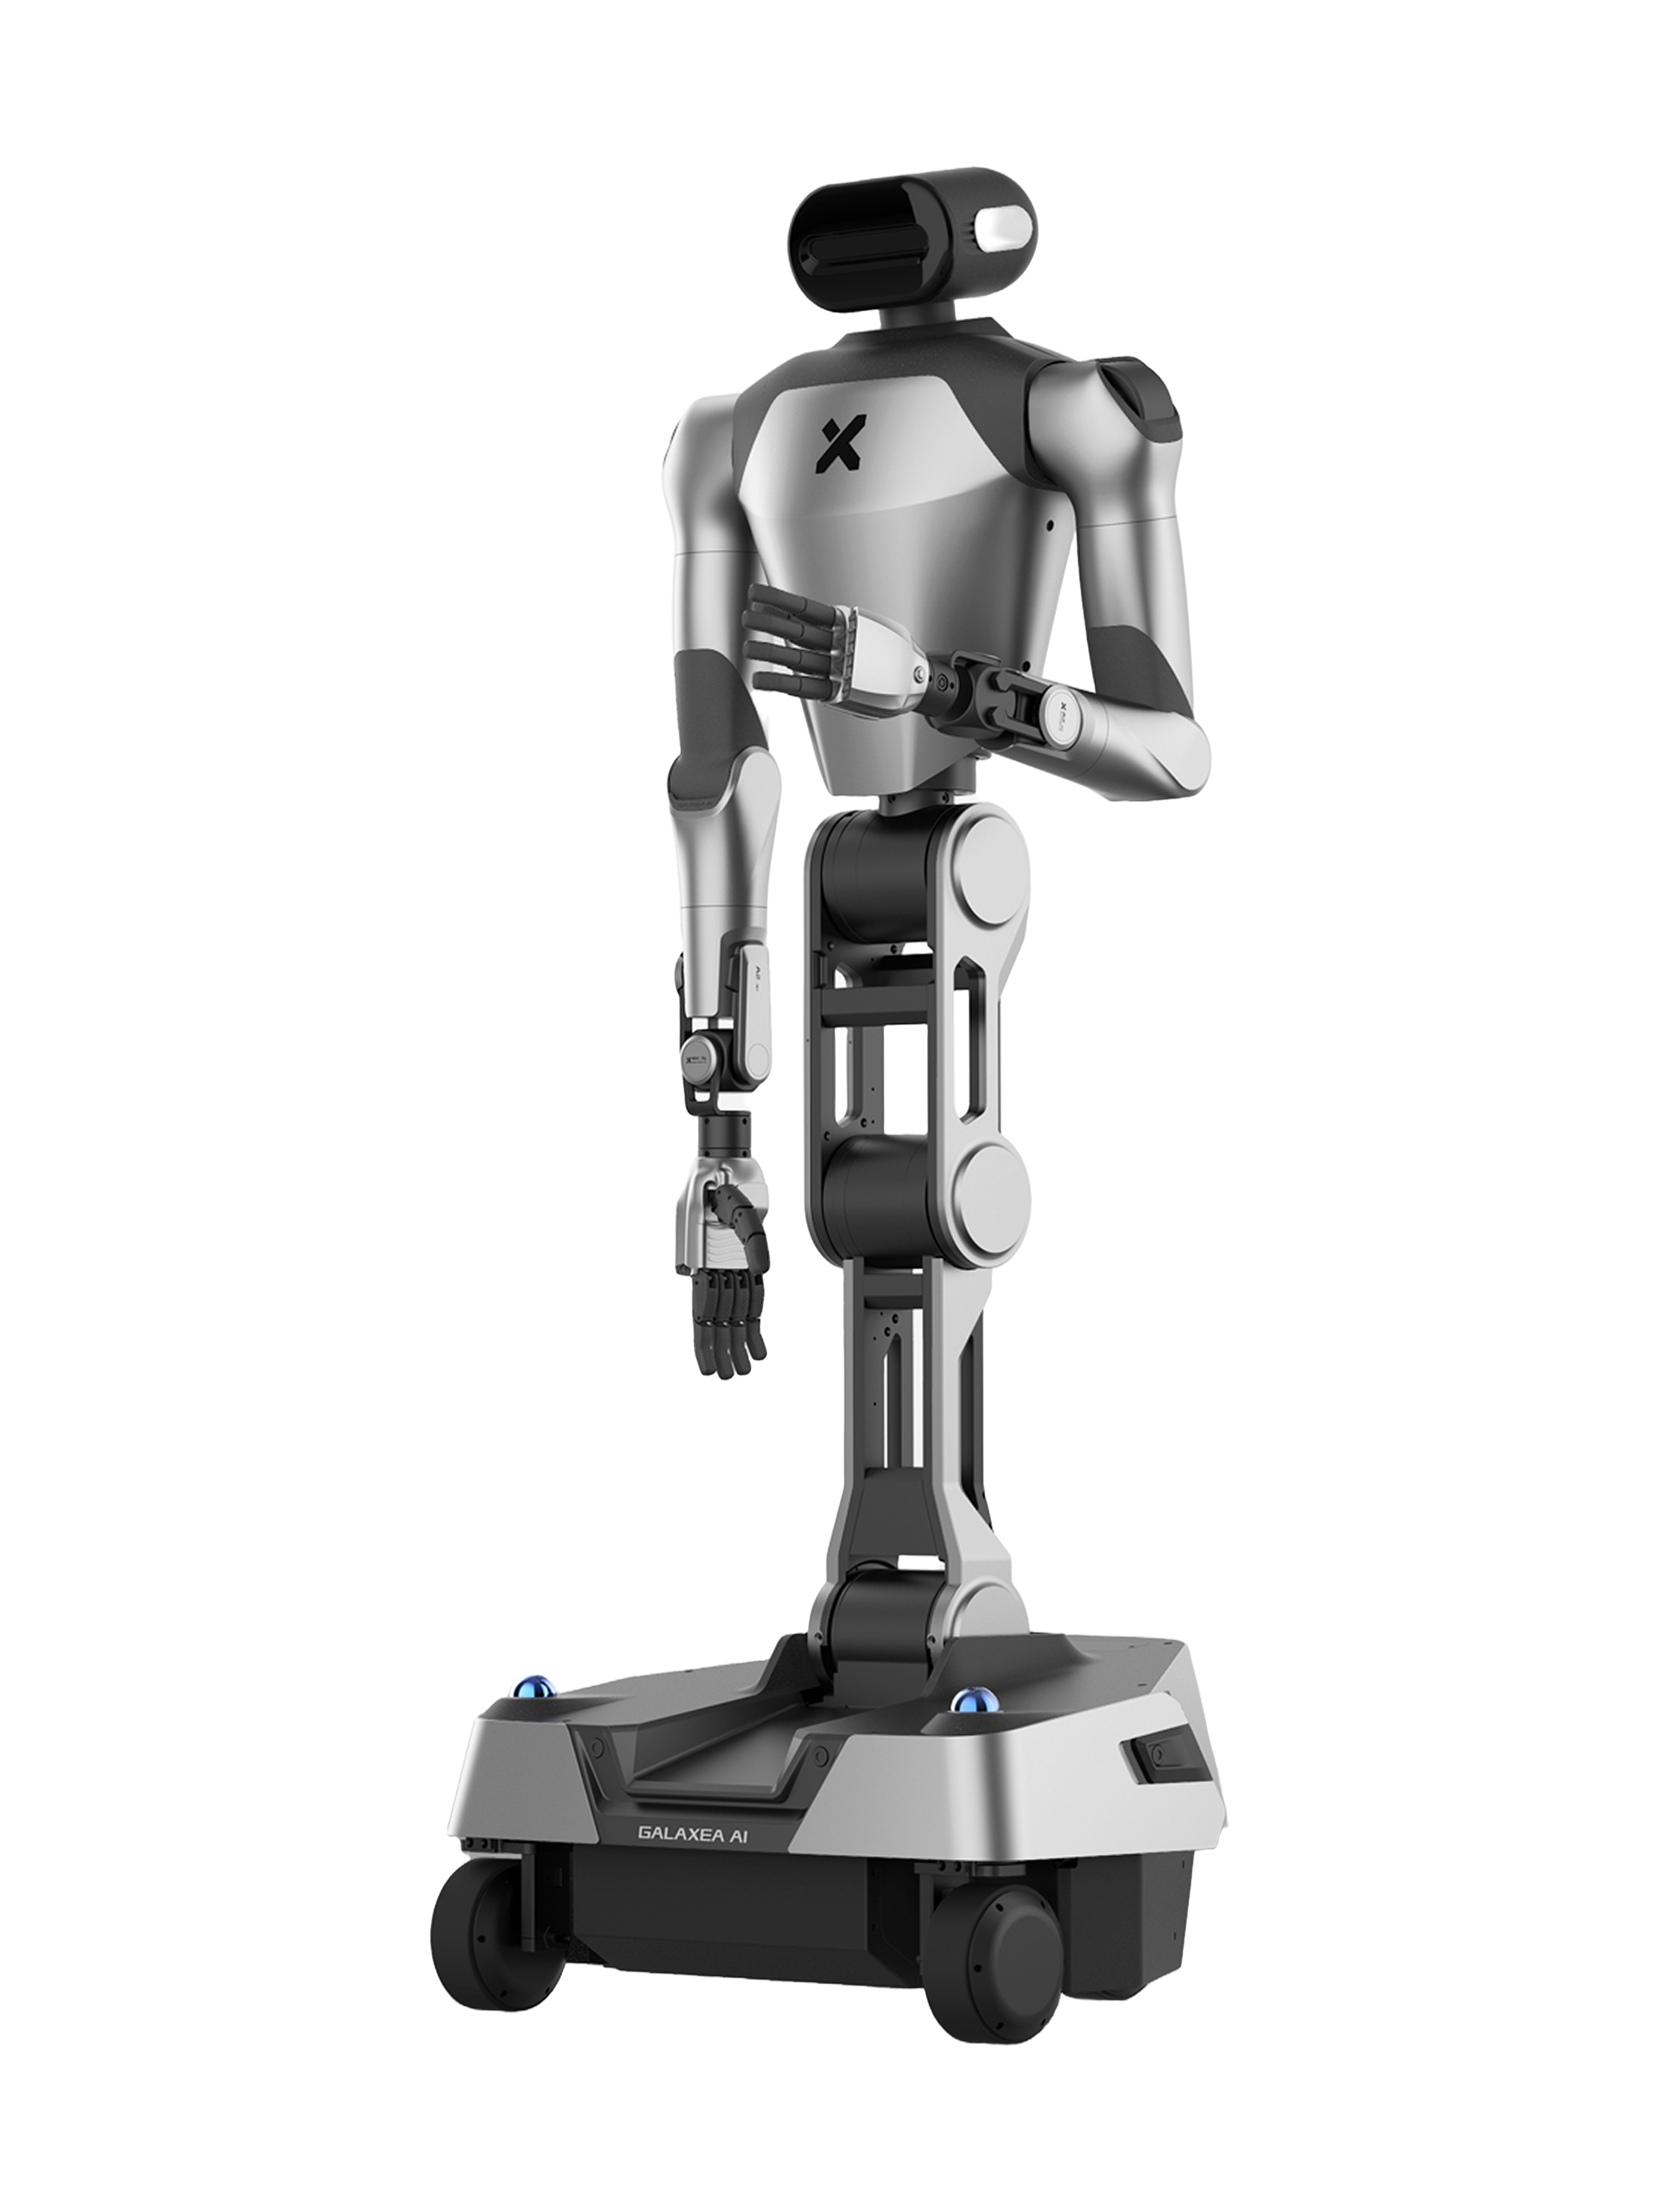
Manufacturer's own photo.
Intended use, per the manufacturer
Source: galaxea-ai.com · Retrieved
This category is not our assessment.
Full specifications
7 of 32 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | not stated | |
| Length | not stated | |
| Width | 67.5cm26.6inOur conversion from 67.5 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Only height and width are given in the key-dimensions row; no depth figure is given. A |
| Height | 170cm66.9inOur conversion from 170 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Producer's own label is "height" in the key-dimensions row. A |
| Degrees of freedom | 26DoF | Caveat Stated as "whole-body degrees of freedom (with standard gripper end-effector)". The same page also gives per-part figures: 7 per arm, 4 torso, 6 chassis. A |
| Payload, moving | not stated | |
| Payload, standing | not stated | |
| Max speed | 5.4km/h3.36mphOur conversion from 5.4 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Producer's own label is "chassis moving speed". A |
| Max slope | not stated | |
| Single obstacle | not stated | |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | |
| Runtime | not stated | |
| Hot-swap battery | not stated | |
| Charge time | not stated | |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | 1x LiDAR. | Note Listed together with 7 HD cameras under a single sensor-configuration line; no lidar model or range figure is given. A |
| Cameras | 7x HD cameras. | Note Listed together with 1 lidar under a single sensor-configuration line. A |
| Onboard compute | NVIDIA Jetson AGX Orin 32GB, 200 TOPS. | Note Producer's own labels are "architecture" and "compute capability". A |
| ROS 2 | not stated | |
| SDK languages | not stated | |
| Autonomy level | not stated | Note No named autonomy level is given; the page describes isomorphic and VR teleoperation and a newly added voice interaction function. A |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | |
| Data ports | not stated | |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- Galaxea Dynamics' own site presents R1 Pro alongside two sibling configurations, R1 and R1 Lite, in a single comparison table; the figures are from the R1 Pro column (the homepage's own image file for this robot is named "R1pro.png").
- The company's registered name in the page footer translates as "Galaxea (Beijing) Artificial Intelligence Technology Co., Ltd."
- Arm figures are also given: a single-arm rated payload of 3.5kg (max 5kg) at a 0.62m reach, and a vertical working range from the floor to 2m. They are not whole-body payloads.
- The stated whole-body degrees-of-freedom total (26, with standard gripper) is larger than the sum of the per-part figures given on the same page (7 DOF per arm + 4 torso + 6 chassis = 17, or 24 if each arm's 7 DOF is counted for both arms); the page does not explain the difference.
- R1 Pro moves on a chassis with 3 steering wheels (chassis degrees of freedom 6); it has no walking legs.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for R1 Prohttps://galaxea-ai.com/products/R1-Pro
Sources
-
A
Manufacturer product page. galaxea-ai.
com/ · Retrievedproducts/ R1-Pro -
B
github.
com/ · RetrievedOpenGalaxea/ GalaxeaVLA -
C
arxiv.
org/ · Retrievedhtml/ 2601. 18692
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.