Key figures as stated by the manufacturer
4 of 6 stated · 2 gaps- Weight A 55kg121lbOur conversion from 55 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- Payload, moving not stated
- Runtime A 480minWarning: load condition not stated
- Max speed A 4.32km/h2.68mphOur conversion from 4.32 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- AI model not stated
- Indicative price C 15,999USD
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Robots with several sources carry several letters.
- Payload, moving
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (5)
Weight
Note Net weight in the specification table.
Payload, moving
Caveat The table gives a "Maximum Payload" of 1 kg. The same table gives 1 kg for the Mercury B1 dual-arm robot and for a single arm.
Runtime
Caveat No load condition is given. The product page says "up to 8 hours".
Max speed
Note Maximum operating speed.
Indicative price
Caveat Regular price in the producer's own store, plus shipping and any taxes and tariffs.
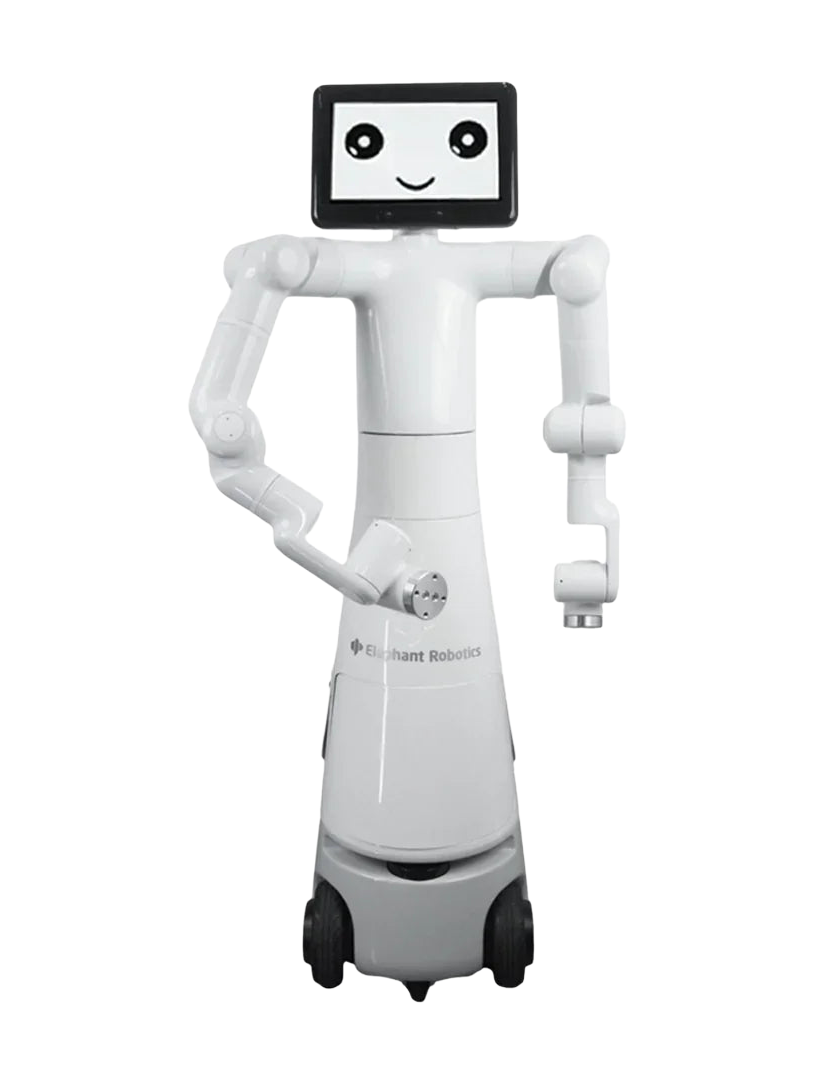
Manufacturer's own photo.
Intended use, per the manufacturer
Source: elephantrobotics.com · Retrieved
This category is not our assessment.
Full specifications
13 of 32 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | 55kg121lbOur conversion from 55 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Net weight in the specification table. A |
| Length | not stated | |
| Width | not stated | |
| Height | 118cm46.5inOur conversion from 118 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Specification table. A |
| Degrees of freedom | 19DoF | Note Specification table. A |
| Payload, moving | not stated | Caveat The table gives a "Maximum Payload" of 1 kg. The same table gives 1 kg for the Mercury B1 dual-arm robot and for a single arm. A |
| Payload, standing | not stated | Caveat The table gives a "Maximum Payload" of 1 kg. The same table gives 1 kg for the Mercury B1 dual-arm robot and for a single arm. A |
| Max speed | 4.32km/h2.68mphOur conversion from 4.32 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Maximum operating speed. A |
| Max slope | 15° | Note Maximum climbing angle. A |
| Single obstacle | 2cm0.79inOur conversion from 2 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Maximum climbing height of the mobile base. B |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | |
| Runtime | 480minWarning: load condition not stated | Caveat No load condition is given. The product page says "up to 8 hours". A |
| Hot-swap battery | not stated | |
| Charge time | not stated | |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | LiDAR in the mobile base. | Note The mobile base also has ultrasonic radar and 2D vision. A |
| Cameras | Orbbec Deeyea 3D camera. | Note Specification table. A |
| Onboard compute | Jetson Orin Nano SUPER 8GB, 67 TOPS. | Note Main controller of the specification table. A |
| ROS 2 | not stated | Caveat The page names ROS, without a version, among the supported simulation software. B |
| SDK languages | Python C++ | Note The page names a Python API (pymycobot) and a C++ API (Mercury API). B |
| Autonomy level | not stated | |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | |
| Data ports | CAN Bus Network port USB serial port | Note Communication row of the table, which also lists Wi-Fi and Bluetooth. A |
| Commercial | ||
| Indicative price | 15,999USD | Caveat Regular price in the producer's own store, plus shipping and any taxes and tariffs. C Price shown in USD, converted using the European Central Bank reference rate for 31/08/2026. D |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- The producer calls Mercury X1 a versatile wheeled full-humanoid robot.
- The page says the X1 is made up of the Mercury B1 dual-arm robot and a mobile base.
- The producer's own store says the Mercury X1 ships in 7-15 business days from a warehouse in China.
- The producer's contact page gives an address in Futian District, Shenzhen, China.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for Mercury X1https://www.elephantrobotics.com/en/mercury-specifications-en/
Sources
-
A
Manufacturer product page. www.
elephantrobotics. · Retrievedcom/ en/ mercury-specifications-en/ -
B
www.
elephantrobotics. · Retrievedcom/ en/ mercury-x1-en/ -
C
shop.
elephantrobotics. · Retrievedcom/ products/ mercury-humanoid-robot-series? variant= 47556966875448 -
D
Rate: European Central Bank, Euro foreign exchange reference rates, 31/08/2026. www.
ecb. · Retrievedeuropa. eu/ stats/ eurofxref/ eurofxref-daily. xml
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.