Unitree Robotics · robot AI model
UnifoLM-VLA-0
China · 2026
Runs on G1 by Unitree RoboticsSource and note: G1B unigen-x.github.io/unifolm-vla.github.io · Retrieved 13 November 2026
Sources retrieved: 13 November 2026 (A, B, C, D)
- Model type
- Vision-language-action (VLA)Source and note: Model typeA huggingface.co/unitreerobotics/UnifoLM-VLA-Base · Retrieved 13 November 2026Note. Developer wording: the model “is a Vision–Language–Action (VLA) large model in the UnifoLM series, designed for general-purpose humanoid robot manipulation.”
- What it controls
- Arms and handsSource and note: What it controlsA huggingface.co/unitreerobotics/UnifoLM-VLA-Base · Retrieved 13 November 2026Note. Model card: the model “is a Vision–Language–Action (VLA) large model in the UnifoLM series, designed for general-purpose humanoid robot manipulation.”
- Access
- Open weights (download)Source and note: AccessC github.com/unitreerobotics/unifolm-vla · Retrieved 13 November 2026Note. GitHub README: “We released the training and inference code, along with the model weights for” UnifoLM-VLA-0.
- Base model
- UnifoLM-VLM-0 (Qwen2.5-VL-7B backbone)Source and note: Base modelB unigen-x.github.io/unifolm-vla.github.io · Retrieved 13 November 2026Note. Project page: “We developed UnifoLM-VLA-0 by incorporating an Action Head into the UnifoLM-VLM-0 model”. For UnifoLM-VLM-0: “Building on the open-source Qwen2.5-VL-7B backbone”.
- Licence type
- Free, research onlySource and note: Licence typeD huggingface.co/unitreerobotics/UnifoLM-VLA-Base/blob/main/LICENSE · Retrieved 13 November 2026Note. Licence file title: “Attribution-NonCommercial-ShareAlike 4.0 International”.
Specifications
7 of 14 stated 7 not stated
4 fields hidden 3 not-stated fields with a note stay ·
How to read the figuresShow guideClose
- not statedNo source
- 0Reported as zero
- ASource
Select a source marker for source details and notes.
Release1/1 disclosed
Released29 January 2026
Source and note: ReleasedC github.com/unitreerobotics/unifolm-vla · Retrieved 13 November 2026Note. GitHub README news entry: “Jan 29, 2026”.
Input and output2/4 disclosed
Model typeVision-language-action (VLA)
Source and note: Model typeA huggingface.co/unitreerobotics/UnifoLM-VLA-Base · Retrieved 13 November 2026Note. Developer wording: the model “is a Vision–Language–Action (VLA) large model in the UnifoLM series, designed for general-purpose humanoid robot manipulation.”
InputsNot stated
What it controlsArms and hands
Source and note: What it controlsA huggingface.co/unitreerobotics/UnifoLM-VLA-Base · Retrieved 13 November 2026Note. Model card: the model “is a Vision–Language–Action (VLA) large model in the UnifoLM series, designed for general-purpose humanoid robot manipulation.”
Degrees of freedom controlledNot stated
Size and speed0/2 disclosed
ParametersNot stated
Source and note: ParametersB unigen-x.github.io/unifolm-vla.github.io · Retrieved 13 November 2026Note. Project page: “Building on the open-source Qwen2.5-VL-7B backbone”.
Control rateNot stated
Where it runs and what it is built on1/2 disclosed
On robot or cloudNot stated
Source and note: On robot or cloudC github.com/unitreerobotics/unifolm-vla · Retrieved 13 November 2026Note. GitHub README, real-world setup: “inference is executed on the server side”.
Base modelUnifoLM-VLM-0 (Qwen2.5-VL-7B backbone)
Source and note: Base modelB unigen-x.github.io/unifolm-vla.github.io · Retrieved 13 November 2026Note. Project page: “We developed UnifoLM-VLA-0 by incorporating an Action Head into the UnifoLM-VLM-0 model”. For UnifoLM-VLM-0: “Building on the open-source Qwen2.5-VL-7B backbone”.
Openness3/3 disclosed
AccessOpen weights (download)
Source and note: AccessC github.com/unitreerobotics/unifolm-vla · Retrieved 13 November 2026Note. GitHub README: “We released the training and inference code, along with the model weights for” UnifoLM-VLA-0.
Licence documentCC BY-NC-SA 4.0
Source and note: Licence documentA huggingface.co/unitreerobotics/UnifoLM-VLA-Base · Retrieved 13 November 2026Note. Model card: “The model is released under the CC BY-NC-SA 4.0 license”.
Licence typeFree, research only
Source and note: Licence typeD huggingface.co/unitreerobotics/UnifoLM-VLA-Base/blob/main/LICENSE · Retrieved 13 November 2026Note. Licence file title: “Attribution-NonCommercial-ShareAlike 4.0 International”.
The developer’s own claims0/2 disclosed
Learns new tasksNot stated
Works across robotsNot stated
Source and note: Works across robotsYes only if the developer itself says the model runs on different robot models, for example robots from two manufacturers or two of one manufacturer’s models. Several units of the same robot do not count.
Notes
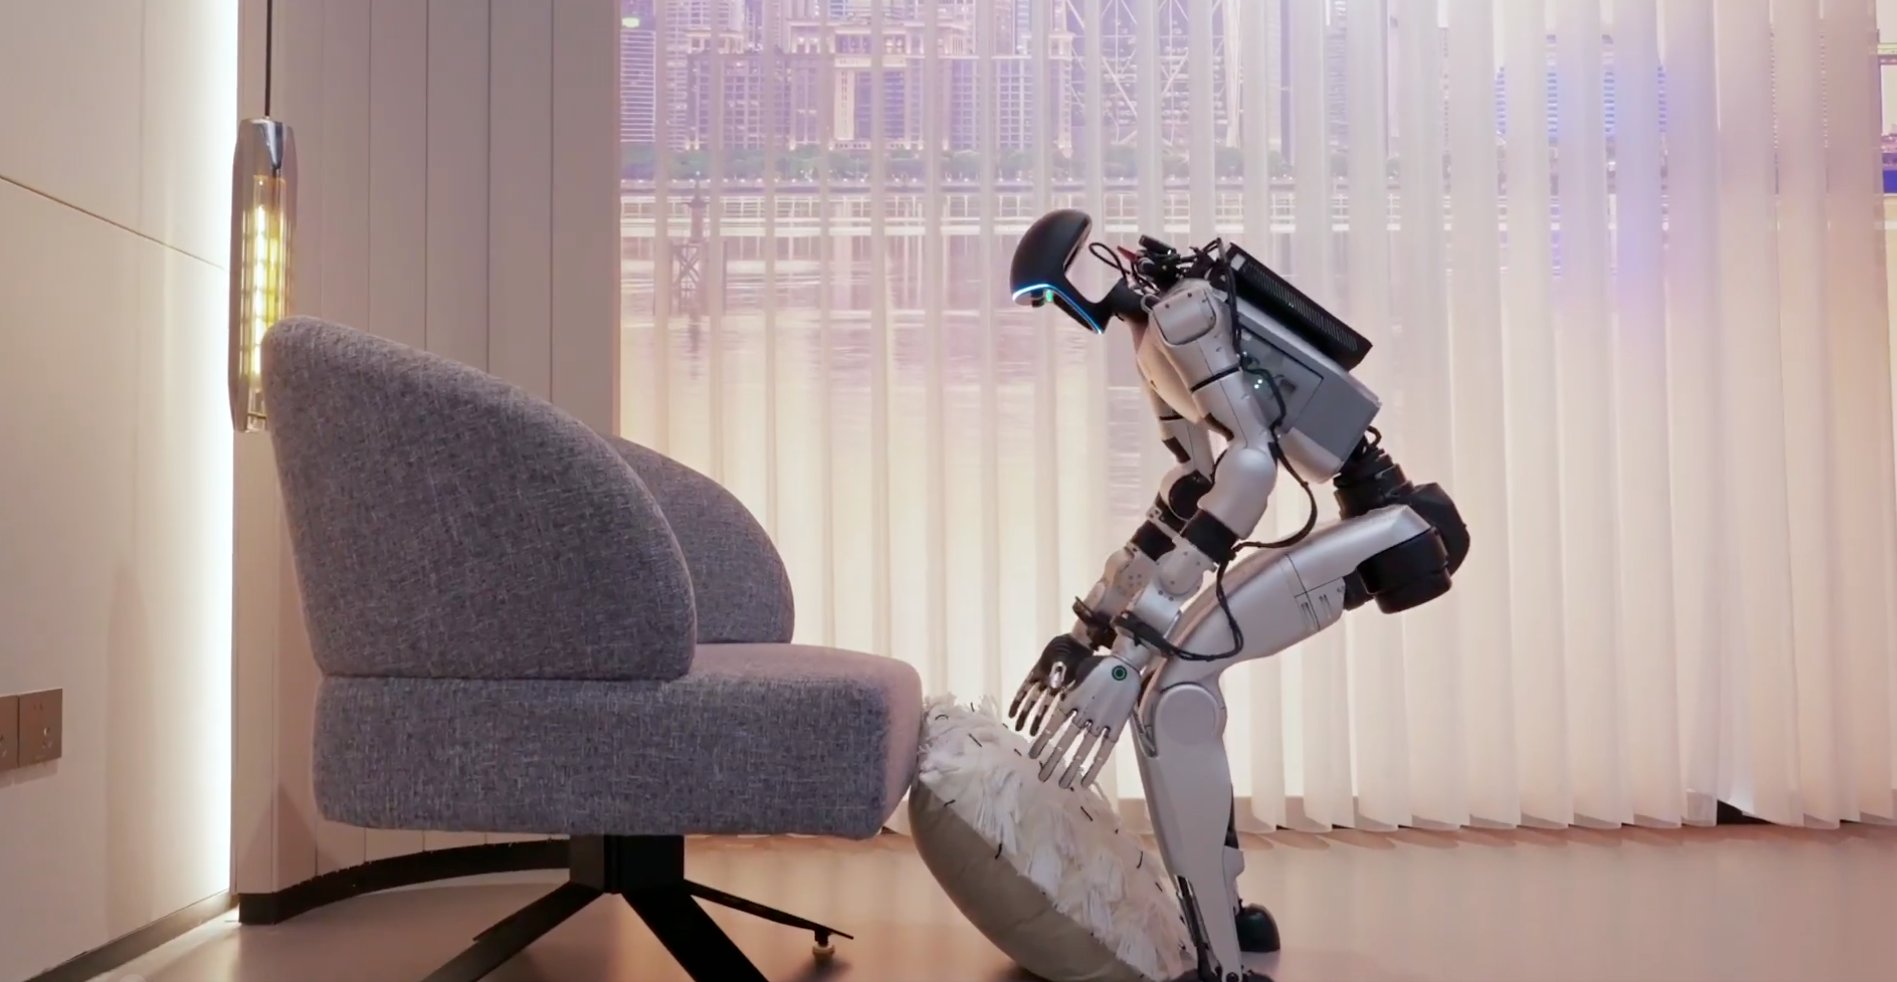
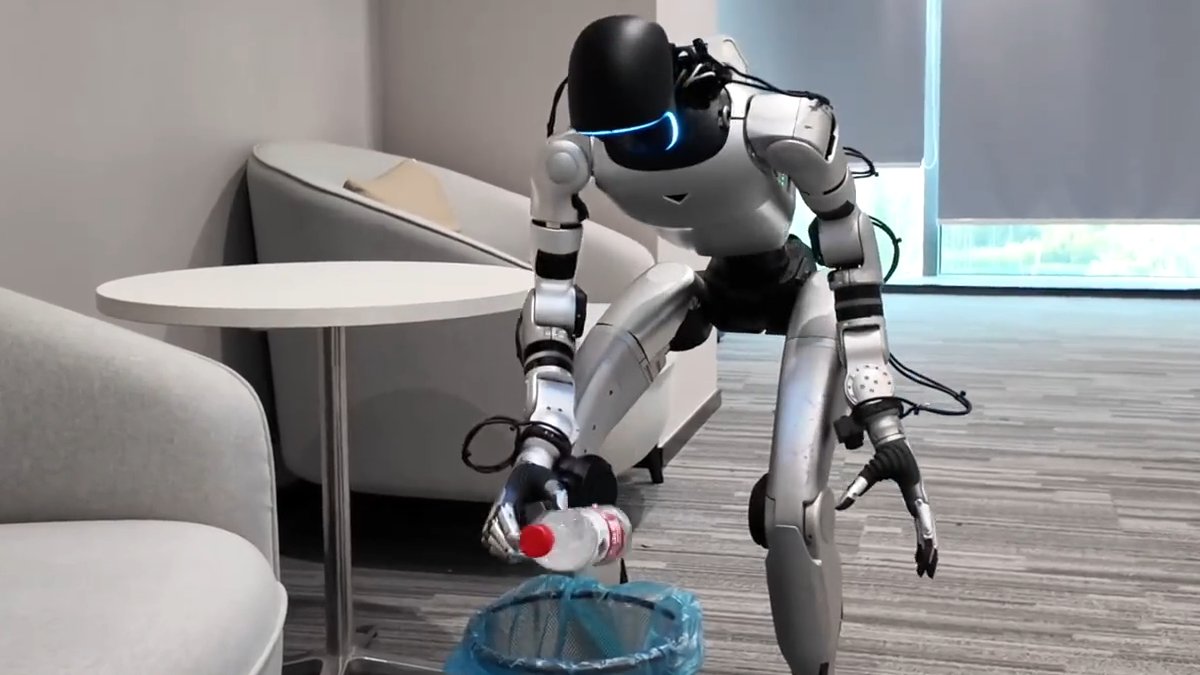
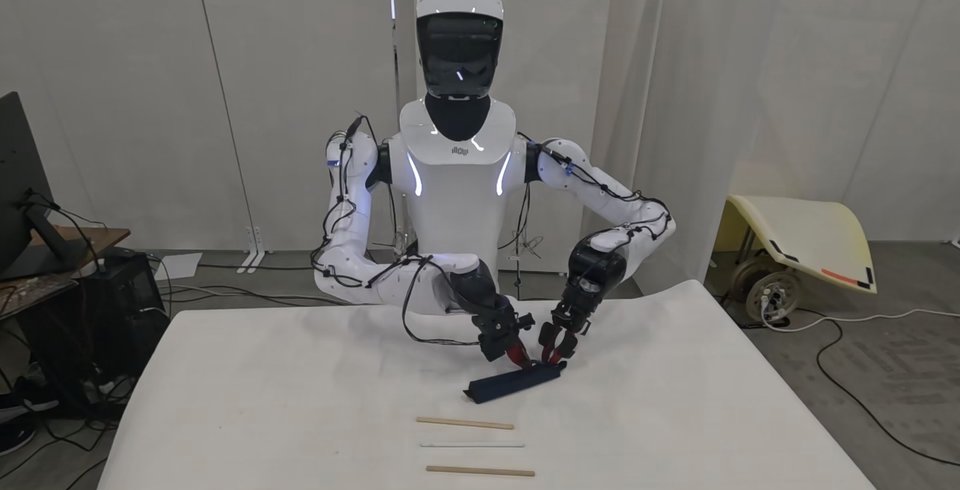
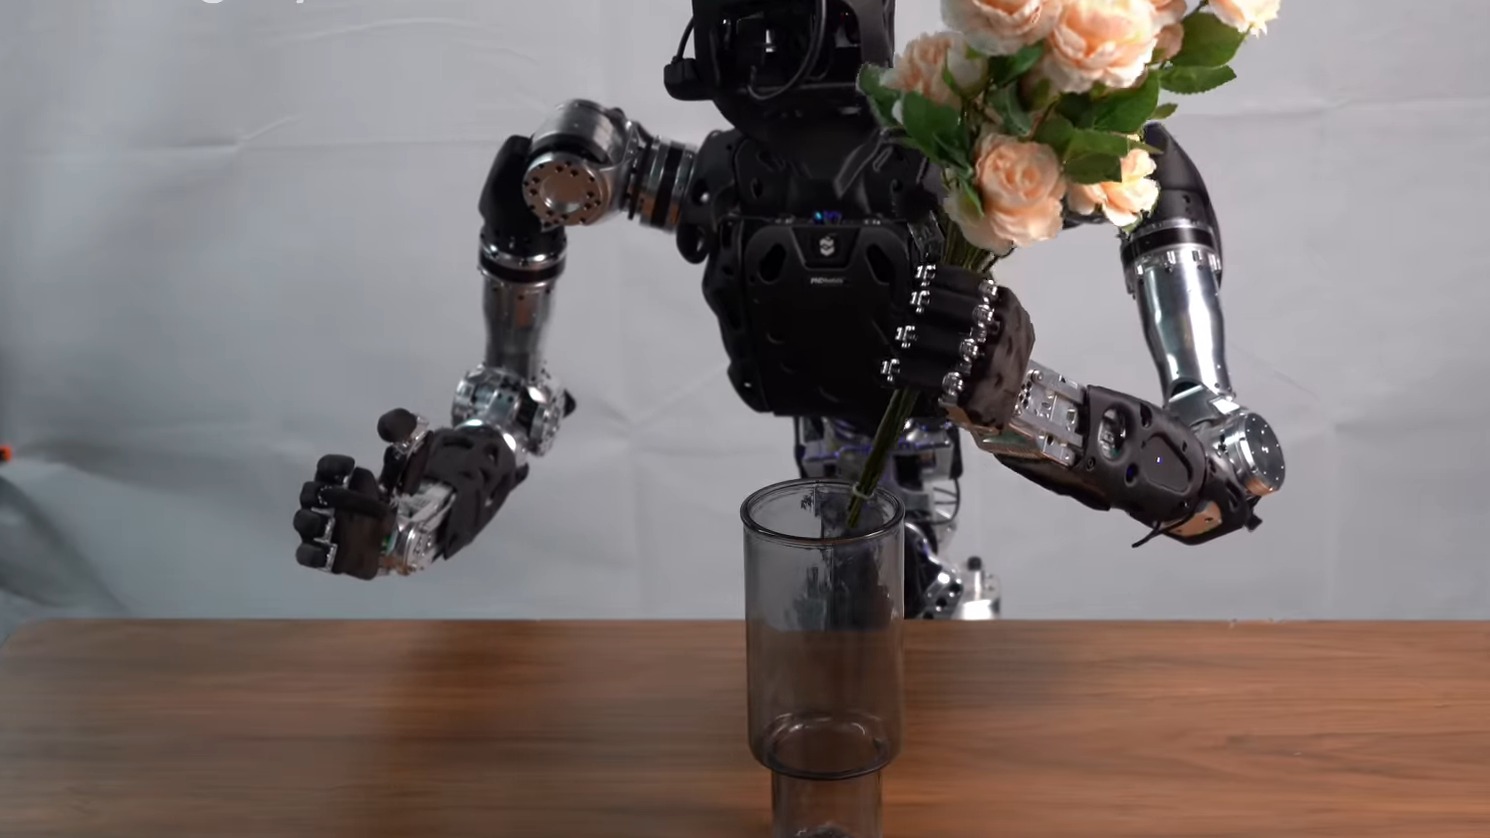
Unitree's model card: the model “is a Vision–Language–Action (VLA) large model in the UnifoLM series, designed for general-purpose humanoid robot manipulation.”
The GitHub README states the date “Jan 29, 2026”: “We released the training and inference code, along with the model weights for” UnifoLM-VLA-0.
Sources
One line per source, not per figure: a source has one retrieval date.
- Ahuggingface.co/unitreerobotics/UnifoLM-VLA-BaseRetrieved 13 November 2026
- Bunigen-x.github.io/unifolm-vla.github.ioMain source. Retrieved 13 November 2026
- Cgithub.com/unitreerobotics/unifolm-vlaRetrieved 13 November 2026
- Dhuggingface.co/unitreerobotics/UnifoLM-VLA-Base/blob/main/LICENSERetrieved 13 November 2026