Shanghai Innovation Institute · robot AI model
τ₀-WM
China · 2026
Sources retrieved: 19 November 2026 (A, B, C)
- Model type
- World action modelSource and note: Model typeA huggingface.co/sii-research/tau-0-wm/raw/main/README.md · Retrieved 19 November 2026Note. Model card: “τ₀-World Model (τ₀-WM) is a unified video-action world model that integrates policy learning, video prediction, and action evaluation within a single future-predictive framework.”
- What it controls
- Arms and handsSource and note: What it controlsA huggingface.co/sii-research/tau-0-wm/raw/main/README.md · Retrieved 19 November 2026Note. Model card: “The model is designed for dual-arm manipulation with the following specifications:” “Absolute poses of end-effectors and gripper openness (16 channels total).”
- Inputs
- Camera Language Robot stateSource and note: InputsA huggingface.co/sii-research/tau-0-wm/raw/main/README.md · Retrieved 19 November 2026Note. Model card: “Jointly predicts future visual latents and continuous action chunks from multi-view observations, language instructions, and robot state.”
- Access
- Open weights (download)Source and note: AccessA huggingface.co/sii-research/tau-0-wm/raw/main/README.md · Retrieved 19 November 2026Note. Checkpoints for both the Video Action Model and simulator are hosted on Hugging Face: “hf download sii-research/tau-0-wm”
- Parameters
- 5.5BSource and note: ParametersB arxiv.org/pdf/2606.01027 · Retrieved 19 November 2026Note. Paper: “Together, they form a 5.5B-parameter Video Action Model.” (5B video transformer plus 0.5B action decoder).
- Base model
- Wan2.2-TI2V-5BSource and note: Base modelB arxiv.org/pdf/2606.01027 · Retrieved 19 November 2026Note. Paper: “VAM is instantiated from Wan2.2-TI2V-5B”
- Licence type
- Free, commercial useSource and note: Licence typeA huggingface.co/sii-research/tau-0-wm/raw/main/README.md · Retrieved 19 November 2026Note. Model card metadata: “license: apache-2.0”
Specifications
11 of 14 stated 3 not stated
0 fields hidden 3 not-stated fields with a note stay ·
How to read the figuresShow guideClose
- not statedNo source
- yesStated by a source
- 0Reported as zero
- ASource
Select a source marker for source details and notes.
Release1/1 disclosed
Released31 May 2026
Source and note: ReleasedC arxiv.org/abs/2606.01027 · Retrieved 19 November 2026Note. arXiv abstract page: “Submitted on 31 May 2026”
Input and output3/4 disclosed
Model typeWorld action model
Source and note: Model typeA huggingface.co/sii-research/tau-0-wm/raw/main/README.md · Retrieved 19 November 2026Note. Model card: “τ₀-World Model (τ₀-WM) is a unified video-action world model that integrates policy learning, video prediction, and action evaluation within a single future-predictive framework.”
InputsCamera Language Robot state
Source and note: InputsA huggingface.co/sii-research/tau-0-wm/raw/main/README.md · Retrieved 19 November 2026Note. Model card: “Jointly predicts future visual latents and continuous action chunks from multi-view observations, language instructions, and robot state.”
What it controlsArms and hands
Source and note: What it controlsA huggingface.co/sii-research/tau-0-wm/raw/main/README.md · Retrieved 19 November 2026Note. Model card: “The model is designed for dual-arm manipulation with the following specifications:” “Absolute poses of end-effectors and gripper openness (16 channels total).”
Degrees of freedom controlledNot stated
Source and note: Degrees of freedom controlledA huggingface.co/sii-research/tau-0-wm/raw/main/README.md · Retrieved 19 November 2026Note. Model card specifies 16-channel end-effector pose and gripper openness output rather than joint degrees of freedom: “Absolute poses of end-effectors and gripper openness (16 channels total).”
Size and speed1/2 disclosed
Parameters5.5B
Source and note: ParametersB arxiv.org/pdf/2606.01027 · Retrieved 19 November 2026Note. Paper: “Together, they form a 5.5B-parameter Video Action Model.” (5B video transformer plus 0.5B action decoder).
Control rateNot stated
Source and note: Control rateB arxiv.org/pdf/2606.01027 · Retrieved 19 November 2026Note. Paper reports end-to-end action generation latency rather than a control frequency: “Real-robot inference is deployed on a single RTX 5090” It executes “using fixed-length action chunks of 30.”
Where it runs and what it is built on1/2 disclosed
On robot or cloudNot stated
Source and note: On robot or cloudB arxiv.org/pdf/2606.01027 · Retrieved 19 November 2026Note. Paper states inference hardware without specifying whether it sits onboard or offboard: “Real-robot inference is deployed on a single RTX 5090”
Base modelWan2.2-TI2V-5B
Source and note: Base modelB arxiv.org/pdf/2606.01027 · Retrieved 19 November 2026Note. Paper: “VAM is instantiated from Wan2.2-TI2V-5B”
Openness3/3 disclosed
AccessOpen weights (download)
Source and note: AccessA huggingface.co/sii-research/tau-0-wm/raw/main/README.md · Retrieved 19 November 2026Note. Checkpoints for both the Video Action Model and simulator are hosted on Hugging Face: “hf download sii-research/tau-0-wm”
Licence documentApache-2.0
Source and note: Licence documentA huggingface.co/sii-research/tau-0-wm/raw/main/README.md · Retrieved 19 November 2026Note. Model card metadata: “license: apache-2.0”
Licence typeFree, commercial use
Source and note: Licence typeA huggingface.co/sii-research/tau-0-wm/raw/main/README.md · Retrieved 19 November 2026Note. Model card metadata: “license: apache-2.0”
The developer’s own claims2/2 disclosed
Learns new tasksWithout examples
Source and note: Learns new tasksB arxiv.org/pdf/2606.01027 · Retrieved 19 November 2026Note. Paper evaluates both zero-shot task execution and supervised fine-tuning.Note. Developer claim, paper: “The zero-shot task requires picking up a pen and placing it into a pen holder, while the fine-tuning task requires picking up an object, wiping off dirt, and returning it to the tabletop.”
Works across robotsYes
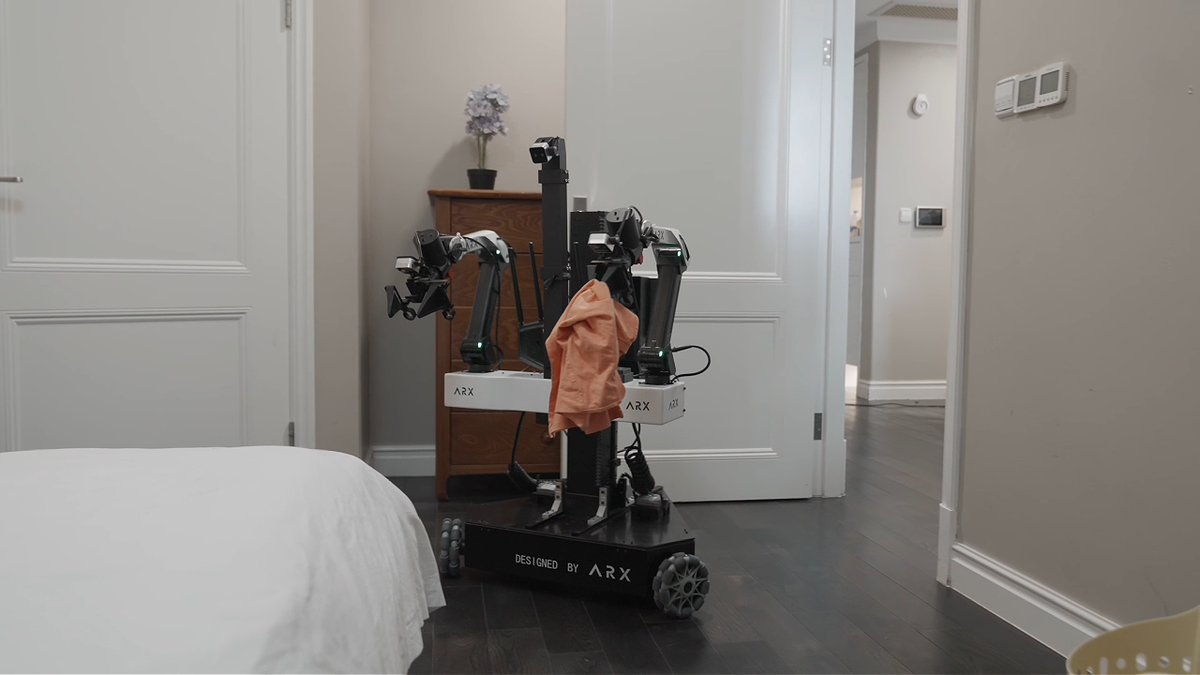
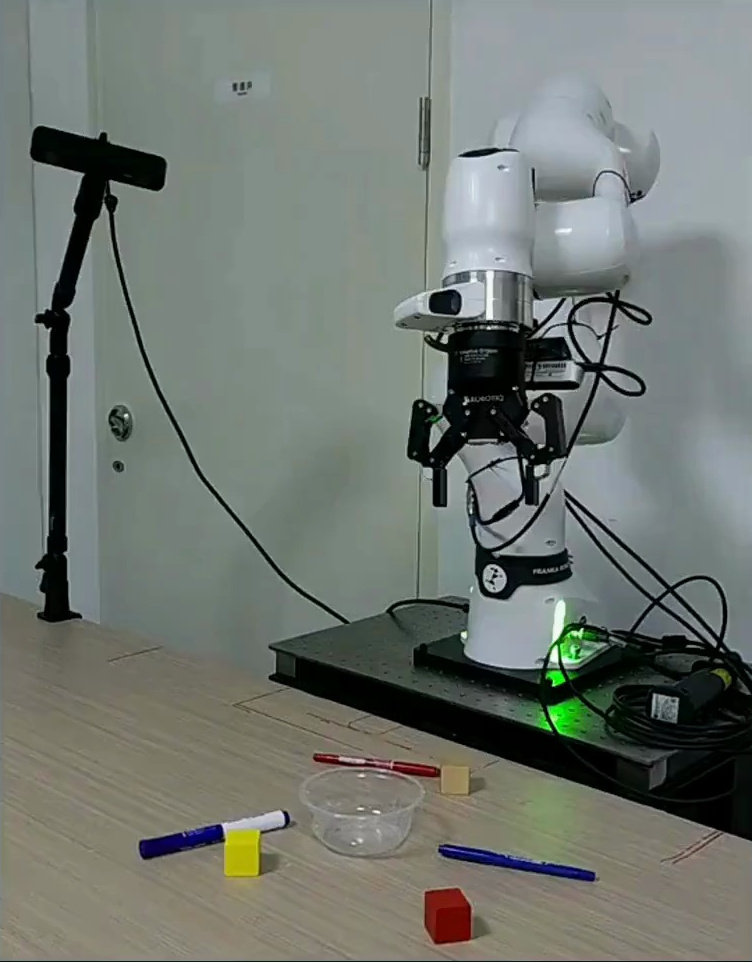
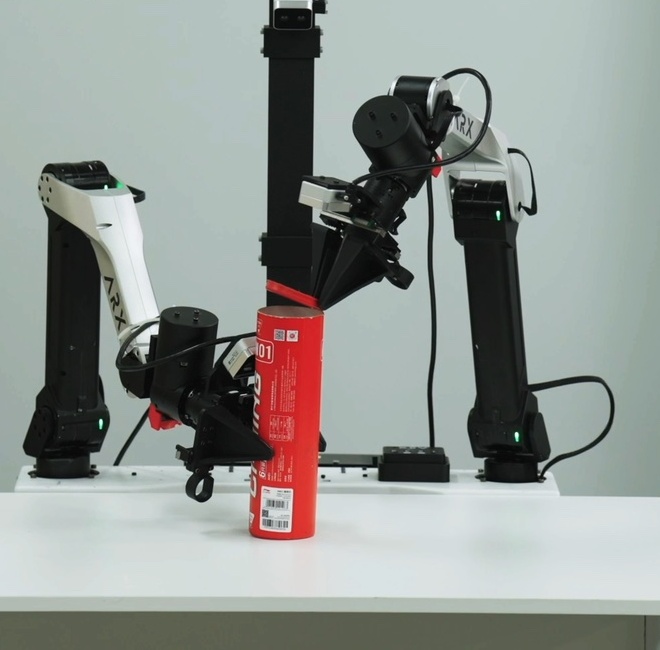
Source and note: Works across robotsB arxiv.org/pdf/2606.01027 · Retrieved 19 November 2026Note. Developer claim, paper: “conducted on the ARX manipulator and Faucet” Training data also spans “17.8K hours of real-robot teleoperation on AGIBOT-G01, ARX manipulators, and dual-arm Franka systems”Yes only if the developer itself says the model runs on different robot models, for example robots from two manufacturers or two of one manufacturer’s models. Several units of the same robot do not count.
Notes
Developed by Shanghai Innovation Institute and AGIBOT Finch. “τ₀-World Model (τ₀-WM) is a unified video-action world model that integrates policy learning, video prediction, and action evaluation within a single future-predictive framework.”
The arXiv preprint was submitted on 31 May 2026, and checkpoints are available for open download on Hugging Face.
Sources
One line per source, not per figure: a source has one retrieval date.
- Ahuggingface.co/sii-research/tau-0-wm/raw/main/README.mdMain source. Retrieved 19 November 2026
- Barxiv.org/pdf/2606.01027Retrieved 19 November 2026
- Carxiv.org/abs/2606.01027Retrieved 19 November 2026