Key figures as stated by the manufacturer
2 of 6 stated · 4 gaps- Weight not stated
- Payload, moving not stated
- Runtime A 480minWarning: load condition not stated
- Max speed A 2.16km/h1.34mphOur conversion from 2.16 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- AI model not stated
- Indicative price not stated
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Robots with several sources carry several letters.
- Payload, moving
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (3)
Payload, moving
Note The page gives a rated straight-arm load of 5 kg per arm, including the dexterous hand. That is an arm-specific figure, not a figure for what the whole robot can carry.
Runtime
Caveat No load or task condition is given.
Max speed
Caveat Chassis figure. The turning speed is at most 0.4 rad/s.
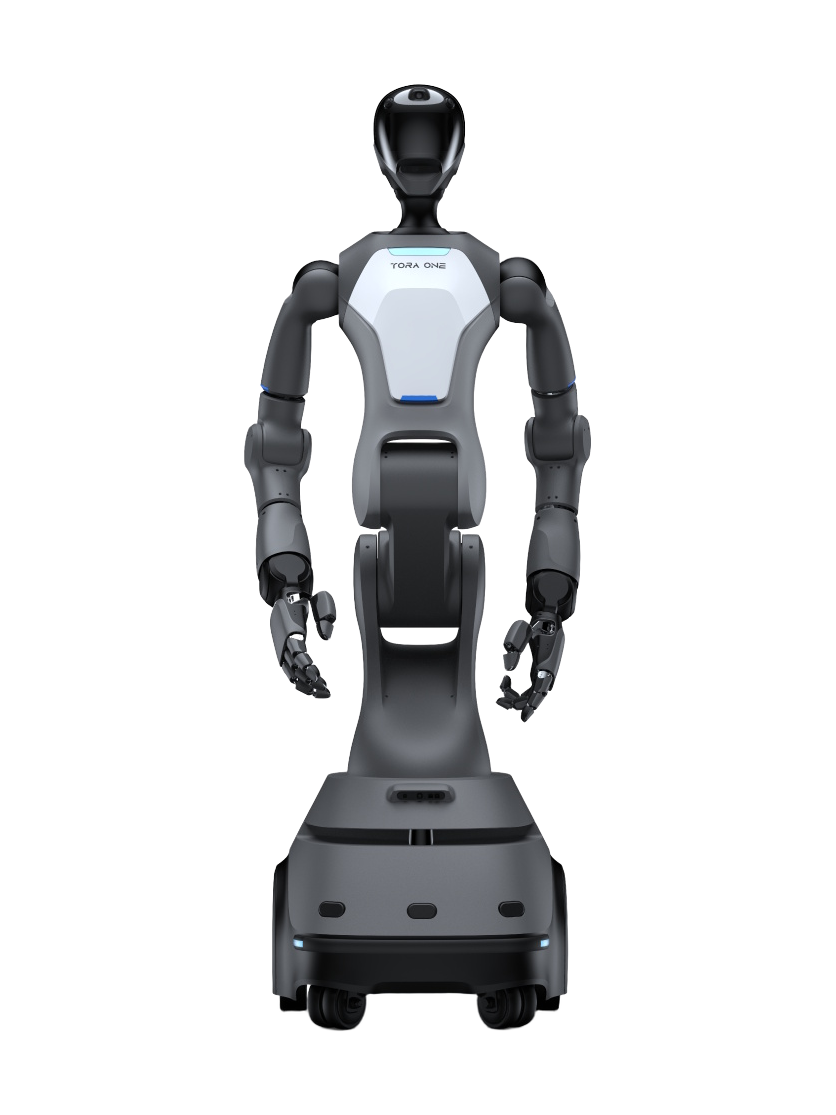
Product image from a reseller's page (robotsinternational.com), not the manufacturer's own site.
Intended use, per the manufacturer
The manufacturer’s words
Warehousing Logistics Medical and Health Care Industrial Manufacturing Commercial Scenarios Home Services
Source: paxini.com · Retrieved
This category is not our assessment.
Full specifications
9 of 32 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | not stated | |
| Length | not stated | |
| Width | not stated | |
| Height | 146–186cm57.5–73.2inOur conversion from 146–186 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Caveat Adjustable: 1.46 m with the waist folded, 1.86 m extended. A |
| Degrees of freedom | 53DoF | Note The body has 21 DoF excluding the dexterous hands, plus 32 DoF for the two hands (16 DoF per hand: 13 active and 3 passive, four fingers per hand). A |
| Payload, moving | not stated | Note The page gives a rated straight-arm load of 5 kg per arm, including the dexterous hand. That is an arm-specific figure, not a figure for what the whole robot can carry. A |
| Payload, standing | not stated | Note The page gives a rated straight-arm load of 5 kg per arm, including the dexterous hand. That is an arm-specific figure, not a figure for what the whole robot can carry. A |
| Max speed | 2.16km/h1.34mphOur conversion from 2.16 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Caveat Chassis figure. The turning speed is at most 0.4 rad/s. A |
| Max slope | 7° | Caveat Chassis figure, given as the climbing angle. A |
| Single obstacle | 2cm0.79inOur conversion from 2 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Caveat Chassis figure, given as the obstacle crossing height. The ditch width is 2 cm. A |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | Note The battery is given as 40 Ah, with no voltage. A |
| Runtime | 480minWarning: load condition not stated | Caveat No load or task condition is given. A |
| Hot-swap battery | not stated | |
| Charge time | 360min | Note Charging time as given in the specification table. A |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | LIDAR system, used with SLAM navigation. | Note The type of LIDAR is not named. Navigation is by laser SLAM. A |
| Cameras | 5 RGB cameras (3 in head, 1 in each hand) and 2 RGBD cameras (1 in head, 1 in chassis). | Caveat The store FAQ describes the head vision as one RGBD camera and three fisheye cameras with a 270-degree field of view. A |
| Onboard compute | not stated | |
| ROS 2 | not stated | |
| SDK languages | not stated | |
| Autonomy level | not stated | Note No named autonomy level is given. Navigation is laser SLAM autonomous navigation, and manipulation uses a Visual-Tactile-Language-Action (VTLA) multimodal model. A |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | |
| Data ports | not stated | |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- TORA ONE moves on a wheeled chassis with a maximum speed of 0.6 m/s; it does not walk on legs.
- The chassis has a turning radius of 0 m and turns on the spot. PaXini gives the navigation positioning accuracy as ±3 cm.
- Each arm, with the dexterous hand, has a maximum reach of 96.5 cm and a rated straight-arm load of 5 kg.
- PaXini's hands carry 2280 ITPU multidimensional tactile sensing units, giving 6840 tactile signals.
- PaXini's online store lists TORA ONE with a contact-sales button and no price.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for TORA ONEhttps://paxini.com/en/robot
Sources
-
A
Manufacturer product page. paxini.
com/ · Retrieveden/ robot
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.