OpenBMB · robot AI model
MiniCPM-RobotTrack
China · 2026
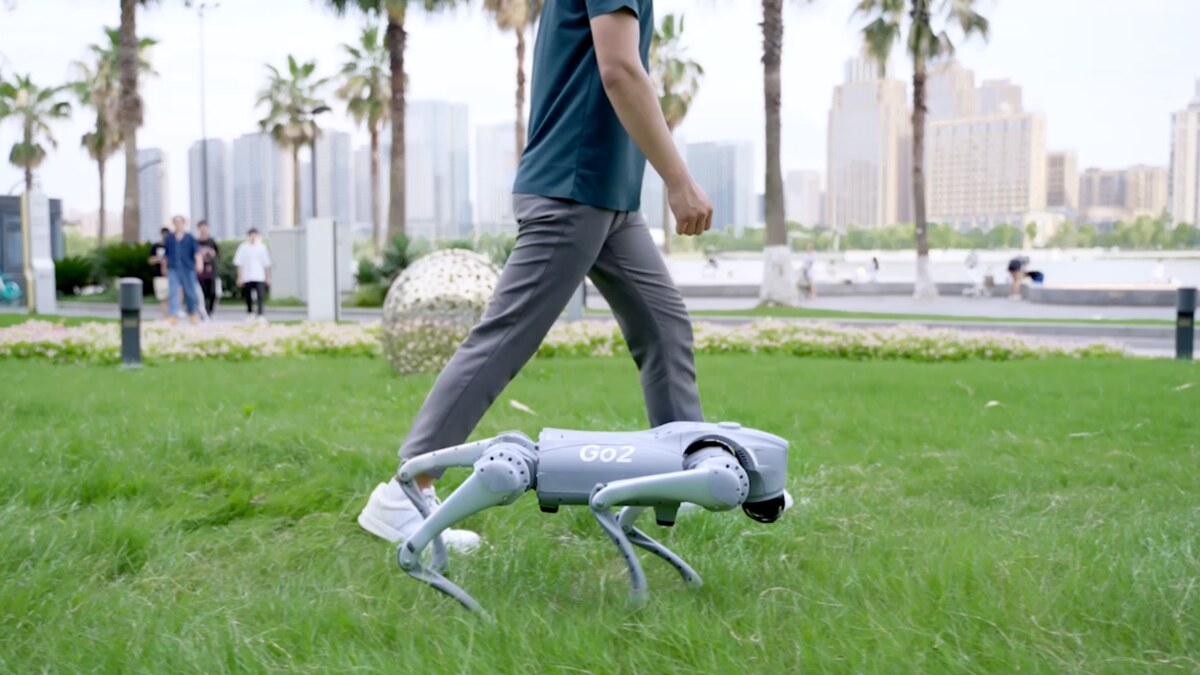
Runs on Go2 by Unitree RoboticsSource and note: Go2B github.com/OpenBMB/MiniCPM-Robot · Retrieved 9 November 2026
Sources retrieved: 9 November 2026 (A, B, C)
- Model type
- Vision-language-action (VLA)Source and note: Model typeA huggingface.co/openbmb/MiniCPM-RobotTrack · Retrieved 9 November 2026Note. Hugging Face model card: “MiniCPM-RobotTrack is a compact vision-language-action model built on MiniCPM4-0.5B for target tracking”.
- Inputs
- Camera LanguageSource and note: InputsA huggingface.co/openbmb/MiniCPM-RobotTrack · Retrieved 9 November 2026Note. Hugging Face model card: the model “combines natural-language instructions with fused DINOv3 and SigLIP visual features”. README: “on Unitree Go2 EDU with fully local, vision-only natural-language tracking”.
- Access
- Open weights (download)Source and note: AccessA huggingface.co/openbmb/MiniCPM-RobotTrack · Retrieved 9 November 2026Note. Hugging Face model card: “Model weights and code are open-sourced under the” Apache-2.0. The repository is listed as not gated.
- Parameters
- 900MSource and note: ParametersB github.com/OpenBMB/MiniCPM-Robot · Retrieved 9 November 2026Note. README model zoo: “A 0.9B vision-language-action model for Target Tracking”. The Hugging Face repository metadata lists 449787035 parameters in model.safetensors; the README says “Evaluation still requires DINOv3 ViT-S/16 and SigLIP So400m”.
- Base model
- MiniCPM4-0.5BSource and note: Base modelA huggingface.co/openbmb/MiniCPM-RobotTrack · Retrieved 9 November 2026Note. Hugging Face model card: “MiniCPM-RobotTrack is a compact vision-language-action model built on MiniCPM4-0.5B for target tracking”.
- Licence type
- Free, commercial useSource and note: Licence typeA huggingface.co/openbmb/MiniCPM-RobotTrack · Retrieved 9 November 2026Note. “Model weights and code are open-sourced under the” Apache-2.0.
Specifications
10 of 14 stated 4 not stated
1 field hidden 3 not-stated fields with a note stay ·
How to read the figuresShow guideClose
- not statedNo source
- 0Reported as zero
- ASource
Select a source marker for source details and notes.
Release1/1 disclosed
Released19 July 2026
Source and note: ReleasedB github.com/OpenBMB/MiniCPM-Robot · Retrieved 9 November 2026Note. [A] README news “[2026.07.19]”: “We release and open-source MiniCPM-Robot”.
Input and output2/4 disclosed
Model typeVision-language-action (VLA)
Source and note: Model typeA huggingface.co/openbmb/MiniCPM-RobotTrack · Retrieved 9 November 2026Note. Hugging Face model card: “MiniCPM-RobotTrack is a compact vision-language-action model built on MiniCPM4-0.5B for target tracking”.
InputsCamera Language
Source and note: InputsA huggingface.co/openbmb/MiniCPM-RobotTrack · Retrieved 9 November 2026Note. Hugging Face model card: the model “combines natural-language instructions with fused DINOv3 and SigLIP visual features”. README: “on Unitree Go2 EDU with fully local, vision-only natural-language tracking”.
What it controlsNot stated
Source and note: What it controlsA huggingface.co/openbmb/MiniCPM-RobotTrack · Retrieved 9 November 2026Note. The model predicts waypoints for the robot's path, not motor commands: it “directly predicts eight future [x, y, yaw] waypoints for embodied person following”. The README deploys it on a Unitree Go2 quadruped.
Degrees of freedom controlledNot stated
Source and note: Degrees of freedom controlledA huggingface.co/openbmb/MiniCPM-RobotTrack · Retrieved 9 November 2026Note. The model outputs waypoints, not joint commands: it “directly predicts eight future [x, y, yaw] waypoints for embodied person following”.
Size and speed2/2 disclosed
Parameters900M
Source and note: ParametersB github.com/OpenBMB/MiniCPM-Robot · Retrieved 9 November 2026Note. README model zoo: “A 0.9B vision-language-action model for Target Tracking”. The Hugging Face repository metadata lists 449787035 parameters in model.safetensors; the README says “Evaluation still requires DINOv3 ViT-S/16 and SigLIP So400m”.
Control rateat least 5Hz
Source and note: Control rateA huggingface.co/openbmb/MiniCPM-RobotTrack · Retrieved 9 November 2026Note. End-to-end loop on the Unitree Go2, not the model alone: Hugging Face model card: “Joint optimization of visual capture, input encoding, model inference, action generation, command transmission, and execution” “delivers a stable 5+ FPS with approximately 180 ms end-to-end latency on the Unitree Go2's native onboard compute”. OpenBMB gives the rate as FPS.
Where it runs and what it is built on2/2 disclosed
On robot or cloudOn the robot
Source and note: On robot or cloudB github.com/OpenBMB/MiniCPM-Robot · Retrieved 9 November 2026Note. README: MiniCPM-RobotTrack runs “on Unitree Go2 EDU with fully local, vision-only natural-language tracking”. Model card: “delivers a stable 5+ FPS with approximately 180 ms end-to-end latency on the Unitree Go2's native onboard compute”. Deployment guide, hardware: “and a bootable NVMe drive in the expansion dock”.
Base modelMiniCPM4-0.5B
Source and note: Base modelA huggingface.co/openbmb/MiniCPM-RobotTrack · Retrieved 9 November 2026Note. Hugging Face model card: “MiniCPM-RobotTrack is a compact vision-language-action model built on MiniCPM4-0.5B for target tracking”.
Openness3/3 disclosed
AccessOpen weights (download)
Source and note: AccessA huggingface.co/openbmb/MiniCPM-RobotTrack · Retrieved 9 November 2026Note. Hugging Face model card: “Model weights and code are open-sourced under the” Apache-2.0. The repository is listed as not gated.
Licence documentApache-2.0
Source and note: Licence documentA huggingface.co/openbmb/MiniCPM-RobotTrack · Retrieved 9 November 2026Note. “Model weights and code are open-sourced under the” Apache-2.0. Tag: “license: apache-2.0”. The repository also lists the files LICENSE_MINICPM and LICENSE_MIT.
Licence typeFree, commercial use
Source and note: Licence typeA huggingface.co/openbmb/MiniCPM-RobotTrack · Retrieved 9 November 2026Note. “Model weights and code are open-sourced under the” Apache-2.0.
The developer’s own claims0/2 disclosed
Learns new tasksNot stated
Works across robotsNot stated
Source and note: Works across robotsC github.com/OpenBMB/MiniCPM-Robot/blob/main/MiniCPM-RobotTrack/docs/GO2_DEPLOYMENT.md · Retrieved 9 November 2026Note. OpenBMB names one supported robot: “Supported hardware is limited to Go2 EDU, Orin NX 16GB, and D435i.”Yes only if the developer itself says the model runs on different robot models, for example robots from two manufacturers or two of one manufacturer’s models. Several units of the same robot do not count.
Notes
OpenBMB describes MiniCPM-RobotTrack on Hugging Face as a compact vision-language-action model built on MiniCPM4-0.5B for target tracking.
MiniCPM-RobotTrack is one of the two first models of the MiniCPM-Robot family; the other is MiniCPM-RobotManip.
Sources
One line per source, not per figure: a source has one retrieval date.
- Ahuggingface.co/openbmb/MiniCPM-RobotTrackMain source. Retrieved 9 November 2026
- Bgithub.com/OpenBMB/MiniCPM-RobotRetrieved 9 November 2026
- Cgithub.com/OpenBMB/MiniCPM-Robot/blob/main/MiniCPM-RobotTrack/docs/GO2_DEPLOYMENT.mdRetrieved 9 November 2026