Nanyang Technological University · robot AI model
RealtimeWAM
Singapore · 2026
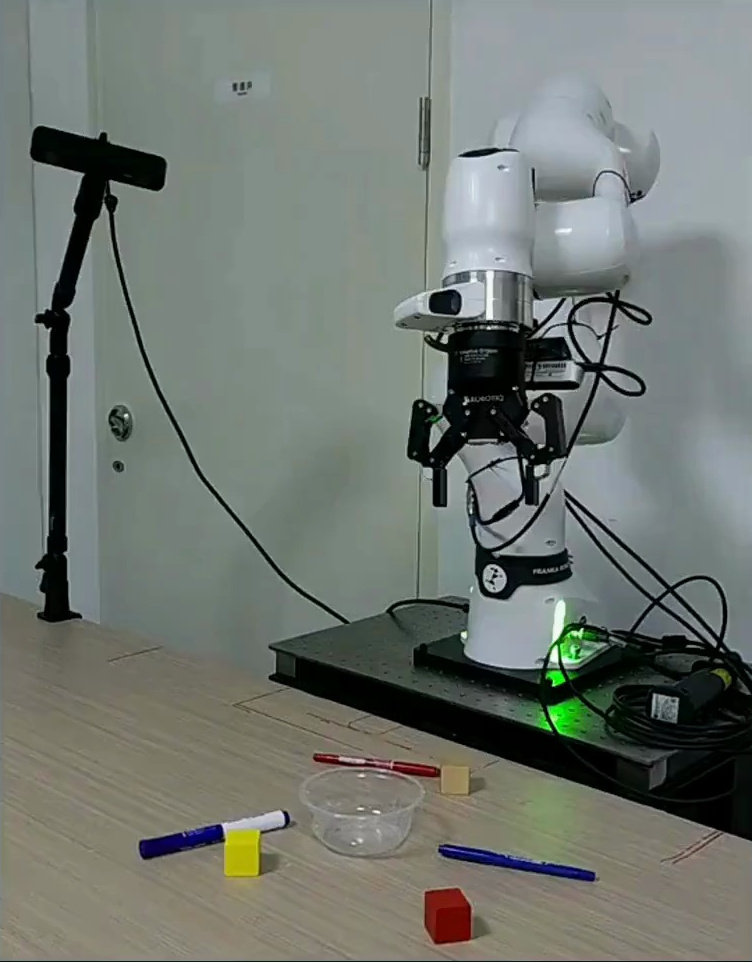
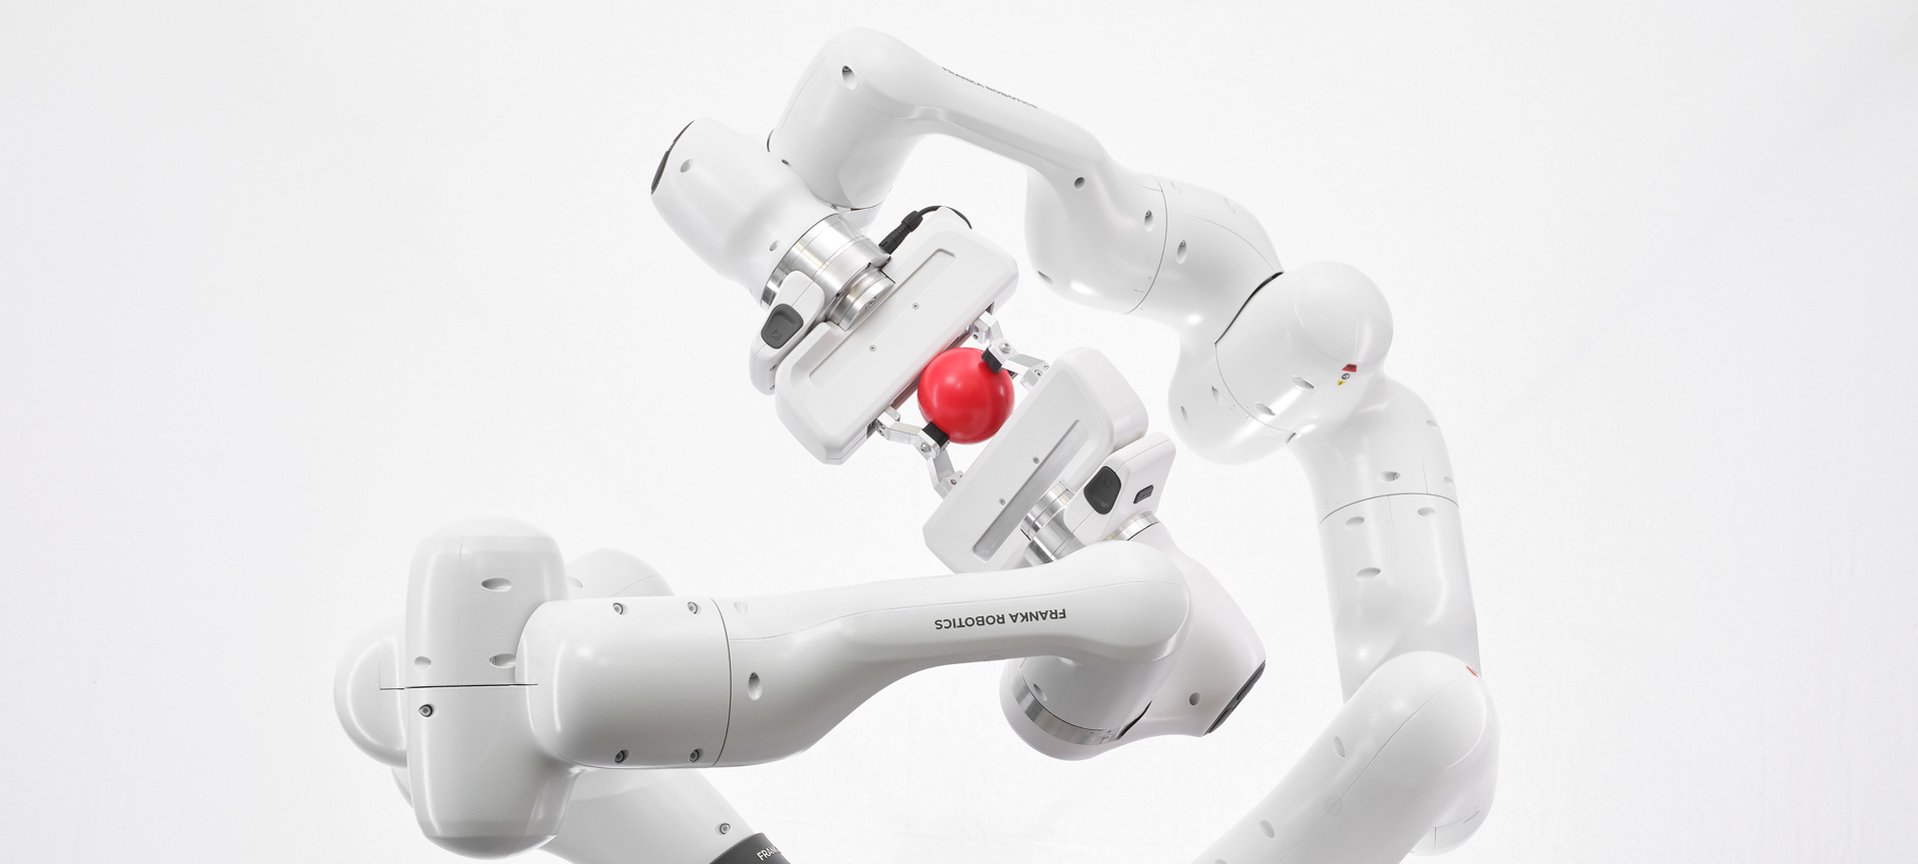
Runs on PiPER by AgileX RoboticsSource and note: PiPERB arxiv.org/html/2610.06617v2 · Retrieved 19 November 2026
Sources retrieved: 19 November 2026 (A, B, C)
- Model type
- World action modelSource and note: Model typeC arxiv.org/abs/2610.06617 · Retrieved 19 November 2026Note. “To this end, we present RealtimeWAM, an extremely efficient WAM variant with one-step action generation and asynchronous inference, addressing these two bottlenecks.”
- What it controls
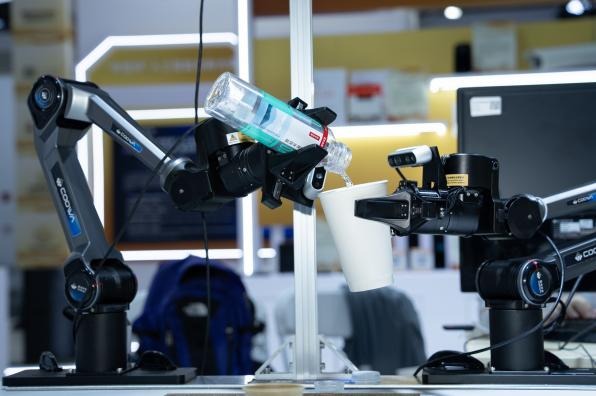
- Arms and handsSource and note: What it controlsB arxiv.org/html/2610.06617v2 · Retrieved 19 November 2026Note. “We additionally evaluate RealtimeWAM on real-world dual-arm manipulation tasks”, “using a bimanual setup comprising two PiPER robotic arms from AgileX Robotics”.
- Inputs
- Camera LanguageSource and note: InputsA huggingface.co/lightx2v/RealtimeWAM · Retrieved 19 November 2026Note. “It includes VAE encoding and video/action inference, while excluding text encoding.”
- Access
- Open weights (download)Source and note: AccessA huggingface.co/lightx2v/RealtimeWAM · Retrieved 19 November 2026Note. “Download the RealtimeWAM checkpoints from [lightx2v/RealtimeWAM](https://huggingface.co/lightx2v/RealtimeWAM) on Hugging Face.”
- Base model
- Fast-WAM / Faster-WAMSource and note: Base modelA huggingface.co/lightx2v/RealtimeWAM · Retrieved 19 November 2026Note. “Our implementation is based on [FastWAM](https://github.com/yuantianyuan01/FastWAM) and [FasterWAM](https://github.com/hustvl/FasterWAM).”
- Licence type
- Free, commercial useSource and note: Licence typeA huggingface.co/lightx2v/RealtimeWAM · Retrieved 19 November 2026Note. Hugging Face model card header: “license: apache-2.0”.
Specifications
8 of 14 stated 6 not stated
5 fields hidden 1 not-stated field with a note stays ·
How to read the figuresShow guideClose
- not statedNo source
- 0Reported as zero
- ASource
Select a source marker for source details and notes.
Release1/1 disclosed
Input and output3/4 disclosed
Size and speed0/2 disclosed
Where it runs and what it is built on1/2 disclosed
Openness3/3 disclosed
The developer’s own claims0/2 disclosed
Notes
Authors affiliated with Nanyang Technological University, Beihang University, Sensetime, and Continental Automotive Singapore; released under ModelTC / LightX2V.
Described by the authors as “To this end, we present RealtimeWAM, an extremely efficient WAM variant with one-step action generation and asynchronous inference, addressing these two bottlenecks.”
Sources
One line per source, not per figure: a source has one retrieval date.
- Ahuggingface.co/lightx2v/RealtimeWAMRetrieved 19 November 2026
- Barxiv.org/html/2610.06617v2Retrieved 19 November 2026
- Carxiv.org/abs/2610.06617Main source. Retrieved 19 November 2026