HKUST(GZ) & OLA Dimensions · robot AI model
UniWAM
China · 2026
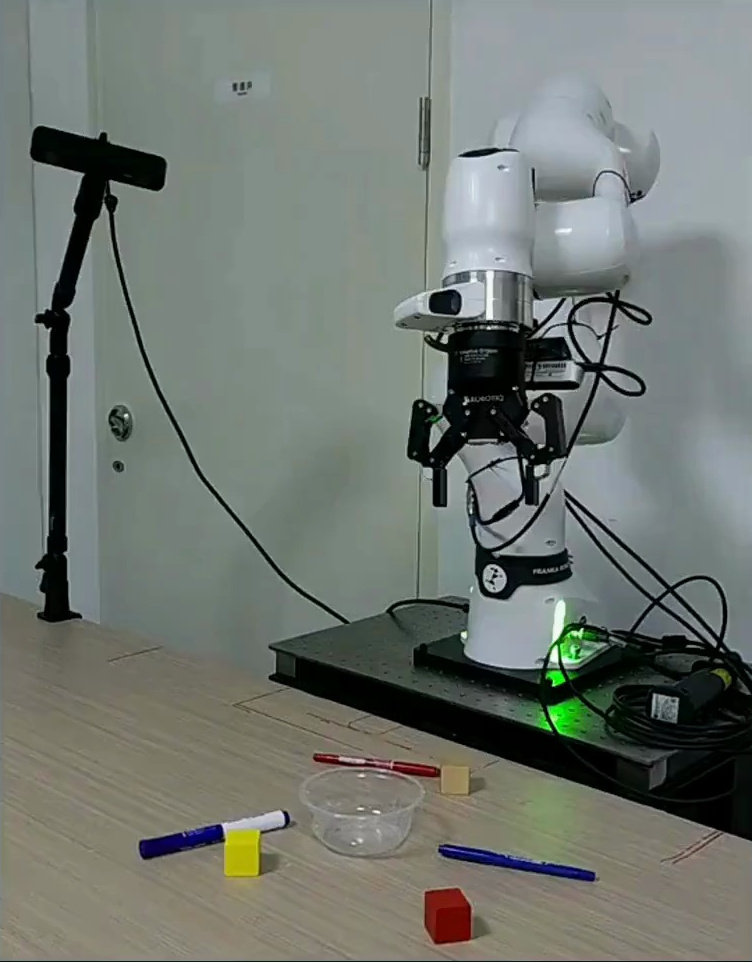
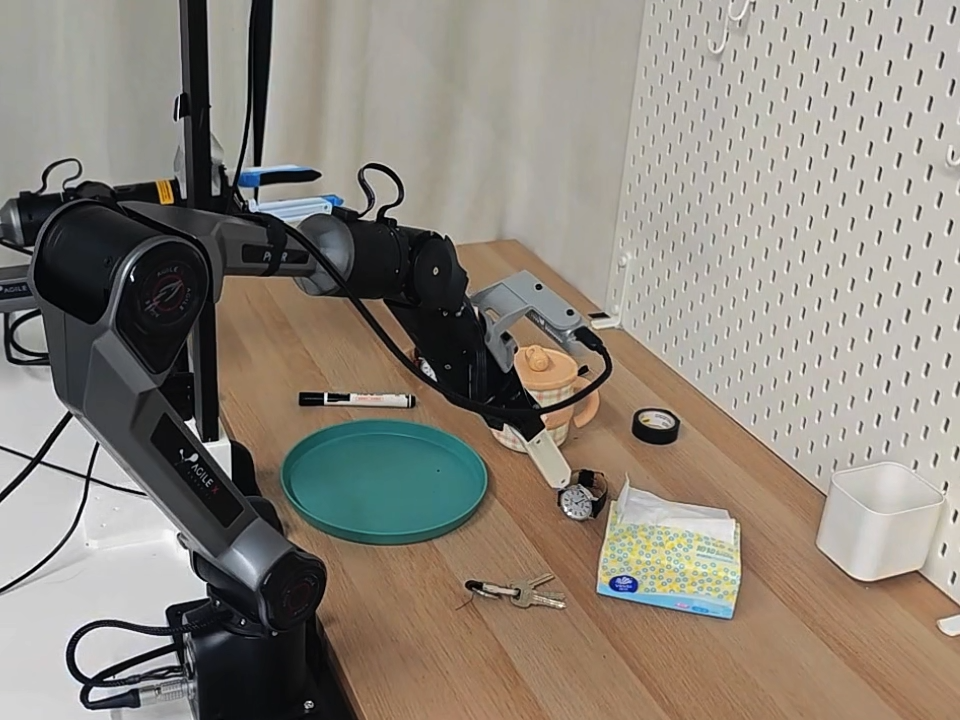
Runs on PiPER by AgileX RoboticsSource and note: PiPERA arxiv.org/abs/2610.02054 · Retrieved 19 November 2026
Sources retrieved: 19 November 2026 (A, B, C, D)
- Model type
- World action modelSource and note: Model typeB raw.githubusercontent.com/UniWAM/UniWAM/main/README.md · Retrieved 19 November 2026Note. Repository title: “# UniWAM: Unified World-Action Model”
- What it controls
- Arms and handsSource and note: What it controlsA arxiv.org/abs/2610.02054 · Retrieved 19 November 2026Note. Real-world evaluation: “Experiments are conducted on the AgileX Piper platform, where each arm has 6-DoF joints and a parallel gripper. Our dual-arm system consists of two Piper”.
- Inputs
- Camera Language Robot stateSource and note: InputsA arxiv.org/abs/2610.02054 · Retrieved 19 November 2026Note. Paper: “Given the current observation ot, proprioceptive state st, and task instruction I, the model learns the joint distribution of language outputs, future observations, and actions”. Real-world cameras: “each equipped with a wrist-mounted camera, together with an additional third-person camera providing a global view of the workspace.”
- Access
- Open weights (download)Source and note: AccessB raw.githubusercontent.com/UniWAM/UniWAM/main/README.md · Retrieved 19 November 2026Note. UniWAM-base and UniWAM-robotwin-clean weights are published on Hugging Face and ModelScope (“pretained checkpoint on mixed robot,human and VQA datasets.”).
- Parameters
- 8BSource and note: ParametersB raw.githubusercontent.com/UniWAM/UniWAM/main/README.md · Retrieved 19 November 2026Note. README: “UniWAM is an 8B-parameter model that brings semantic understanding, visual prediction, and action generation into one MoT architecture.”
- Base model
- Qwen3-VL-2B-Instruct & Wan2.2-TI2V-5BSource and note: Base modelB raw.githubusercontent.com/UniWAM/UniWAM/main/README.md · Retrieved 19 November 2026Note. Pretrained backbones: “Qwen/Qwen3-VL-2B-Instruct” and “Wan-AI/Wan2.2-TI2V-5B”.
- Licence type
- Free, commercial useSource and note: Licence typeC huggingface.co/chenpyyy/UniWAM-base · Retrieved 19 November 2026Note. UniWAM-base model card: “license: apache-2.0”
Specifications
10 of 14 stated 4 not stated
2 fields hidden 2 not-stated fields with a note stay ·
How to read the figuresShow guideClose
- not statedNo source
- 0Reported as zero
- ASource
Select a source marker for source details and notes.
Release1/1 disclosed
Released1 October 2026
Source and note: ReleasedD arxiv.org/abs/2610.02054v1 · Retrieved 19 November 2026Note. arXiv v1: “Submitted on 1 Oct 2026”.
Input and output3/4 disclosed
Model typeWorld action model
Source and note: Model typeB raw.githubusercontent.com/UniWAM/UniWAM/main/README.md · Retrieved 19 November 2026Note. Repository title: “# UniWAM: Unified World-Action Model”
InputsCamera Language Robot state
Source and note: InputsA arxiv.org/abs/2610.02054 · Retrieved 19 November 2026Note. Paper: “Given the current
observation ot, proprioceptive state st, and task instruction I, the model learns the joint distribution of
language outputs, future observations, and actions”. Real-world cameras: “each equipped with a wrist-mounted
camera, together with an additional third-person camera providing a global view of the workspace.”
What it controlsArms and hands
Source and note: What it controlsA arxiv.org/abs/2610.02054 · Retrieved 19 November 2026Note. Real-world evaluation: “Experiments are conducted on the AgileX Piper platform, where each arm has 6-DoF
joints and a parallel gripper. Our dual-arm system consists of two Piper”.
Degrees of freedom controlledNot stated
Source and note: Degrees of freedom controlledA arxiv.org/abs/2610.02054 · Retrieved 19 November 2026Note. Evaluated on a dual-arm setup: “Experiments are conducted on the AgileX Piper platform, where each arm has 6-DoF
joints and a parallel gripper. Our dual-arm system consists of two Piper”.
Size and speed1/2 disclosed
Parameters8B
Source and note: ParametersB raw.githubusercontent.com/UniWAM/UniWAM/main/README.md · Retrieved 19 November 2026Note. README: “UniWAM is an 8B-parameter model that brings semantic understanding, visual prediction, and action generation into one MoT architecture.”
Control rateNot stated
Where it runs and what it is built on1/2 disclosed
On robot or cloudNot stated
Base modelQwen3-VL-2B-Instruct & Wan2.2-TI2V-5B
Source and note: Base modelB raw.githubusercontent.com/UniWAM/UniWAM/main/README.md · Retrieved 19 November 2026Note. Pretrained backbones: “Qwen/Qwen3-VL-2B-Instruct” and “Wan-AI/Wan2.2-TI2V-5B”.
Openness3/3 disclosed
AccessOpen weights (download)
Source and note: AccessB raw.githubusercontent.com/UniWAM/UniWAM/main/README.md · Retrieved 19 November 2026Note. UniWAM-base and UniWAM-robotwin-clean weights are published on Hugging Face and ModelScope (“pretained checkpoint on mixed robot,human and VQA datasets.”).
Licence documentApache-2.0
Source and note: Licence documentC huggingface.co/chenpyyy/UniWAM-base · Retrieved 19 November 2026Note. UniWAM-base model card: “license: apache-2.0”
Licence typeFree, commercial use
Source and note: Licence typeC huggingface.co/chenpyyy/UniWAM-base · Retrieved 19 November 2026Note. UniWAM-base model card: “license: apache-2.0”
The developer’s own claims1/2 disclosed
Learns new tasksNeeds retraining
Source and note: Learns new tasksB raw.githubusercontent.com/UniWAM/UniWAM/main/README.md · Retrieved 19 November 2026Note. Developer README lists “post-trained checkpoint on the clean subset of RoboTwin 2.0.”
Works across robotsNot stated
Source and note: Works across robotsA arxiv.org/abs/2610.02054 · Retrieved 19 November 2026Note. The paper describes “cross-embodiment pretraining” across datasets, but real-world experiments are reported only on a dual-arm AgileX Piper platform (“Experiments are conducted on the AgileX Piper platform, where each arm has 6-DoF
joints and a parallel gripper. Our dual-arm system consists of two Piper”).Yes only if the developer itself says the model runs on different robot models, for example robots from two manufacturers or two of one manufacturer’s models. Several units of the same robot do not count.
Notes
Developers describe UniWAM: “UniWAM is an 8B-parameter model that brings semantic understanding, visual prediction, and action generation into one MoT architecture.”
Core contributors are affiliated with “The Hong Kong University of Science and Technology (Guangzhou)” and “OLA Dimensions”.
Sources
One line per source, not per figure: a source has one retrieval date.
- Aarxiv.org/abs/2610.02054Retrieved 19 November 2026
- Braw.githubusercontent.com/UniWAM/UniWAM/main/README.mdMain source. Retrieved 19 November 2026
- Chuggingface.co/chenpyyy/UniWAM-baseRetrieved 19 November 2026
- Darxiv.org/abs/2610.02054v1Retrieved 19 November 2026