PoWa 10 (CRB 1910-10/1.52)
A robot arm from Sweden, first released 2026.
Sources retrieved: 4 November 2026 (A, B, C, D)
- Status
- In production
- Intended use, per the manufacturer
- Not stated
- Indicative price
- Not stated
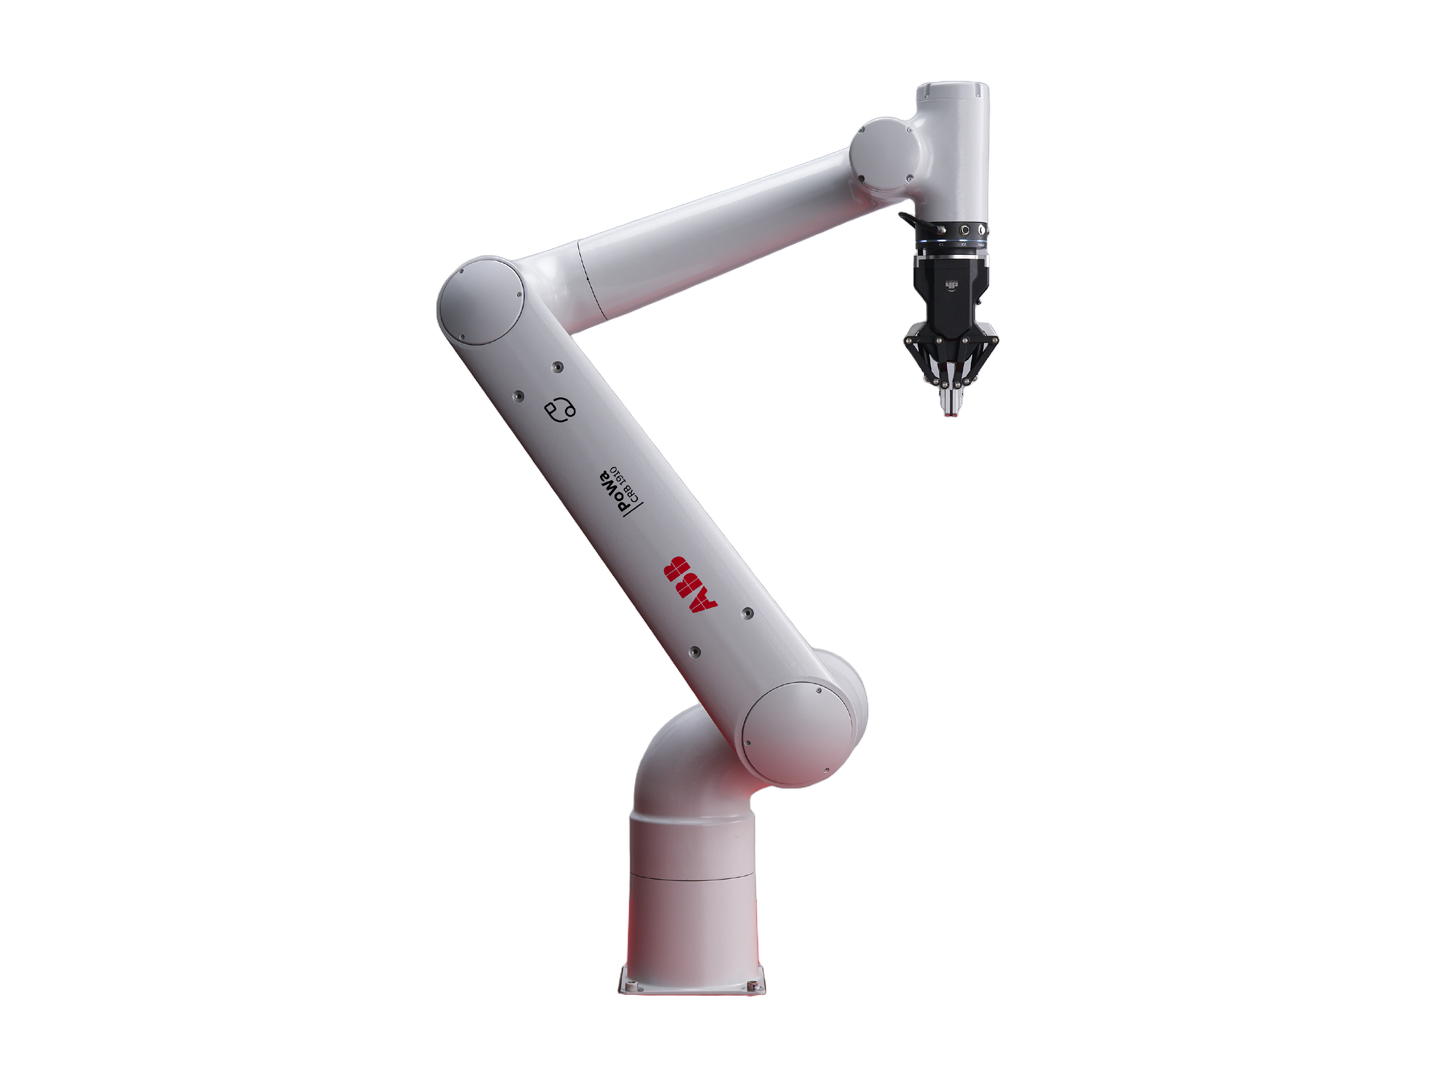
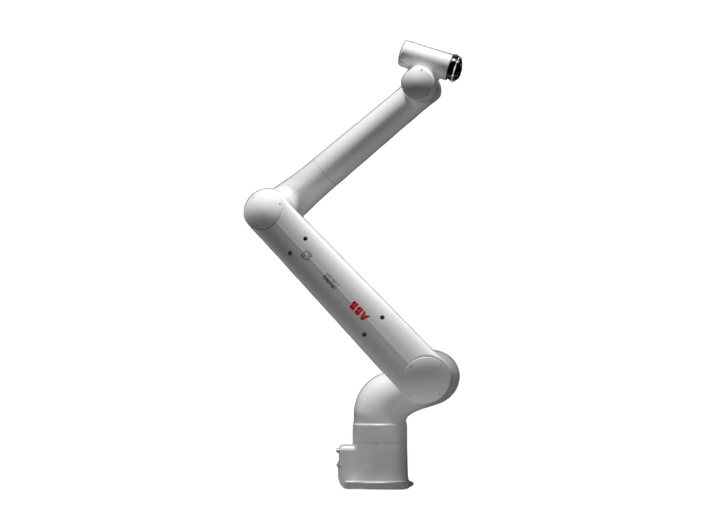
Image from the manufacturer's own datasheet (abb.com); the CRB 1910 datasheet covers PoWa 10 and PoWa 13 and carries this one photo.
Specifications
14 of 22 stated 8 not stated
8 fields hidden
How to read the figuresShow guideClose
- not statedNo source
- noyesStated by a source
- 0Reported as zero
- ASource
- A*Source with a caveat (select it)
- CERecords only what the manufacturer states regarding CE marking.
Select a source marker for source details and notes.
Performance5/5 disclosed
Physical5/5 disclosed
Mounting, power and communication2/4 disclosed
Sensing and autonomy0/2 disclosed
Commercial0/1 disclosed
Compliance & certifications2/5 disclosed
Against the field
Each strip holds every robot of this type in the guide that states the figure, one bar per group of values. Further right means a larger figure, not a better robot. A taller bar means more robots in that group.
Payload
10kg22lbOur conversion from 10 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
50 robot arms state a payload
23 state a higher figure, 22 a lower one. 4 more state exactly the same figure.
Reach
1,670mm65.7inOur conversion from 1.67 m. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
49 robot arms state a reach
13 state a higher figure, 35 a lower one.
Weight
42kg92.6lbOur conversion from 42 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
46 robot arms state a weight
20 state a higher figure, 25 a lower one. Log scale: each step along the axis multiplies the value.
Degrees of freedom
6DoF
45 robot arms state degrees of freedom
12 state a higher figure, 1 a lower one. 30 more state exactly the same figure. 1 states only a bound (≥ or ≤) and is not ranked.
Notes
ABB Robotics launched the PoWa cobot family on 22 April 2026.
ABB states that the PoWa cobot family is now available globally.
The CRB 1910 meets ISO Class 4 cleanroom requirements at 50% rated speed and 100% rated load, and ISO Class 5 at 100% rated speed and 100% rated load.
The lower arm and elbow together can carry up to 7 kg.
Sources
One line per source, not per figure: a source has one retrieval date.
- Asearch.abb.com/library/Download.aspx?DocumentID=3HAC097944-001&LanguageCode=en&DocumentPartId=&Action=LaunchSecondary. Retrieved 4 November 2026
- Bsearch.abb.com/library/Download.aspx?DocumentID=9AKK108471A1046&LanguageCode=en&DocumentPartId=&Action=LaunchSecondary. Retrieved 4 November 2026
- Cabb.com/global/en/areas/robotics/products/robots/collaborative-robots/powaMain source. Retrieved 4 November 2026
- Dsearch.abb.com/library/Download.aspx?DocumentID=3HAC102712-001&LanguageCode=en&DocumentPartId=&Action=LaunchSecondary. Retrieved 4 November 2026
More robots
Same manufacturer
GoFa 10 (CRB 15000-10/1.52)ABB
GoFa 12 (CRB 15000-12/1.27)ABB
IRB 1700-12/1.45ABB
PoWa 13 (CRB 1910-13/1.34)ABB
PoWa 16 (CRB 1920-16/1.96)ABB
PoWa 20 (CRB 1920-20/1.67)ABB