UniX AIChina
Wanda 2.0
- Weight not stated
- Security and surveillance
- Research and development
- Consumer and education
- Entertainment
Key figures as stated by the manufacturer
2 of 6 stated · 4 gaps- Weight not stated
- Payload, moving not stated
- Runtime A 480–960minWarning: load condition not stated
- Max speed A 5.4km/h3.36mphOur conversion from 5.4 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- AI model not stated
- Indicative price not stated
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Robots with several sources carry several letters.
- Payload, moving
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (3)
Payload, moving
Note The page gives "Dual-arm Load Capacity: 12kg" and a 6 kg single-arm payload. Those are arm-specific figures, not figures for what the whole robot can carry.
Runtime
Caveat Given with no load or task condition.
Max speed
Caveat Given as the maximum movement speed of the differential-drive chassis.
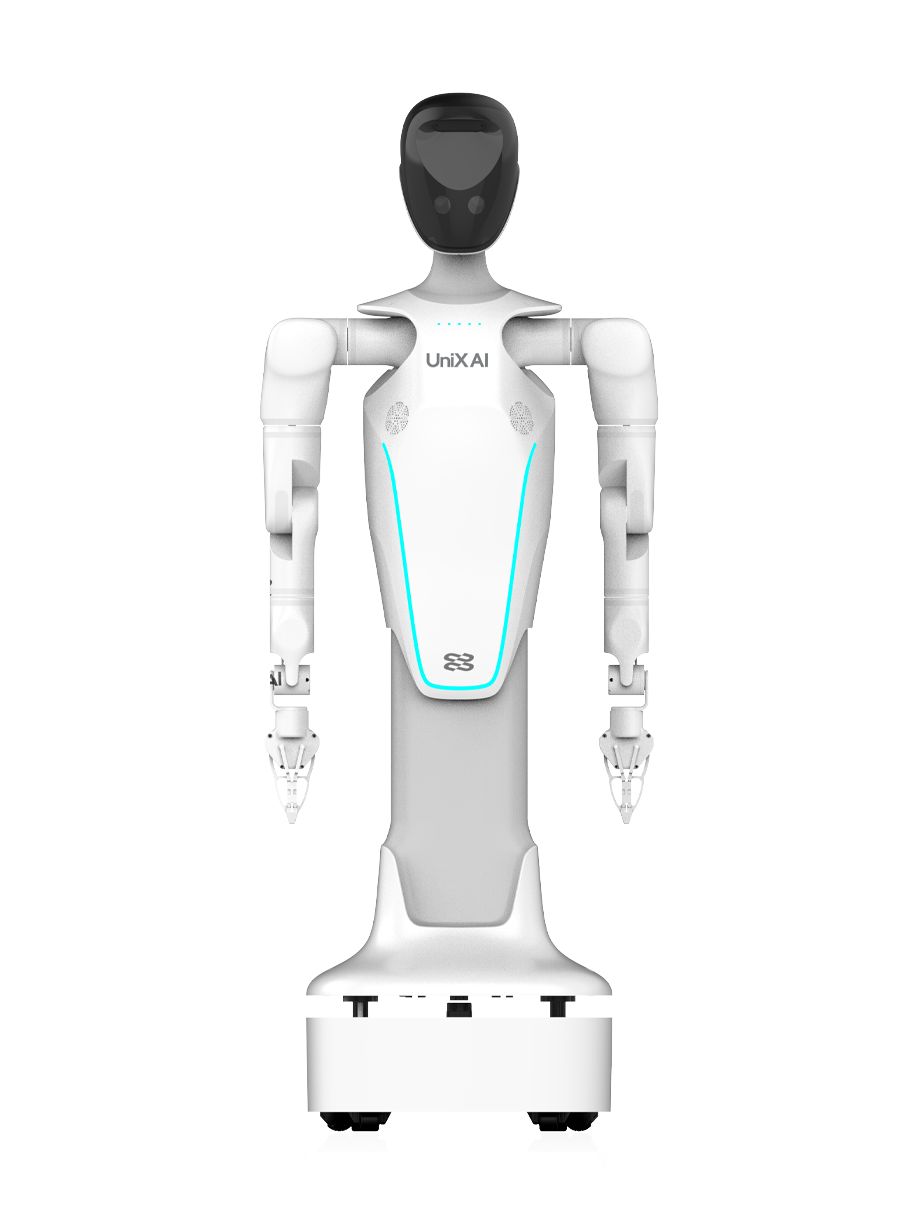
Manufacturer's own photo.
Intended use, per the manufacturer
The manufacturer’s words
We provide scenario-based solutions for reception,security, elderly care, companionship, entertainment , research & education
Source: unix-group.ai · Retrieved
This category is not our assessment.
Full specifications
5 of 32 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | not stated | |
| Length | not stated | |
| Width | not stated | |
| Height | 140–168cm55.1–66.1inOur conversion from 140–168 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Caveat Height range as given in the overview. The Applications page gives a standing height of 168 cm. A |
| Degrees of freedom | not stated | Note The Applications page says "23 high-DoF joints"; the overview lists a 2-DoF head and 8-DoF arms. No total number of degrees of freedom is given. B |
| Payload, moving | not stated | Note The page gives "Dual-arm Load Capacity: 12kg" and a 6 kg single-arm payload. Those are arm-specific figures, not figures for what the whole robot can carry. A |
| Payload, standing | not stated | Note The page gives "Dual-arm Load Capacity: 12kg" and a 6 kg single-arm payload. Those are arm-specific figures, not figures for what the whole robot can carry. A |
| Max speed | 5.4km/h3.36mphOur conversion from 5.4 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Caveat Given as the maximum movement speed of the differential-drive chassis. A |
| Max slope | not stated | |
| Single obstacle | not stated | |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | |
| Runtime | 480–960minWarning: load condition not stated | Caveat Given with no load or task condition. A |
| Hot-swap battery | not stated | |
| Charge time | not stated | |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | 360° LiDAR on the chassis. | Note Chassis System row of the overview; the chassis also carries an ultrasonic sensor. A |
| Cameras | Head-mounted dual RGB camera and RGBD camera. | Note Perception System row of the overview. A |
| Onboard compute | not stated | Note The overview shows a figure of "275 TOPs" with the words "Up to" but no label saying what it measures, and no chip is named. A |
| ROS 2 | not stated | |
| SDK languages | not stated | Note The Applications page speaks of open software and hardware interfaces for customization and names no programming languages. B |
| Autonomy level | not stated | Note The page says the robot comes preloaded with "L4-level" applications; it names no autonomy level for the robot itself. A |
| Payload and expansion | ||
| Mounting interface | not stated | Note The overview names a biomimetic two-finger gripper as the end effector and no mounting interface. A |
| Power out | not stated | |
| Data ports | not stated | |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- UniX AI describes Wanda as a full-size general-purpose humanoid robot with a differential-drive chassis and two 8-DoF arms.
- UniX AI's company timeline lists Wanda 2.0 with the entry: "The world's first 8-degree-of-freedom bionic arm is now available for preorder".
- The same timeline says of Wanda 2.0 mass production: "The mass production plan has been officially launched, marking the start of large-scale implementation".
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for Wanda 2.0https://www.unix-group.ai/wanda/1812
Sources
-
A
Manufacturer product page. www.
unix-group. · Retrievedai/ wanda/ 1812 -
B
www.
unix-group. · Retrievedai/ Applications
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.