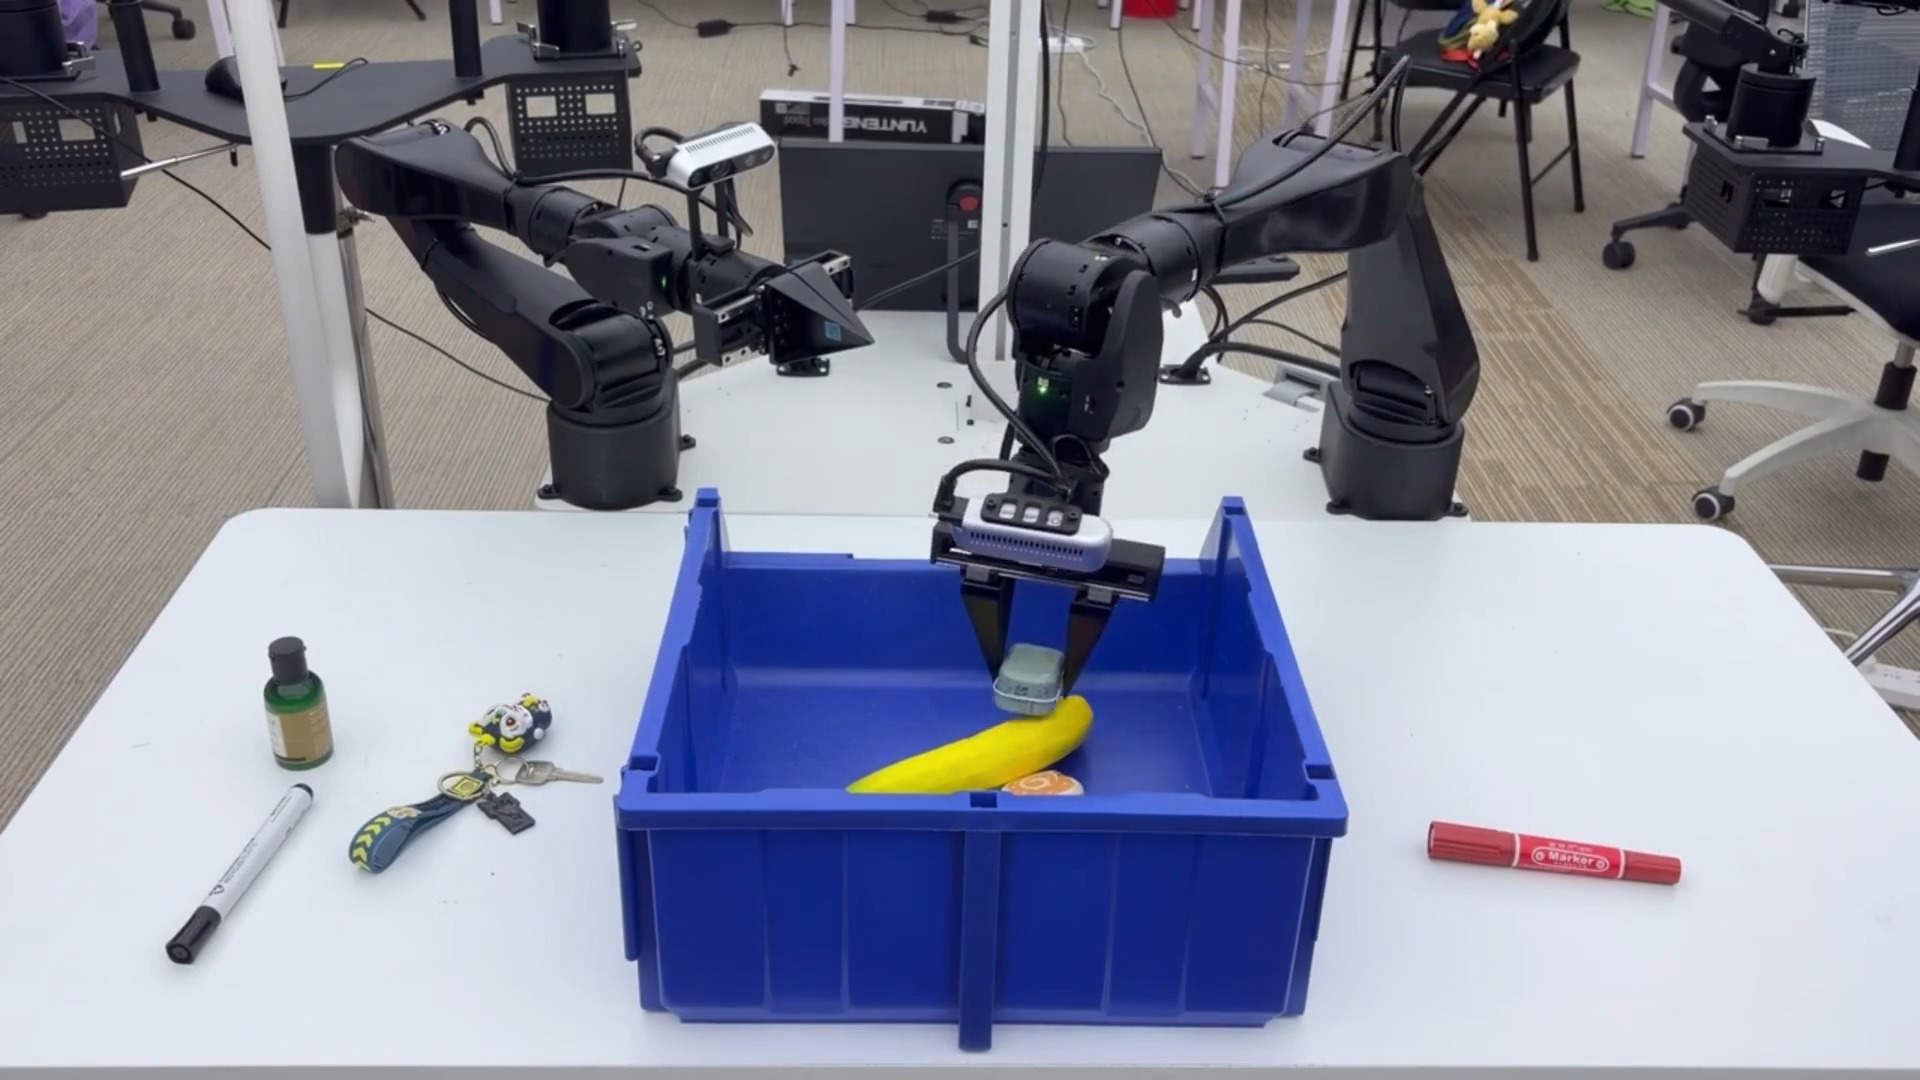
Tsinghua University · robot AI model
UniDex
China · 2026
Sources retrieved: 13 November 2026 (A, B, C, D)
- Model type
- Vision-language-action (VLA)Source and note: Model typeC arxiv.org/abs/2603.22264 · Retrieved 13 November 2026Note. Developer wording: “with a unified vision-language-action (VLA) policy”.
- What it controls
- Arms and handsSource and note: What it controlsA unidex-ai.github.io · Retrieved 13 November 2026Note. Project page: UniDex-VLA takes point clouds, language and proprioception “and predicts dexterous action chunks in FAAS”; FAAS is the shared action space across dexterous hands.
- Inputs
- Depth Language Robot stateSource and note: InputsA unidex-ai.github.io · Retrieved 13 November 2026Note. Project page: UniDex-VLA is a 3D vision-language-action policy “that takes pointcloud observations,” “language instructions, and proprioception”.
- Access
- Open weights (download)Source and note: AccessB huggingface.co/UniDex-ai/UniDex · Retrieved 13 November 2026Note. Hugging Face repository: it “hosts the released” UniDex models; contents include “Model checkpoints” for pretraining and downstream use.
Specifications
7 of 14 stated 7 not stated
5 fields hidden 2 not-stated fields with a note stay ·
How to read the figuresShow guideClose
- not statedNo source
- yesStated by a source
- 0Reported as zero
- ASource
Select a source marker for source details and notes.
Release1/1 disclosed
Released23 March 2026
Source and note: ReleasedC arxiv.org/abs/2603.22264 · Retrieved 13 November 2026Note. arXiv listing: “Submitted on 23 Mar 2026”.
Input and output3/4 disclosed
Model typeVision-language-action (VLA)
Source and note: Model typeC arxiv.org/abs/2603.22264 · Retrieved 13 November 2026Note. Developer wording: “with a unified vision-language-action (VLA) policy”.
InputsDepth Language Robot state
Source and note: InputsA unidex-ai.github.io · Retrieved 13 November 2026Note. Project page: UniDex-VLA is a 3D vision-language-action policy “that takes pointcloud observations,” “language instructions, and proprioception”.
What it controlsArms and hands
Source and note: What it controlsA unidex-ai.github.io · Retrieved 13 November 2026Note. Project page: UniDex-VLA takes point clouds, language and proprioception “and predicts dexterous action chunks in FAAS”; FAAS is the shared action space across dexterous hands.
Degrees of freedom controlledNot stated
Size and speed0/2 disclosed
ParametersNot stated
Control rateNot stated
Where it runs and what it is built on0/2 disclosed
On robot or cloudNot stated
Base modelNot stated
Source and note: Base modelD github.com/unidex-ai/UniDex · Retrieved 13 November 2026Note. The setup instructions require pretrained assets including “PaliGemma tokenizer and weights”.
Openness1/3 disclosed
AccessOpen weights (download)
Source and note: AccessB huggingface.co/UniDex-ai/UniDex · Retrieved 13 November 2026Note. Hugging Face repository: it “hosts the released” UniDex models; contents include “Model checkpoints” for pretraining and downstream use.
Licence documentNot stated
Source and note: Licence documentB huggingface.co/UniDex-ai/UniDex · Retrieved 13 November 2026Note. The model repository states no licence. The code repository README shows an MIT licence badge, which covers the code.
Licence typeNot stated
The developer’s own claims2/2 disclosed
Learns new tasksNeeds retraining
Source and note: Learns new tasksC arxiv.org/abs/2603.22264 · Retrieved 13 November 2026Note. Paper abstract: “a 3D VLA policy pretrained on UniDex-Dataset and finetuned with task demonstrations”.
Works across robotsYes
Source and note: Works across robotsC arxiv.org/abs/2603.22264 · Retrieved 13 November 2026Note. Paper abstract: the action space is built for “enabling cross-hand transfer”; the dataset spans “across eight dexterous hands”.Yes only if the developer itself says the model runs on different robot models, for example robots from two manufacturers or two of one manufacturer’s models. Several units of the same robot do not count.
Notes
The project page lists most authors at “Tsinghua University” and “Shanghai Qizhi Institute”, with one each from Sun Yat-sen University and the University of North Carolina at Chapel Hill.
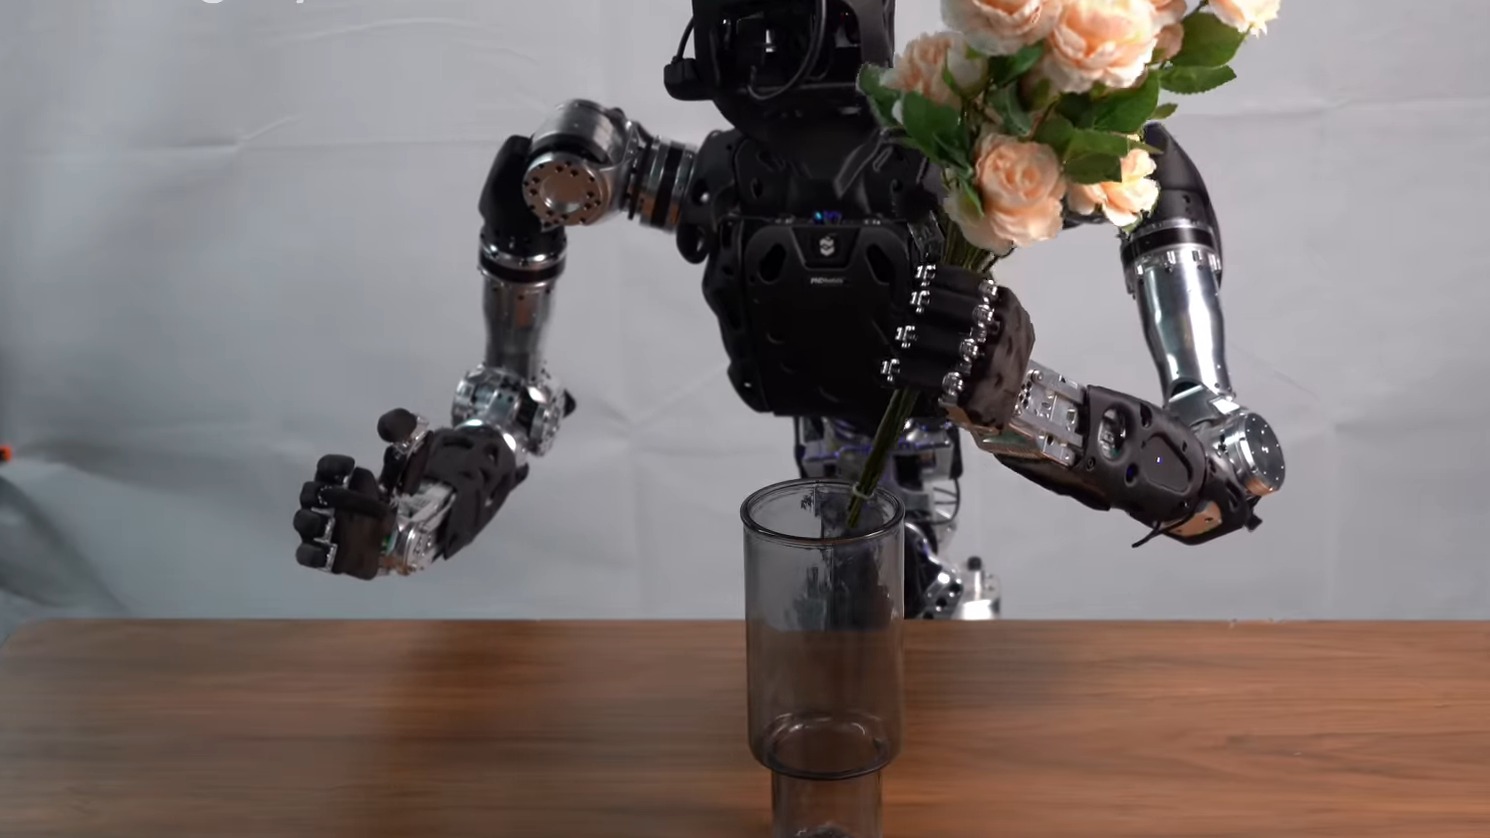
The developer calls UniDex “a robot foundation suite”: the UniDex-VLA policy, a dataset “across eight dexterous hands” and a portable data-capture setup.
Sources
One line per source, not per figure: a source has one retrieval date.
- Aunidex-ai.github.ioMain source. Retrieved 13 November 2026
- Bhuggingface.co/UniDex-ai/UniDexRetrieved 13 November 2026
- Carxiv.org/abs/2603.22264Retrieved 13 November 2026
- Dgithub.com/unidex-ai/UniDexRetrieved 13 November 2026