Istituto Italiano di Tecnologia (IIT)
HyQReal
A quadruped robot from Italy, first released 2019.
Sources retrieved: 4 September 2026 (A)
- Status
- Demonstrator
- Applications
- Indicative price
- Not stated
- Intended use, per the manufacturer
- Designed to support humans in emergency scenarios, disaster response, and hazardous environments.Source and note: Intended use, per the manufacturerA dls.iit.it/hyqreal · Retrieved 4 September 2026
- Person
175 cm68.9 in - 135 cm53.1 inHeight
90 cm35.4 in
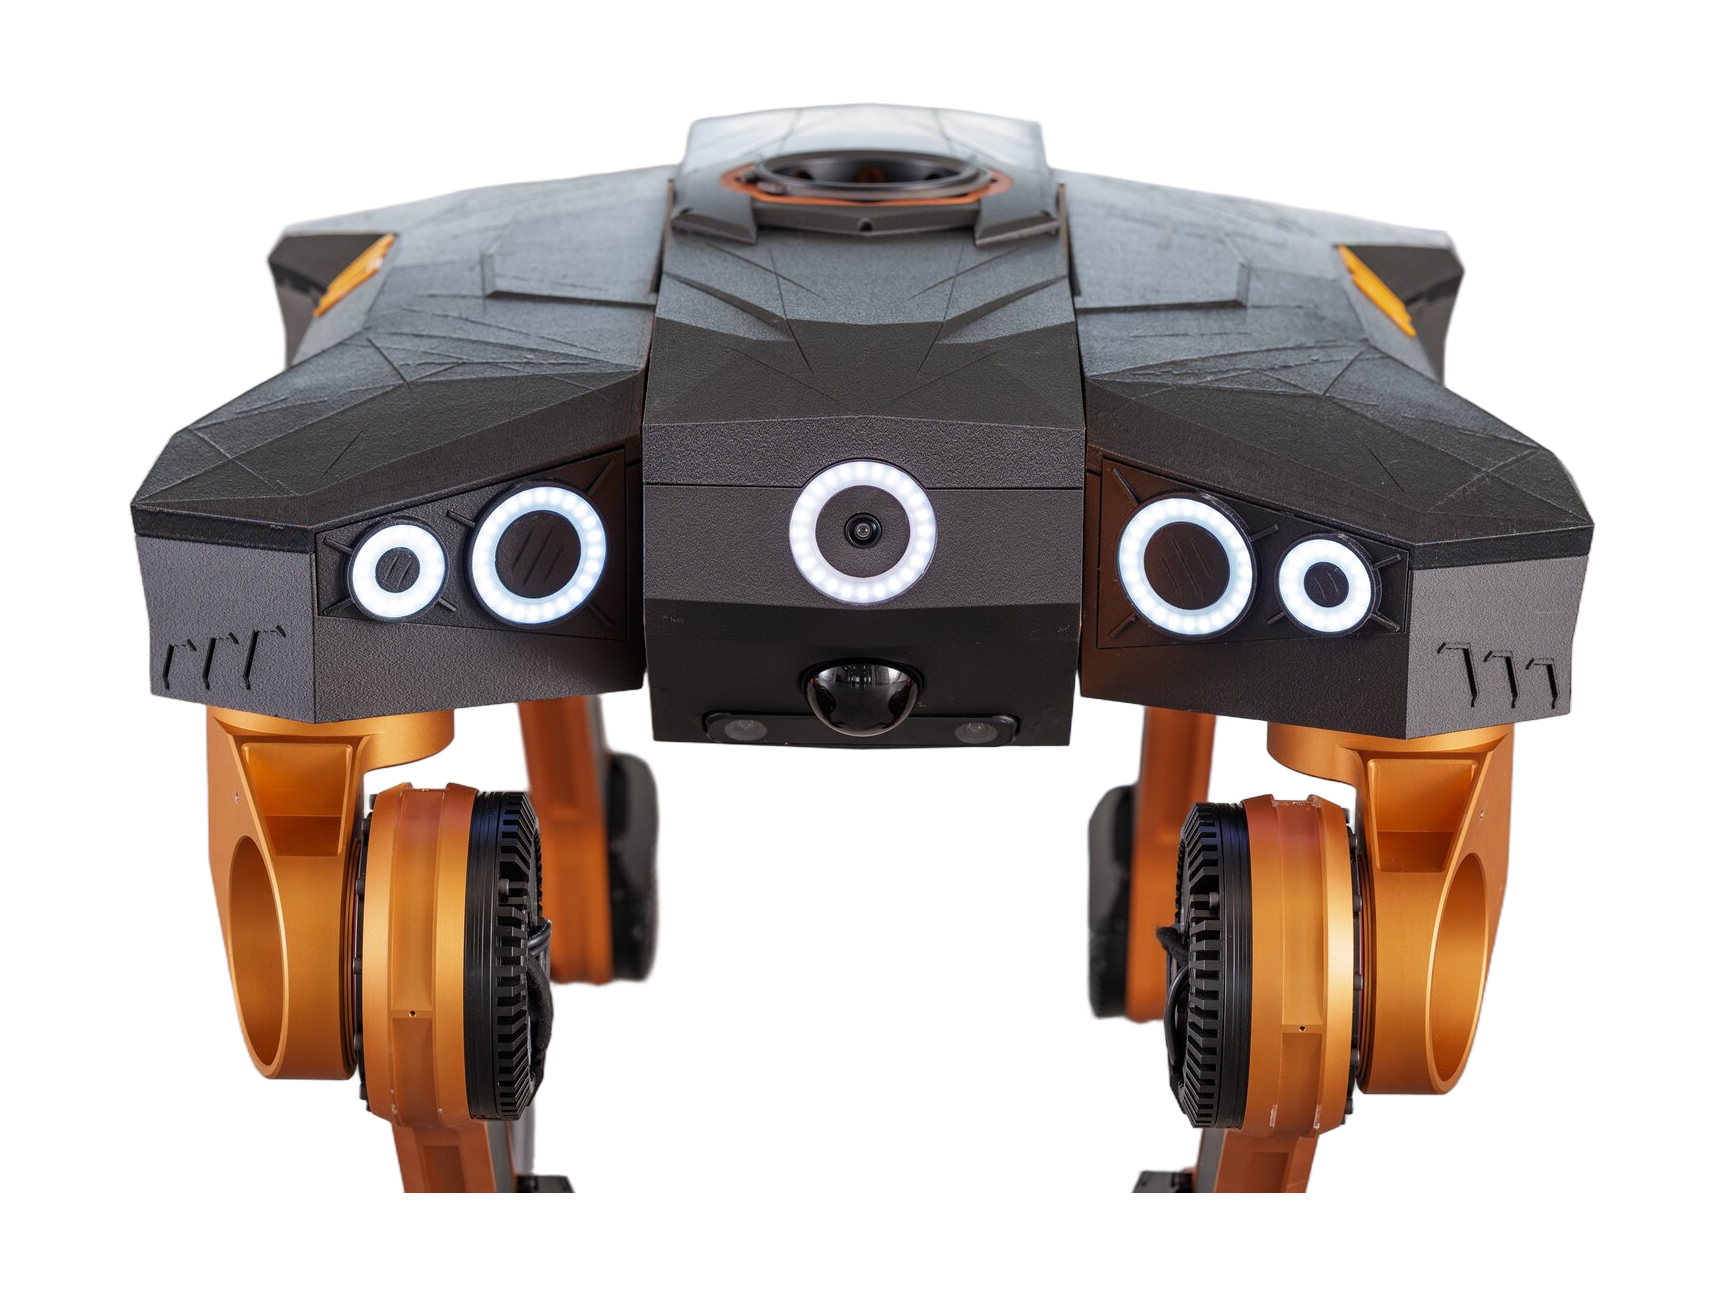
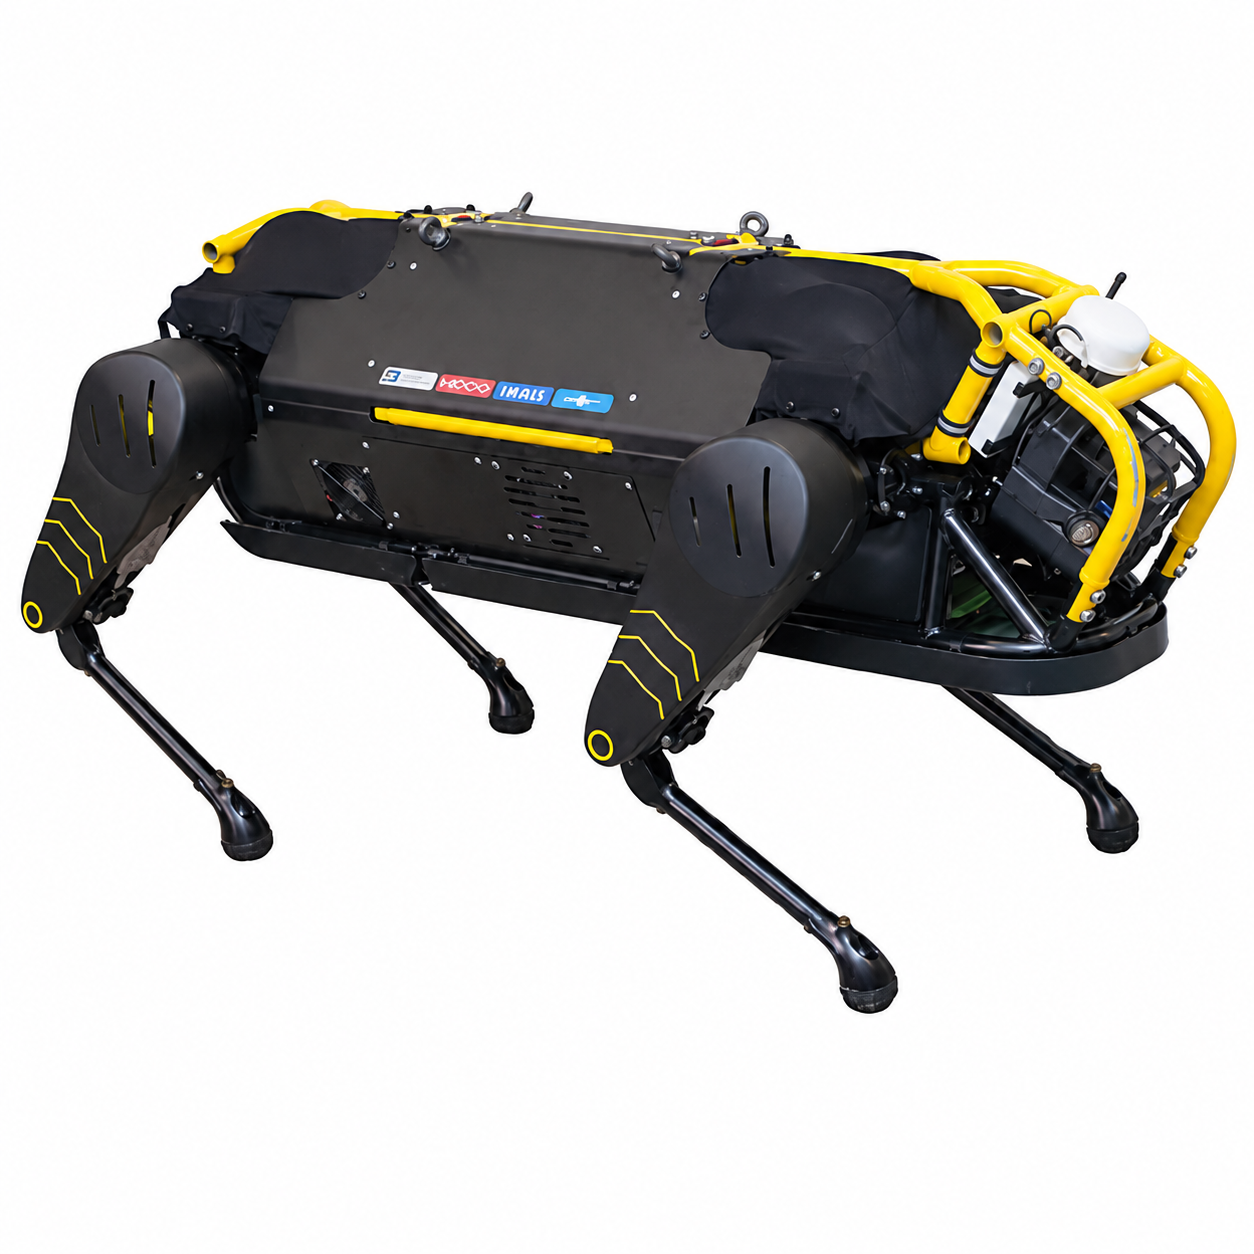
Manufacturer's own photo.
Drawn at one scale next to a 175 cm person, from the figures the maker states: height 90 cm and length 135 cm.Drawn at one scale next to a 68.9 in person, from the figures the maker states, converted to inches: height 35.4 in and length 53.1 in.
Specifications
5/33 specifications disclosed 28 not stated
28 fields hidden
Not statedThe manufacturer states nothing about this field.NoStated: the robot does not have this.A marker with an asterisk (*) also carries a caveat.
Select a source marker for source details and notes.
Physical4/14 disclosed
Power0/5 disclosed
Sensing and autonomy1/6 disclosed
Payload and expansion0/3 disclosed
Commercial0/1 disclosed
Compliance & certifications0/4 disclosed
Against the field
Each strip holds every robot of this type in the guide that states the figure, one bar per group of values. Further right means a larger figure, not a better robot.
Height
90cm35.4inOur conversion from 900 mm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
89 quadrupeds state a height
4 state a higher figure, 83 a lower one.
Weight
140kg309lbOur conversion from 140 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
124 quadrupeds state a weight
5 state a higher figure, 118 a lower one. Log scale: each step along the axis multiplies the value.
Degrees of freedom
12DoF
76 quadrupeds state degrees of freedom
15 state a higher figure, 4 a lower one. 56 more state exactly the same figure.
Notes
A heavy-duty hydraulic quadruped from IIT's Dynamic Legged Systems lab, built with Moog, using an aluminum roll cage and Kevlar/fiberglass skin.
A 48V battery drives four electric motors and hydraulic pumps; in 2019 it famously towed a 3,300 kg Piaggio P180 Avanti airplane.
Sources
One line per source, not per figure: a source has one retrieval date.
- Adls.iit.it/hyqrealMain source. Retrieved 4 September 2026