Key figures as stated by the manufacturer
0 of 6 stated · 6 gapsThe manufacturer states none of the 6 key figures.
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Robots with several sources carry several letters.
- Payload, moving
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
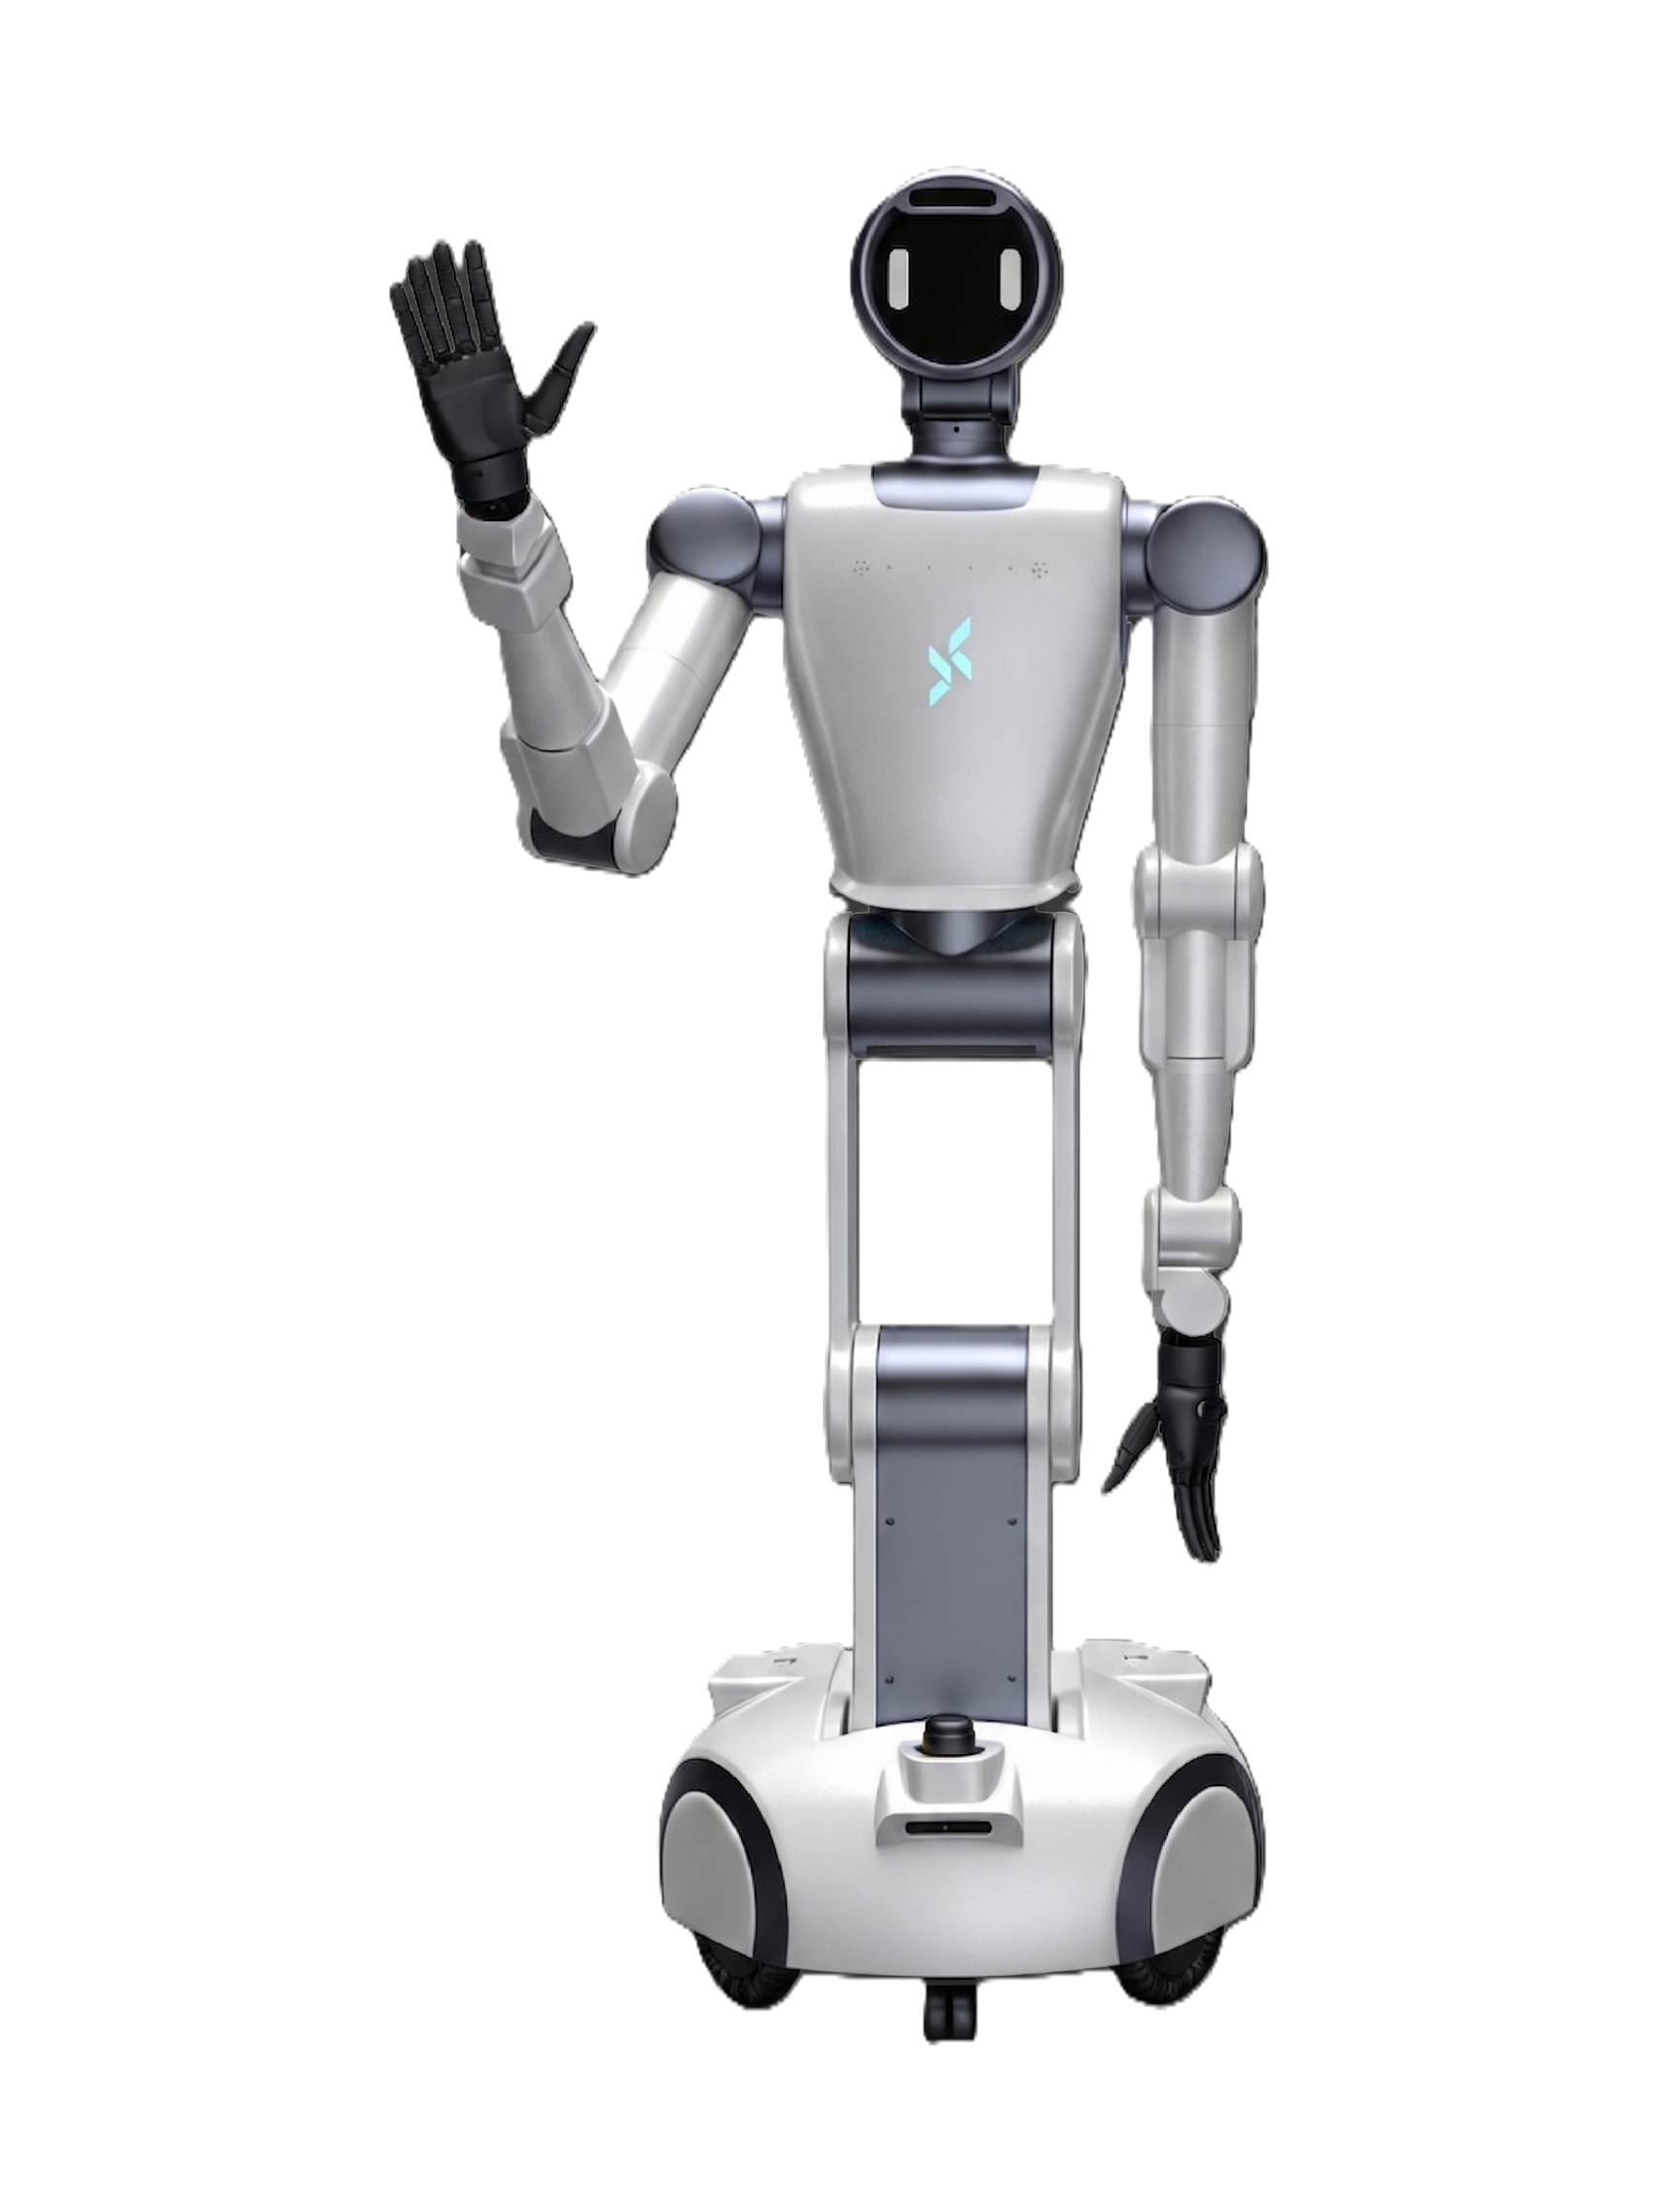
Manufacturer's own photo.
Intended use, per the manufacturer
The manufacturer’s words
Support material circulation, station delivery, and line-side handoff across production flows.
Source: daxrobotics.cn · Retrieved
This category is not our assessment.
Full specifications
2 of 32 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | not stated | |
| Length | not stated | |
| Width | not stated | |
| Height | not stated | |
| Degrees of freedom | 26DoF | Note Whole-body figure on the product callout; no breakdown by body part is given. A |
| Payload, moving | not stated | |
| Payload, standing | not stated | Caveat The callout gives 15 kg for the two arms together. That is an arm-specific figure, not a figure for what the whole robot can carry. A |
| Max speed | not stated | |
| Max slope | not stated | |
| Single obstacle | not stated | |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | |
| Runtime | not stated | |
| Hot-swap battery | not stated | |
| Charge time | not stated | |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | not stated | |
| Cameras | not stated | |
| Onboard compute | 8-core CPU and 200 TOPS GPU. | Note The callout adds that sensing and interaction are optional; no chip is named. A |
| ROS 2 | not stated | |
| SDK languages | not stated | Caveat The English product card lists open interfaces and APIs for secondary development under the X7 Pro; the Chinese card lists that line under the X7 EDU and gives the X7 Pro an on-device language model instead. No programming language is named. A |
| Autonomy level | not stated | Caveat The tagline says fully autonomous with an on-device language model; no autonomy level is named. A |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | |
| Data ports | not stated | |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- The producer sells the X7 in two versions, X7 EDU and X7 Pro; the X7 EDU is tagged for teaching and R&D, and the X7 Pro for an on-device language model and full autonomy.
- The producer's photo shows a head, a torso with two arms and hands, and a wheeled base.
- The producer lists a 70 cm single arm that takes a gripper or a dexterous hand.
- The base is a vector chassis with 6 degrees of freedom and 360° omni-directional movement.
- The manufacturer's website signs itself "DAX Robotics"; the Qiji robot horses on the same site are listed here under DaxAI Robotics.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for X7 Prohttps://www.daxrobotics.cn/
Sources
-
A
Manufacturer product page. www.
daxrobotics. · Retrievedcn/
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.