Key figures as stated by the manufacturer
3 of 6 stated · 3 gaps- Weight A 31.8kgOur conversion from 70 lb. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.70lb
- Payload, moving not stated
- Runtime A 600–720minWarning: load condition not stated
- Max speed A 2.88–4.32km/h1.79–2.68mphOur conversion from 2.88–4.32 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- AI model not stated
- Indicative price not stated
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Robots with several sources carry several letters.
- Payload, moving
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (3)
Weight
Note Weight in the specification sheet, which describes a reference configuration.
Runtime
Caveat The sheet gives a target range of up to 10–12 hours, depending on configuration; no load condition is given.
Max speed
Note Maximum speed, given as a range in the specification sheet.
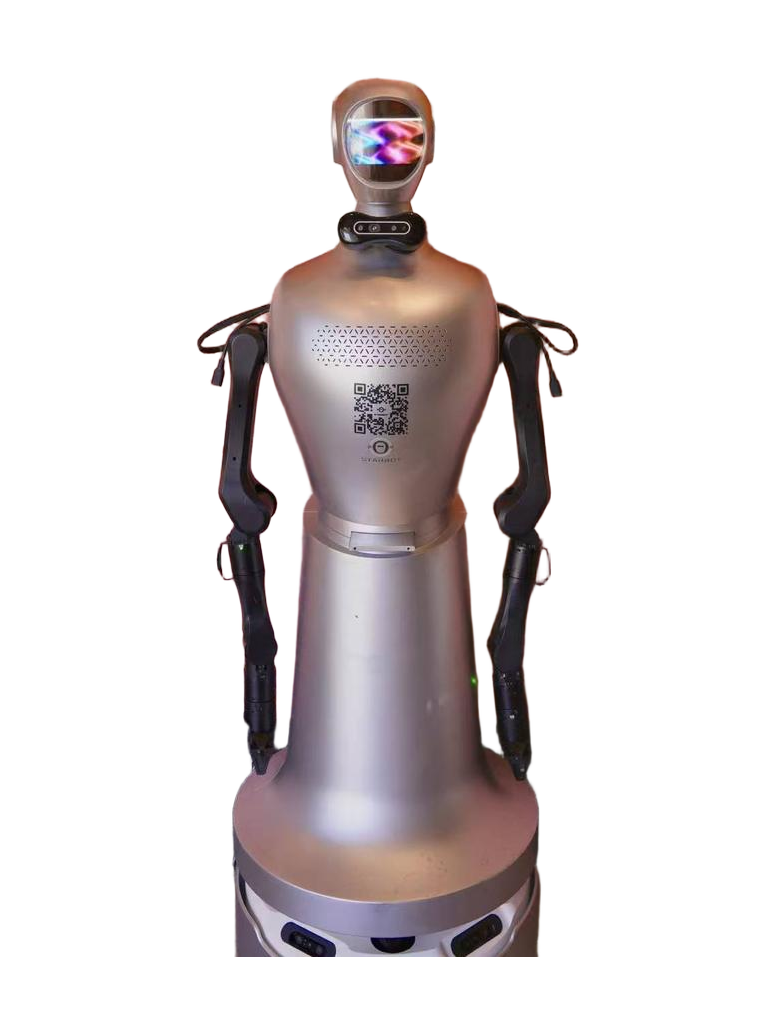
Manufacturer's own photo.
Intended use, per the manufacturer
Source: starbotusa.com · Retrieved
StarBot calls Nova its first-generation humanoid service robot and describes its wheeled service platforms as designed for continued testing in restaurant, hospitality, retail and related environments, without naming a single use.
This category is not our assessment.
Full specifications
6 of 32 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | 31.8kgOur conversion from 70 lb. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.70lb | Note Weight in the specification sheet, which describes a reference configuration. A |
| Length | not stated | |
| Width | not stated | |
| Height | 152.4cm60inOur conversion from 152.4 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Height in the specification sheet, which describes a reference configuration. A |
| Degrees of freedom | not stated | |
| Payload, moving | not stated | |
| Payload, standing | not stated | Caveat The sheet gives an arm payload of up to 2–3 kg. That is an arm-specific figure, not a figure for what the whole robot can carry. A |
| Max speed | 2.88–4.32km/h1.79–2.68mphOur conversion from 2.88–4.32 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Maximum speed, given as a range in the specification sheet. A |
| Max slope | not stated | |
| Single obstacle | not stated | |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | |
| Runtime | 600–720minWarning: load condition not stated | Caveat The sheet gives a target range of up to 10–12 hours, depending on configuration; no load condition is given. A |
| Hot-swap battery | not stated | |
| Charge time | 180min | Note Charging time in the specification sheet. A |
| Docking station | not stated | Caveat The sheet says docking options vary by configuration. A |
| Sensing and autonomy | ||
| LiDAR | not stated | |
| Cameras | Depth cameras (Intel RealSense class) and an RGB camera. | Note The sensor row lists the depth cameras and the RGB camera together with an IMU. A |
| Onboard compute | not stated | |
| ROS 2 | not stated | |
| SDK languages | not stated | |
| Autonomy level | not stated | Caveat The sheet says Nova runs autonomous workflows with optional remote support; it names no autonomy level. A |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | |
| Data ports | not stated | |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- StarBot describes itself as a Santa Barbara robotics company building embodied-AI platforms for education, university research and real-world service operations.
- StarBot dates the launch of Nova to December 2025 and describes it as a wheeled base with two 7-DOF arms.
- StarBot calls Nova its first-generation humanoid service robot and an interface for supervised voice, navigation and service-workflow research.
- The specification sheet lists customer greeting, store navigation and guidance, product and service explanation, and queue management as functions.
- The specification sheet lists English, Spanish and Italian as voice languages, customizable.
- StarBot says the specification sheet describes a Nova reference configuration that may vary by model, options, software release and operating environment.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for Novahttps://www.starbotusa.com/
Sources
-
A
Manufacturer product page. www.
starbotusa. · Retrievedcom/ -
B
www.
starbotusa. · Retrievedcom/ features
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.