MIT Biomimetic Robotics Laboratory
MIT Cheetah 2
A quadruped robot from the United States, first released 2014.
Sources retrieved: 6 September 2026 (A, B, C)
- Status
- Discontinued
- Applications
- Indicative price
- Not stated
- Intended use, per the manufacturer
- MIT researchers have built a robotic cheetah that can now run and jump over hurdles, autonomously, as it runs.Source and note: Intended use, per the manufacturerC news.mit.edu/2014/mit-cheetah-robot-runs-jumps-0915 · Retrieved 6 September 2026
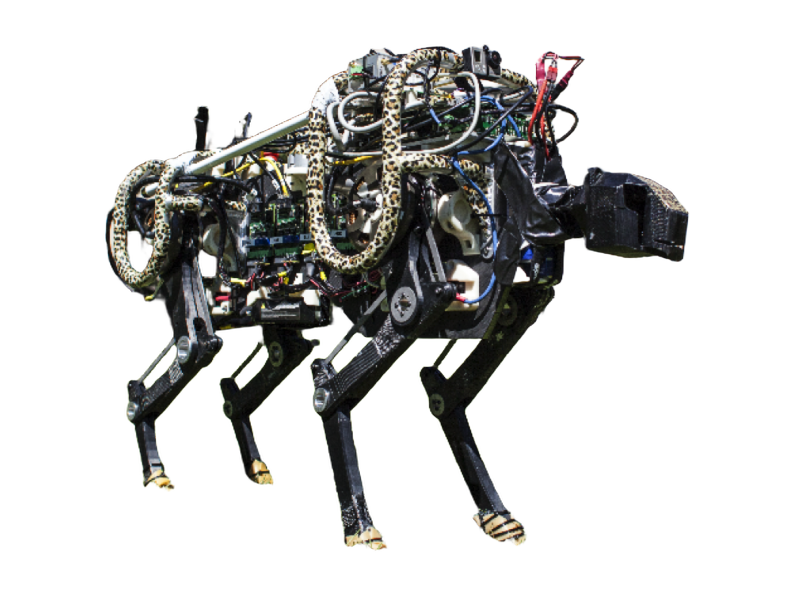
Manufacturer's own photo.
Specifications
3/33 specifications disclosed 30 not stated
30 fields hidden
Not statedThe manufacturer states nothing about this field.NoStated: the robot does not have this.A marker with an asterisk (*) also carries a caveat.
Select a source marker for source details and notes.
Physical2/14 disclosed
Power0/5 disclosed
Sensing and autonomy1/6 disclosed
Payload and expansion0/3 disclosed
Commercial0/1 disclosed
Compliance & certifications0/4 disclosed
Against the field
Each strip holds every robot of this type in the guide that states the figure, one bar per group of values. Further right means a larger figure, not a better robot.
Max speed
at most 23.04km/hat most 14.3mphOur conversion from 6.4 m/s. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
113 quadrupeds state a top speed
MIT Cheetah 2 states an upper limit, not one figure, so it is shown open-ended and not ranked against the others.
Notes
MIT's second-generation running quadruped, first shown running and jumping fully untethered outdoors on MIT's Killian Court lawn in September 2014.
A later peer-reviewed controller for this force-control bounding algorithm reached a minimum cost of transport of 0.47.
Sources
One line per source, not per figure: a source has one retrieval date.
- Abiomimetics.mit.edu/publications/8eaeee8a-5435-426f-a761-45d6e62190dd/Main source. Retrieved 6 September 2026
- Bbiomimetics.mit.edu/research/6339b35c-124a-43da-8749-c2a777566065/Retrieved 6 September 2026
- Cnews.mit.edu/2014/mit-cheetah-robot-runs-jumps-0915Retrieved 6 September 2026