Dexmal · robot AI model
DW0.5
China · 2026
Sources retrieved: 10 November 2026 (A, B, C)
- Model type
- World modelSource and note: Model typeA github.com/dexmal/opendw · Retrieved 10 November 2026Note. GitHub README: “DW05 is a multimodal world model for embodied decision-making, designed to understand how actions shape future outcomes in robot environments.” The Hugging Face tags also list world-action-model.
- What it controls
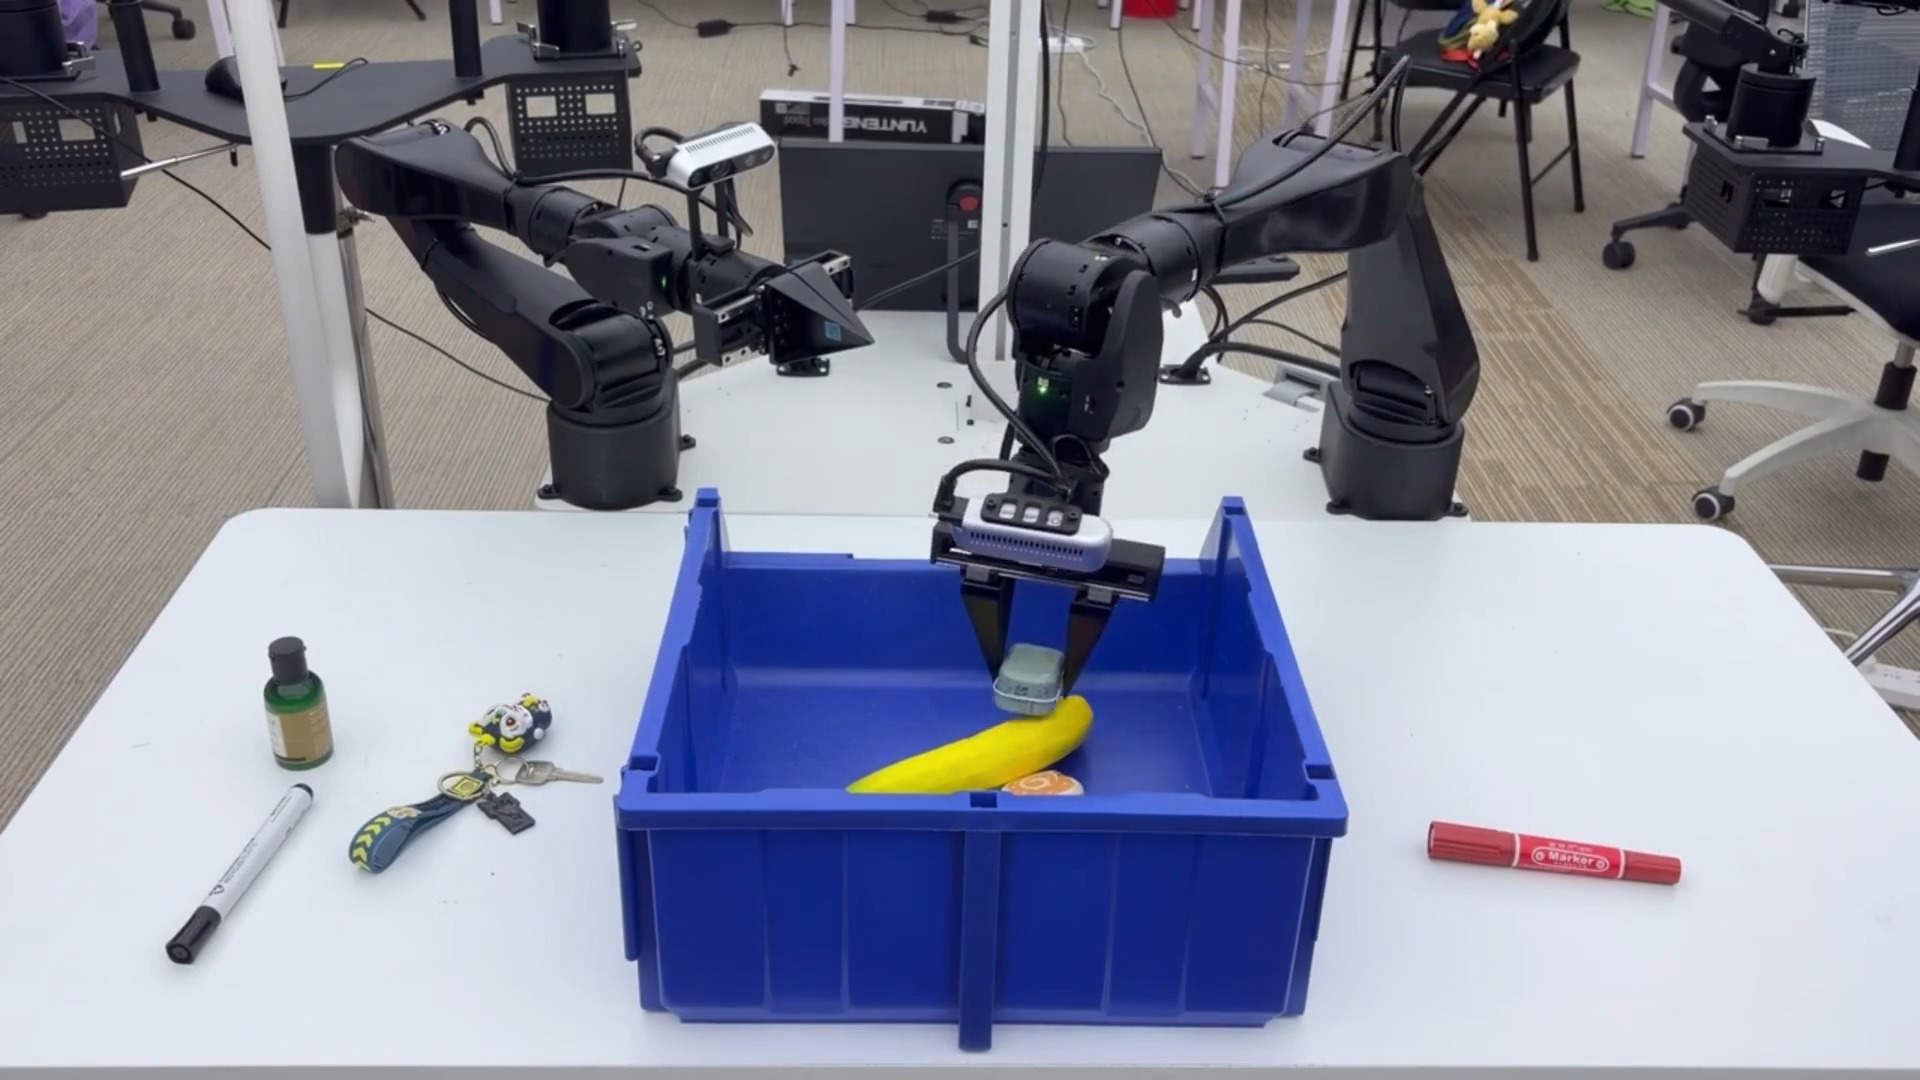
- Arms and handsSource and note: What it controlsB dexmal.com/blog/dw0.5?lang=en-US · Retrieved 10 November 2026Note. GitHub README: “It unifies future video prediction, action generation, and state-value estimation in one framework, with released weights, inference code, and training code.” The blog evaluates the action policy on two arms: “RoboTwin2.0 directly evaluates action-policy capability in a dual-arm simulation environment.”
- Inputs
- Camera Language Robot stateSource and note: InputsA github.com/dexmal/opendw · Retrieved 10 November 2026Note. GitHub README: “DW05 uses language, image/video, robot type, state, and action inputs for embodied world modeling.”
- Access
- Open weights (download)Source and note: AccessA github.com/dexmal/opendw · Retrieved 10 November 2026Note. GitHub README, model preparation: “huggingface-cli download Dexmal/DW05-Base --local-dir ./checkpoints/DW05-Base”. The Hugging Face repository is listed as not gated.
- Base model
- Wan2.2Source and note: Base modelC huggingface.co/Dexmal/DW05-Base · Retrieved 10 November 2026Note. Hugging Face model card: “This release is trained from and used with open third-party components, including Wan2.2 and uMT5-compatible tokenizer/text components.” GitHub README: “It follows an MoT framework where a Wan backbone is followed by three expert heads for video, action, and value modeling.”
- Licence type
- Free, commercial useSource and note: Licence typeA github.com/dexmal/opendw · Retrieved 10 November 2026Note. GitHub README: “It unifies future video prediction, action generation, and state-value estimation in one framework, with released weights, inference code, and training code.” Hugging Face model card: “This DW05-Base release is distributed under the Apache License 2.0.”
Specifications
10 of 14 stated 4 not stated
3 fields hidden 1 not-stated field with a note stays ·
How to read the figuresShow guideClose
- not statedNo source
- yesStated by a source
- 0Reported as zero
- ASource
Select a source marker for source details and notes.
Release1/1 disclosed
ReleasedJuly 2026
Source and note: ReleasedA github.com/dexmal/opendw · Retrieved 10 November 2026Note. [A] GitHub README, latest updates: “2026-07: Initial DW05 public release with weights and inference code.”
Input and output3/4 disclosed
Model typeWorld model
Source and note: Model typeA github.com/dexmal/opendw · Retrieved 10 November 2026Note. GitHub README: “DW05 is a multimodal world model for embodied decision-making, designed to understand how actions shape future outcomes in robot environments.” The Hugging Face tags also list world-action-model.
InputsCamera Language Robot state
Source and note: InputsA github.com/dexmal/opendw · Retrieved 10 November 2026Note. GitHub README: “DW05 uses language, image/video, robot type, state, and action inputs for embodied world modeling.”
What it controlsArms and hands
Source and note: What it controlsB dexmal.com/blog/dw0.5?lang=en-US · Retrieved 10 November 2026Note. GitHub README: “It unifies future video prediction, action generation, and state-value estimation in one framework, with released weights, inference code, and training code.” The blog evaluates the action policy on two arms: “RoboTwin2.0 directly evaluates action-policy capability in a dual-arm simulation environment.”
Degrees of freedom controlledNot stated
Source and note: Degrees of freedom controlledC huggingface.co/Dexmal/DW05-Base · Retrieved 10 November 2026Note. Hugging Face model card gives the size of the action vector, not a DoF count for a named robot: “a 32-dimensional action and proprioception interface”.
Size and speed0/2 disclosed
ParametersNot stated
Control rateNot stated
Where it runs and what it is built on1/2 disclosed
On robot or cloudNot stated
Base modelWan2.2
Source and note: Base modelC huggingface.co/Dexmal/DW05-Base · Retrieved 10 November 2026Note. Hugging Face model card: “This release is trained from and used with open third-party components, including Wan2.2 and uMT5-compatible tokenizer/text components.” GitHub README: “It follows an MoT framework where a Wan backbone is followed by three expert heads for video, action, and value modeling.”
Openness3/3 disclosed
AccessOpen weights (download)
Source and note: AccessA github.com/dexmal/opendw · Retrieved 10 November 2026Note. GitHub README, model preparation: “huggingface-cli download Dexmal/DW05-Base --local-dir ./checkpoints/DW05-Base”. The Hugging Face repository is listed as not gated.
Licence documentApache License 2.0
Source and note: Licence documentC huggingface.co/Dexmal/DW05-Base · Retrieved 10 November 2026Note. Hugging Face model card: “This DW05-Base release is distributed under the Apache License 2.0.” Tag: “license:apache-2.0”.
Licence typeFree, commercial use
Source and note: Licence typeA github.com/dexmal/opendw · Retrieved 10 November 2026Note. GitHub README: “It unifies future video prediction, action generation, and state-value estimation in one framework, with released weights, inference code, and training code.” Hugging Face model card: “This DW05-Base release is distributed under the Apache License 2.0.”
The developer’s own claims2/2 disclosed
Learns new tasksNeeds retraining
Source and note: Learns new tasksC huggingface.co/Dexmal/DW05-Base · Retrieved 10 November 2026Note. Developer claim, Hugging Face model card: “The base checkpoint is intended as a general DW05 model release and as a starting point for method development, fine-tuning, and downstream policy/runtime integration.”
Works across robotsYes
Source and note: Works across robotsB dexmal.com/blog/dw0.5?lang=en-US · Retrieved 10 November 2026Note. Developer claim, blog: “The current results show that DW0.5 already generalizes across tasks, robots, and scenes at a basic level.” The blog demo is headed “Across Embodiments Aloha DOS-W1 AgiBot G1”.Yes only if the developer itself says the model runs on different robot models, for example robots from two manufacturers or two of one manufacturer’s models. Several units of the same robot do not count.
Notes
Dexmal writes the model name as DW0.5 on its blog and as DW05 in its repository and on Hugging Face.
Dexmal released two checkpoints: DW05-Base and DW05-Robotwin, a RoboTwin 2.0 fine-tune; the Value Expert is announced for a later release.
Dexmal lists its Beijing address on its own website.
Sources
One line per source, not per figure: a source has one retrieval date.
- Agithub.com/dexmal/opendwRetrieved 10 November 2026
- Bdexmal.com/blog/dw0.5?lang=en-USMain source. Retrieved 10 November 2026
- Chuggingface.co/Dexmal/DW05-BaseRetrieved 10 November 2026