Tutor Intelligence · robot AI model
TI-0.1
United States · 2026
Sources retrieved: 10 November 2026 (A, B)
- What it controls
- Arms and handsSource and note: What it controlsB research.tutorintelligence.com/ti0-1 · Retrieved 10 November 2026Note. Technical report: TI-0.1 uses action-chunking diffusion to predict “a chunk of arm and gripper actions”.
- Inputs
- Camera Robot stateSource and note: InputsA tutorintelligence.com/blog/ti0-1 · Retrieved 10 November 2026Note. Blog post: TI-0.1 is “a model that acts from camera images and the robot’s own joint readings”. Technical report: it predicts actions “from recent camera images and robot state”.
Specifications
5 of 14 stated 9 not stated
4 fields hidden 5 not-stated fields with a note stay ·
How to read the figuresShow guideClose
- not statedNo source
- 0Reported as zero
- ASource
Select a source marker for source details and notes.
Release1/1 disclosed
Released9 November 2026
Source and note: ReleasedB research.tutorintelligence.com/ti0-1 · Retrieved 10 November 2026Note. [A] The technical report is marked published “November 9, 2026”.
Input and output2/4 disclosed
Model typeNot stated
Source and note: Model typeB research.tutorintelligence.com/ti0-1 · Retrieved 10 November 2026Note. Technical report: TI-0.1 is “a visuomotor action-chunking diffusion policy that runs on Sonny”.
InputsCamera Robot state
Source and note: InputsA tutorintelligence.com/blog/ti0-1 · Retrieved 10 November 2026Note. Blog post: TI-0.1 is “a model that acts from camera images and the robot’s own joint readings”. Technical report: it predicts actions “from recent camera images and robot state”.
What it controlsArms and hands
Source and note: What it controlsB research.tutorintelligence.com/ti0-1 · Retrieved 10 November 2026Note. Technical report: TI-0.1 uses action-chunking diffusion to predict “a chunk of arm and gripper actions”.
Degrees of freedom controlledNot stated
Source and note: Degrees of freedom controlledB research.tutorintelligence.com/ti0-1 · Retrieved 10 November 2026Note. The technical report lists Sonny's arms as “2 × 6-DoF, 5 kg”; the policy predicts “a chunk of arm and gripper actions”.
Size and speed0/2 disclosed
ParametersNot stated
Control rateNot stated
Source and note: Control rateB research.tutorintelligence.com/ti0-1 · Retrieved 10 November 2026Note. Technical report: “The visuomotor policy predicts an action chunk and executes part of it before replanning”.
Where it runs and what it is built on1/2 disclosed
On robot or cloudOn the robot
Source and note: On robot or cloudB research.tutorintelligence.com/ti0-1 · Retrieved 10 November 2026Note. Technical report: “The inference loop stays on the robot”.
Base modelNot stated
Source and note: Base modelA tutorintelligence.com/blog/ti0-1 · Retrieved 10 November 2026Note. Blog post: “we distill the RL policy into TI-0.1”, a policy trained with reinforcement learning in simulation.
Openness0/3 disclosed
AccessNot stated
Licence documentNot stated
Licence typeNot stated
The developer’s own claims1/2 disclosed
Learns new tasksNeeds retraining
Source and note: Learns new tasksB research.tutorintelligence.com/ti0-1 · Retrieved 10 November 2026Note. Developer claim, technical report: “We train a privileged-state policy for each task”. Blog post: “Starting from just a few Tutor demonstrations, TI-0.1 learns its task entirely in simulation and runs autonomously on Sonny at human speed.”
Works across robotsNot stated
Source and note: Works across robotsB research.tutorintelligence.com/ti0-1 · Retrieved 10 November 2026Note. Technical report: TI-0.1 is “a visuomotor policy deployed on the bimanual Sonny manipulator”.Yes only if the developer itself says the model runs on different robot models, for example robots from two manufacturers or two of one manufacturer’s models. Several units of the same robot do not count.
Notes
Tutor Intelligence presents TI-0.1 as the first model in its TI series trained with TRACE, an agentic harness in which LLM agents rebuild a robot's task in simulation and train policies there.
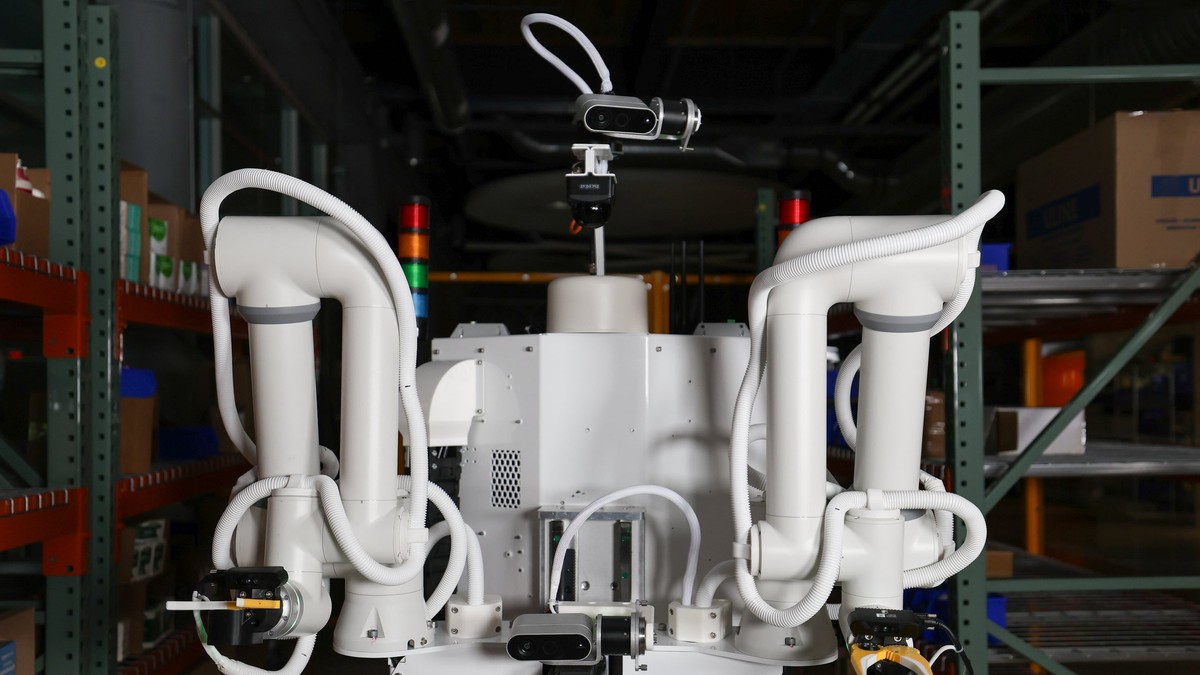
TI-0.1 is shown running on Sonny, Tutor Intelligence's bimanual robot.
Tutor Intelligence states that it is headquartered in Watertown, Massachusetts.
Sources
One line per source, not per figure: a source has one retrieval date.
- Atutorintelligence.com/blog/ti0-1Retrieved 10 November 2026
- Bresearch.tutorintelligence.com/ti0-1Main source. Retrieved 10 November 2026