Tianjin University · robot AI model
Embodied-R1.5
China · 2026
Sources retrieved: 13 November 2026 (A, B, C)
- Model type
- Embodied reasoningSource and note: Model typeB arxiv.org/abs/2606.11324 · Retrieved 13 November 2026Note. Developer wording: Embodied-R1.5 is “a unified Embodied Foundation Model (EFM) that integrates comprehensive embodied reasoning capabilities, spanning embodied cognition, task planning, correction, and pointing”.
- Inputs
- Camera LanguageSource and note: InputsA huggingface.co/IffYuan/Embodied-R1.5 · Retrieved 13 November 2026Note. Model card: “The model reasons over the visual observation”.
- Access
- Open weights (download)Source and note: AccessB arxiv.org/abs/2606.11324 · Retrieved 13 November 2026Note. Paper: “We open-source model weights, datasets, training code, and EmbodiedEvalKit”.
- Parameters
- 8BSource and note: ParametersC embodied-r.github.io · Retrieved 13 November 2026Note. Project page: the model integrates its capabilities “within a single 8B-parameter architecture”.
- Base model
- Qwen3-VL-8B-InstructSource and note: Base modelA huggingface.co/IffYuan/Embodied-R1.5 · Retrieved 13 November 2026Note. Model card metadata lists the base model as “Qwen/Qwen3-VL-8B-Instruct”.
- Licence type
- Free, commercial useSource and note: Licence typeA huggingface.co/IffYuan/Embodied-R1.5 · Retrieved 13 November 2026Note. Developer wording: “We open-source model weights, datasets, training code, and EmbodiedEvalKit”; model card: “Released under the Apache 2.0 license.”
Specifications
8 of 14 stated 6 not stated
3 fields hidden 3 not-stated fields with a note stay ·
How to read the figuresShow guideClose
- not statedNo source
- 0Reported as zero
- ASource
Select a source marker for source details and notes.
Release1/1 disclosed
Released9 June 2026
Source and note: ReleasedB arxiv.org/abs/2606.11324 · Retrieved 13 November 2026Note. arXiv listing: “Submitted on 9 Jun 2026”.
Input and output2/4 disclosed
Model typeEmbodied reasoning
Source and note: Model typeB arxiv.org/abs/2606.11324 · Retrieved 13 November 2026Note. Developer wording: Embodied-R1.5 is “a unified Embodied Foundation Model (EFM) that integrates comprehensive embodied reasoning capabilities, spanning embodied cognition, task planning, correction, and pointing”.
InputsCamera Language
Source and note: InputsA huggingface.co/IffYuan/Embodied-R1.5 · Retrieved 13 November 2026Note. Model card: “The model reasons over the visual observation”.
What it controlsNot stated
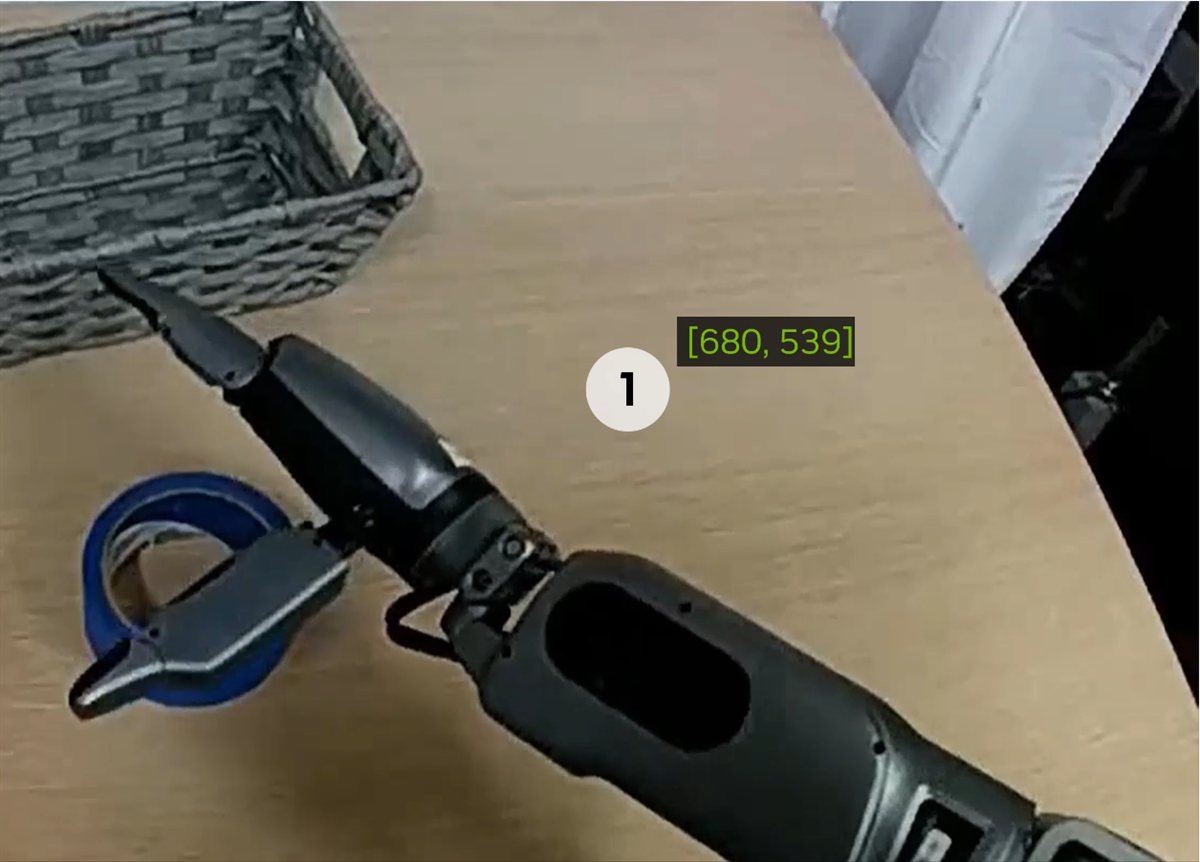
Source and note: What it controlsA huggingface.co/IffYuan/Embodied-R1.5 · Retrieved 13 November 2026Note. The model answers in text, points, boxes and trajectories, not with robot motion. Model card: the model is built to “ground high-level reasoning in coordinates and trajectories”.
Degrees of freedom controlledNot stated
Size and speed1/2 disclosed
Parameters8B
Source and note: ParametersC embodied-r.github.io · Retrieved 13 November 2026Note. Project page: the model integrates its capabilities “within a single 8B-parameter architecture”.
Control rateNot stated
Where it runs and what it is built on1/2 disclosed
On robot or cloudNot stated
Base modelQwen3-VL-8B-Instruct
Source and note: Base modelA huggingface.co/IffYuan/Embodied-R1.5 · Retrieved 13 November 2026Note. Model card metadata lists the base model as “Qwen/Qwen3-VL-8B-Instruct”.
Openness3/3 disclosed
AccessOpen weights (download)
Source and note: AccessB arxiv.org/abs/2606.11324 · Retrieved 13 November 2026Note. Paper: “We open-source model weights, datasets, training code, and EmbodiedEvalKit”.
Licence documentApache-2.0
Source and note: Licence documentA huggingface.co/IffYuan/Embodied-R1.5 · Retrieved 13 November 2026Note. Model card: “Released under the Apache 2.0 license.”
Licence typeFree, commercial use
Source and note: Licence typeA huggingface.co/IffYuan/Embodied-R1.5 · Retrieved 13 November 2026Note. Developer wording: “We open-source model weights, datasets, training code, and EmbodiedEvalKit”; model card: “Released under the Apache 2.0 license.”
The developer’s own claims0/2 disclosed
Learns new tasksNot stated
Source and note: Learns new tasksB arxiv.org/abs/2606.11324 · Retrieved 13 November 2026Note. The paper states that “Embodied-R1.5 can be fine-tuned into a VLA with only a small amount of data”, and it also reports “extensive zero-shot real-robot experiments”.
Works across robotsNot stated
Source and note: Works across robotsYes only if the developer itself says the model runs on different robot models, for example robots from two manufacturers or two of one manufacturer’s models. Several units of the same robot do not count.
Notes
The project page lists the affiliations “Tianjin University” and “Tencent Hunyuan”.
Sources
One line per source, not per figure: a source has one retrieval date.
- Ahuggingface.co/IffYuan/Embodied-R1.5Retrieved 13 November 2026
- Barxiv.org/abs/2606.11324Retrieved 13 November 2026
- Cembodied-r.github.ioMain source. Retrieved 13 November 2026