Key figures as stated by the manufacturer
0 of 6 stated · 6 gapsDemonstratorThe manufacturer states none of the 6 key figures.
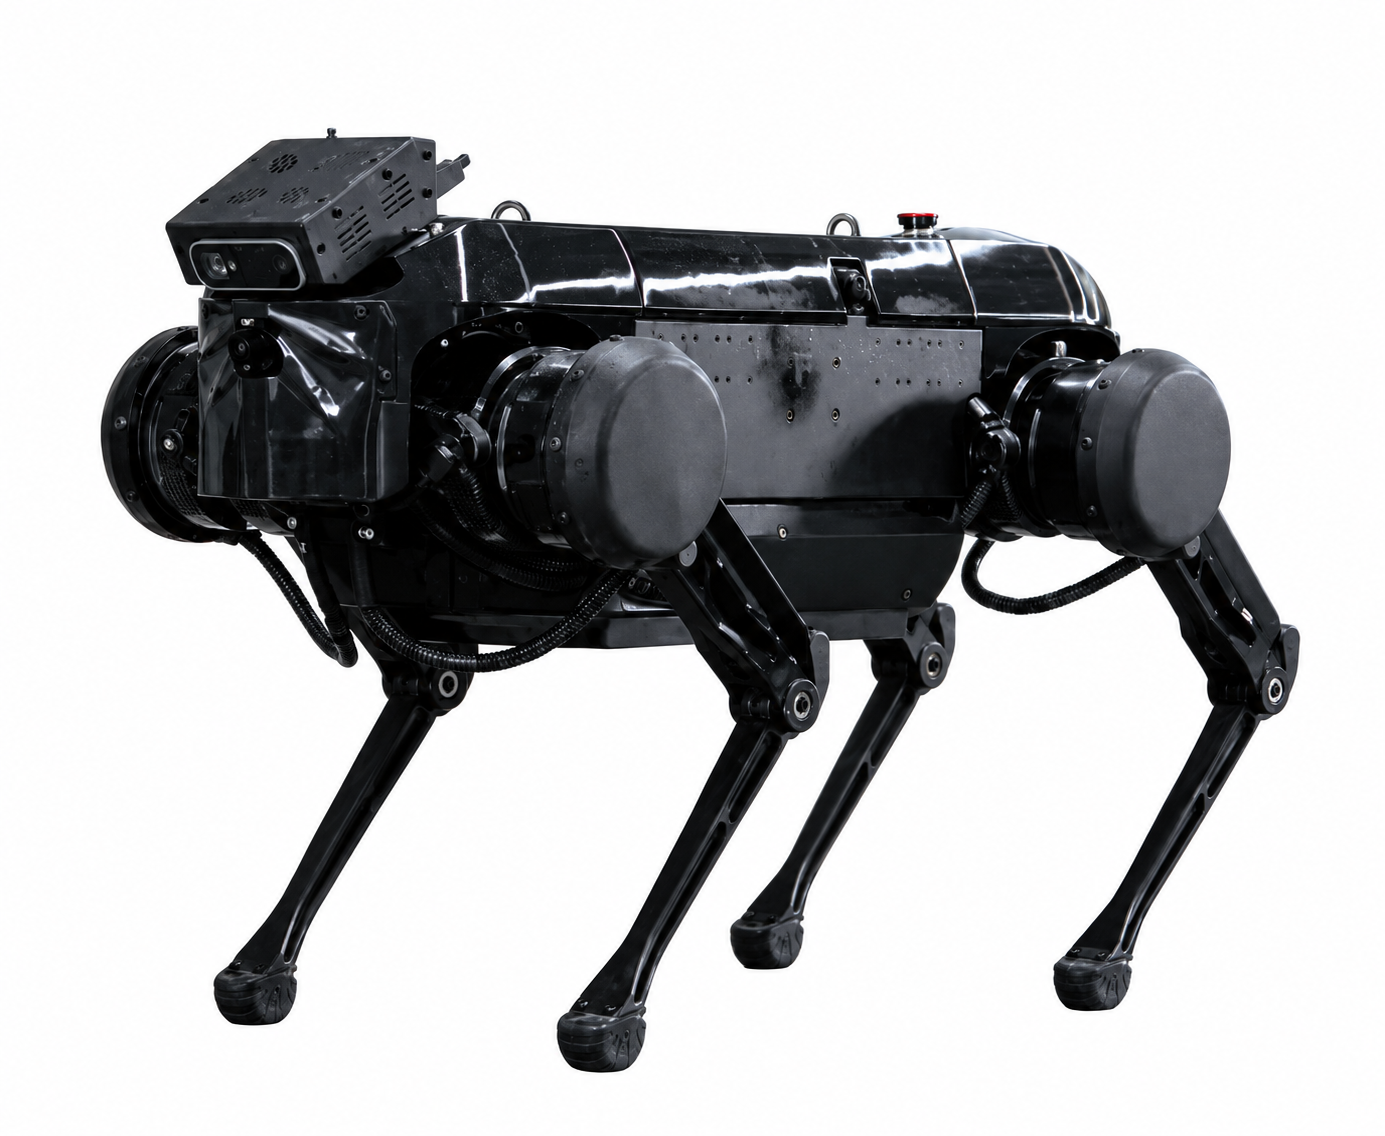
Manufacturer's own photo.
Intended use, per the manufacturer
The manufacturer’s words
First quadruped robot in China demonstrated completing the plum-blossom-pile (quincuncial pile) walking challenge, showcasing perception, footstep-planning and torque-control research.
Source: equalocean.com · Retrieved
This category is not our assessment.
Every field in the schema
3 of 33 fields statedImperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | not stated | |
| Length | not stated | |
| Width | not stated | |
| Height | not stated | |
| Degrees of freedom | not stated | |
| Payload, walking | not stated | |
| Payload, standing | not stated | |
| Max speed | not stated | |
| Max slope | not stated | |
| Single obstacle | 60cm23.6inOur conversion from 60 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A Note60 cm step climbed at a 20° incline, as a precursor test before the plum-blossom-pile challenge — a compound test condition, not a plain vertical-obstacle figure. |
| Stair step, continuous | not stated | |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | |
| Runtime | not stated | |
| Hot-swap battery | not stated | |
| Charge time | not stated | |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | not stated | |
| Cameras | RGB-D camera used for real-time environment perception together with eye-foot calibration. | B CaveatNo model/part number disclosed, only sensor type. |
| Onboard compute | not stated | |
| ROS 2 | not stated | |
| SDK languages | not stated | |
| Autonomy level | Perception and foot-placement positioning error within 1 cm, 10 ms environment-based route planning, 1 kHz real-time dynamics-based torque control. | B CaveatFigures reported in tech-press coverage of the Jamoca plum-blossom-pile demonstration, not a manufacturer datasheet. |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | |
| Data ports | not stated | |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Stair step and payload each exist in two variants. Only compare fields with the same label.
Notes
- Announced 20 November 2020 by Tencent Robotics X Lab; the first quadruped in China to walk across quincuncial ('plum blossom') piles after climbing a 60 cm step.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for Jamocahttps://equalocean.com/briefing/20201120230004679
Sources
- A Secondary: syncedreview.com/2020/11/25/tencent-robot-xs-jamoca-takes-on-kung-fu-master-challenge-to-walk-on-quincunical-piles/ · Retrieved
- B Secondary: hyper.ai/en/news/13833 · Retrieved
- C Manufacturer product page. equalocean.com/briefing/20201120230004679 · Retrieved
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.