Key figures as stated by the manufacturer
0 of 6 stated · 6 gapsThe manufacturer states none of the 6 key figures.
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Robots with several sources carry several letters.
- Payload, moving
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
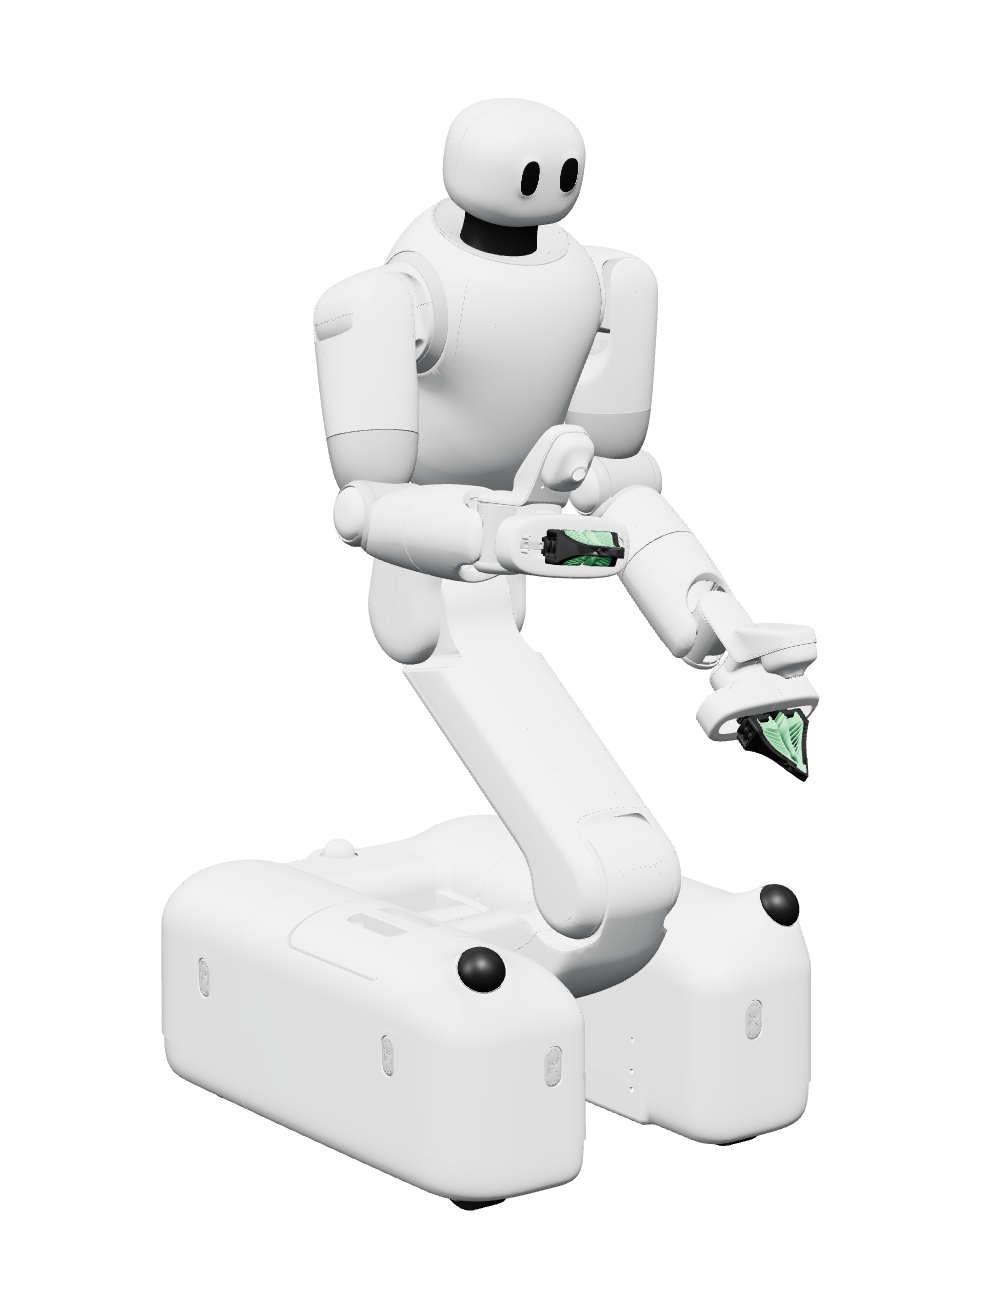
Manufacturer's own photo.
Intended use, per the manufacturer
Source: dyna.co · Retrieved
This category is not our assessment.
Full specifications
0 of 32 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | not stated | |
| Length | not stated | |
| Width | not stated | |
| Height | not stated | |
| Degrees of freedom | not stated | Caveat The producer's diagram gives Taku a 21-degree-of-freedom upper body plus a mobile base, with two 7-degree-of-freedom arms; it gives no total that includes the base. A |
| Payload, moving | not stated | |
| Payload, standing | not stated | |
| Max speed | not stated | |
| Max slope | not stated | |
| Single obstacle | not stated | |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | |
| Runtime | not stated | |
| Hot-swap battery | not stated | |
| Charge time | not stated | |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | not stated | |
| Cameras | not stated | Note The producer lists Taku's sensing as vision, tactile and proprioception. B |
| Onboard compute | not stated | |
| ROS 2 | not stated | |
| SDK languages | not stated | |
| Autonomy level | not stated | |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | |
| Data ports | not stated | |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- The producer introduced Dyna-2.1, a full-stack physical agent, together with Taku, the semi-humanoid robot at its centre, in a research post.
- The research post that introduces Taku is dated September 29, 2026.
- The producer describes Taku as a semi-humanoid robot with a human-shaped body above the waist, a folding lower body, a base on four steerable wheels and two 7-degree-of-freedom arms.
- The producer says most steps in its target workflows need reach and manipulation precision rather than legs, so Taku moves between stations on wheels, and that it sized Taku like an average person.
- The producer says Taku's arms use low-ratio planetary actuators, which allow higher speeds and accelerations than the harmonic drives in conventional arms.
- The research post uses a hotel laundry room workflow as its running example; the producer calls commercial laundry one of the deployment verticals it has been focusing on.
- The producer says it is based in Redwood City, California.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for Takuhttps://www.dyna.co/dyna-2.1
Sources
-
A
Manufacturer product page. www.
dyna. · Retrievedco/ dyna-2. 1 -
B
www.
dyna. · Retrievedco/
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.