Key figures as stated by the manufacturer
2 of 6 stated · 4 gaps- Weight not stated
- Payload, moving not stated
- Runtime A 180minWarning: load condition not stated
- Max speed A 10.8km/h6.71mphOur conversion from 10.8 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- AI model not stated
- Indicative price not stated
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Robots with several sources carry several letters.
- Payload, moving
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (4)
Payload, moving
Caveat The core parameters give 7 kg per arm; the two single-arm modules carry 3 kg and 7 kg. That is an arm figure, not a figure for what the whole robot can carry.
Runtime
Caveat Whole-robot runtime in the core parameters table; no load is given.
Max speed
Note Forward speed in the core parameters table.
Indicative price
Caveat The page gives a starting price of 9,800 yuan for the modular platform without saying which configuration it covers.
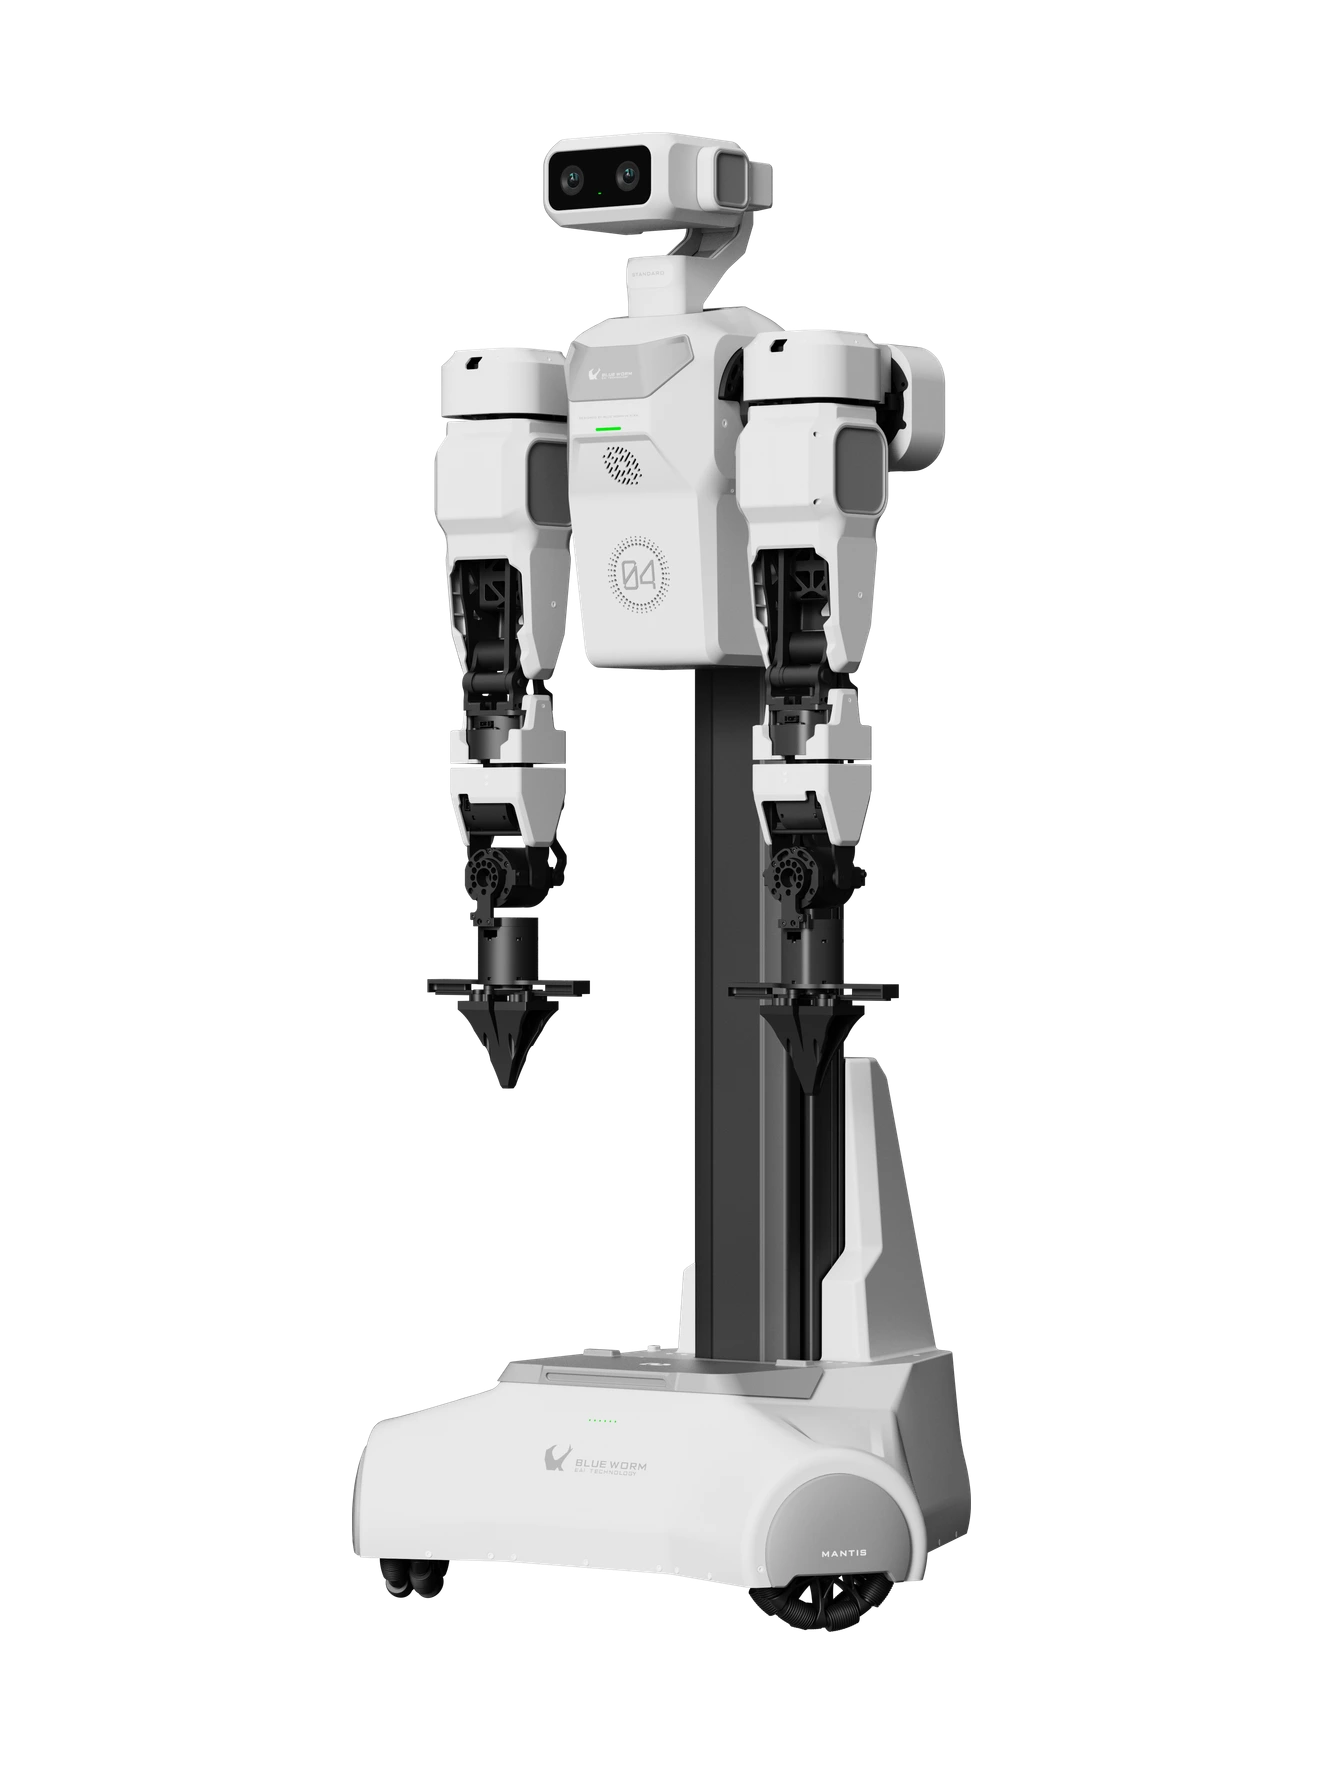
Manufacturer's own photo.
Intended use, per the manufacturer
Source: bluewormrobotics.com · Retrieved
This category is not our assessment.
Full specifications
6 of 32 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | not stated | |
| Length | 63.3cm24.9inOur conversion from 63.3 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Overall size in the core parameters table, given as length 633 mm, width 552 mm and height 1400 mm. A |
| Width | 55.2cm21.7inOur conversion from 55.2 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Overall size in the core parameters table, given as length 633 mm, width 552 mm and height 1400 mm. A |
| Height | 140cm55.1inOur conversion from 140 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Overall size in the core parameters table; the lift range is 550 mm. A |
| Degrees of freedom | 22DoF | Note Whole-body figure in the core parameters table. A |
| Payload, moving | not stated | Caveat The core parameters give 7 kg per arm; the two single-arm modules carry 3 kg and 7 kg. That is an arm figure, not a figure for what the whole robot can carry. A |
| Payload, standing | not stated | Caveat The core parameters give 7 kg per arm; the two single-arm modules carry 3 kg and 7 kg. That is an arm figure, not a figure for what the whole robot can carry. A |
| Max speed | 10.8km/h6.71mphOur conversion from 10.8 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Forward speed in the core parameters table. A |
| Max slope | not stated | |
| Single obstacle | not stated | |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | |
| Runtime | 180minWarning: load condition not stated | Caveat Whole-robot runtime in the core parameters table; no load is given. A |
| Hot-swap battery | not stated | |
| Charge time | not stated | |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | not stated | |
| Cameras | not stated | |
| Onboard compute | not stated | |
| ROS 2 | not stated | Caveat ROS 2, MoveIt 2 and an SDK are listed as supported on the 7 kg arm module but not on the 3 kg module, and the page says the scope of development support depends on the configuration. A |
| SDK languages | not stated | |
| Autonomy level | not stated | |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | |
| Data ports | not stated | |
| Commercial | ||
| Indicative price | not stated | Caveat The page gives a starting price of 9,800 yuan for the modular platform without saying which configuration it covers. |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- Blue Worm says Mantis Standard is a wheeled humanoid because the product is aimed at upper-body work.
- A wheeled chassis moves the robot, two arms do the work, and a lift extends the working range vertically.
- The robot is built from modules joined by quick-release interfaces and can be combined as a single arm, a chassis, a dual-arm unit or the complete robot.
- The page gives a lift range of 550 mm.
- The chassis moves omnidirectionally with 3 degrees of freedom.
- The design of the camera head was inspired by a handheld gimbal camera.
- The page names two groups of uses: research, development and data collection; and commercial, service and light-industry work.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for Mantis Standardhttps://www.bluewormrobotics.com/products/mantis-standard
Sources
-
A
Manufacturer product page. www.
bluewormrobotics. · Retrievedcom/ products/ mantis-standard
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.