Alibaba DAMO Academy · robot AI model
RynnVLA-Latent
China · 2026
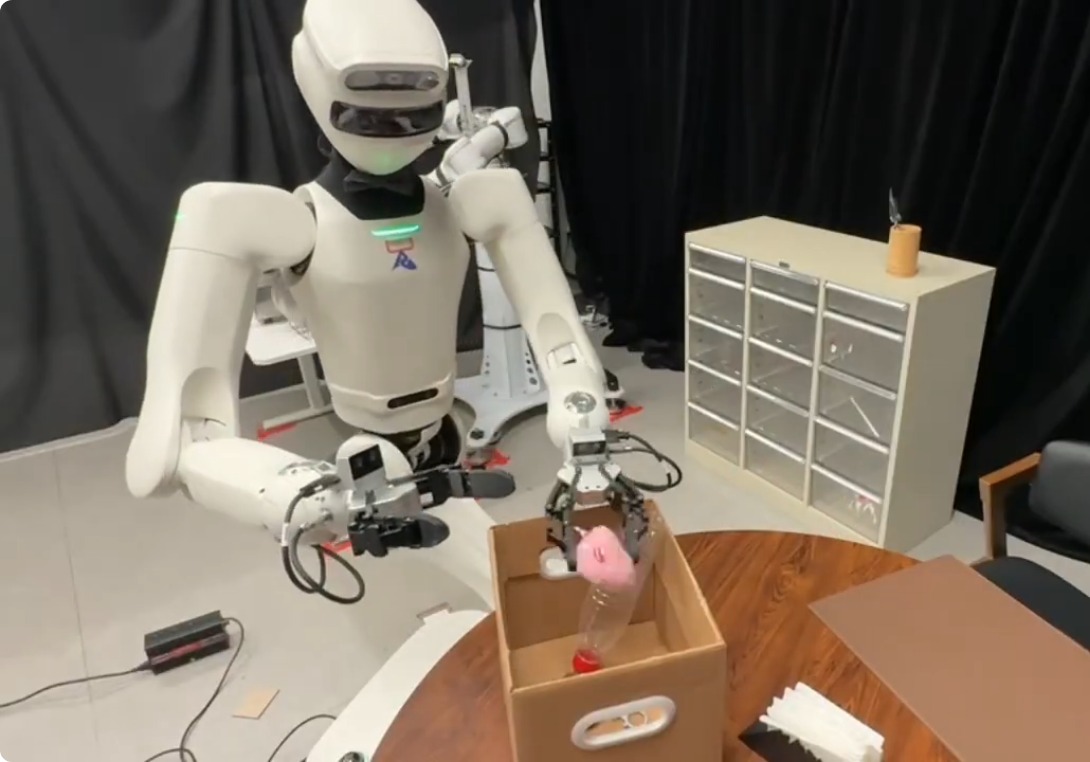
Runs on S1 by AstribotSource and note: S1B arxiv.org/html/2610.34356 · Retrieved 30 October 2026
Sources retrieved: 30 October 2026 (A, B, C, D)
- Model type
- Vision-language-action (VLA)Source and note: Model typeA huggingface.co/Alibaba-DAMO-Academy/RynnVLA-Latent-4B · Retrieved 30 October 2026Note. Alibaba's own term: “a Mixture-of-Transformers vision-language-action model”.
- What it controls
- Arms and handsSource and note: What it controlsB arxiv.org/html/2610.34356 · Retrieved 30 October 2026Note. Technical report, after robot post-training: “The policy predicts native action chunks, which are passed to the robot control interface for execution.” The real-robot platforms are dual-arm: “Two dual-arm embodiments used for real-world evaluation”. The report does not say whether the mobile base is driven by the policy.
- Inputs
- Camera Language Robot stateSource and note: InputsA huggingface.co/Alibaba-DAMO-Academy/RynnVLA-Latent-4B · Retrieved 30 October 2026Note. Model card: “Given a language instruction and up to six camera views”. Robot state is added in robot post-training: “Proprioceptive state is introduced only at this stage.”
- Access
- Open weights (download)Source and note: AccessC github.com/alibaba-damo-academy/RynnVLA-Latent · Retrieved 30 October 2026Note. Repository README: “The trained checkpoints are published separately from this code repository, on both Hugging Face and ModelScope.” Only Stage-1 checkpoints are published: “They are not closed-loop control policies”.
- Parameters
- 5.04B Varies by versionSource and note: ParametersA huggingface.co/Alibaba-DAMO-Academy/RynnVLA-Latent-4B · Retrieved 30 October 2026Note. RynnVLA-Latent-4B, model card: “Parameters: 5,042,270,129 (5.042 B)”. RynnVLA-Latent-2B: “Parameters: 2,510,917,041 (2.511 B)”. Technical report, layers of the 4B size: “RynnVLA-Latent-4B 36 2560 4.44 B 768 0.60 B 5.04 B” (language model 4.44 B, action expert 0.60 B, total 5.04 B).
- Base model
- RynnBrainSource and note: Base modelC github.com/alibaba-damo-academy/RynnVLA-Latent · Retrieved 30 October 2026Note. Repository README, Stage-1 training: “initialize from a RynnBrain backbone”. Project page: “RynnBrain VLM + narrow action expert”.
- Licence type
- Free, commercial useSource and note: Licence typeA huggingface.co/Alibaba-DAMO-Academy/RynnVLA-Latent-4B · Retrieved 30 October 2026Note. Weights: “Apache License 2.0.” Code repository: “Apache License 2.0”.
Specifications
11/14 specifications disclosed 3 not stated
1 field hidden 2 not-stated fields with a note stay ·
How to read the figuresShow guideClose
Not statedThe developer publishes nothing on itYesThe developer says it doesVersionsDiffers between versions
Select a source marker for source details and notes.
Release1/1 disclosed
Input and output3/4 disclosed
Size and speed1/2 disclosed
Versions
- RynnVLA-Latent-2B
- 2,510,917,041
- RynnVLA-Latent-4B
- 5,042,270,129
Where it runs and what it is built on1/2 disclosed
Openness3/3 disclosed
The developer’s own claims2/2 disclosed
Versions
- RynnVLA-Latent-2B
- RynnVLA-Latent-4B
The developer has released this model in several versions. Each figure applies to the version its source names.
Notes
Alibaba DAMO Academy publishes RynnVLA-Latent in two sizes, 2B and 4B, as Stage-1 pretraining checkpoints.
The released checkpoints are not ready-made robot controllers: a robot needs its own Stage-2 post-training first.
RynnLAM, the model that labels the pretraining videos with latent actions, is published as a separate checkpoint.
Sources
One line per source, not per figure: a source has one retrieval date.
- Ahuggingface.co/Alibaba-DAMO-Academy/RynnVLA-Latent-4BRetrieved 30 October 2026
- Barxiv.org/html/2610.34356Retrieved 30 October 2026
- Cgithub.com/alibaba-damo-academy/RynnVLA-LatentRetrieved 30 October 2026
- Darxiv.org/abs/2610.34356Retrieved 30 October 2026