Alibaba DAMO Academy · robot AI model
RynnUnify
China · 2026
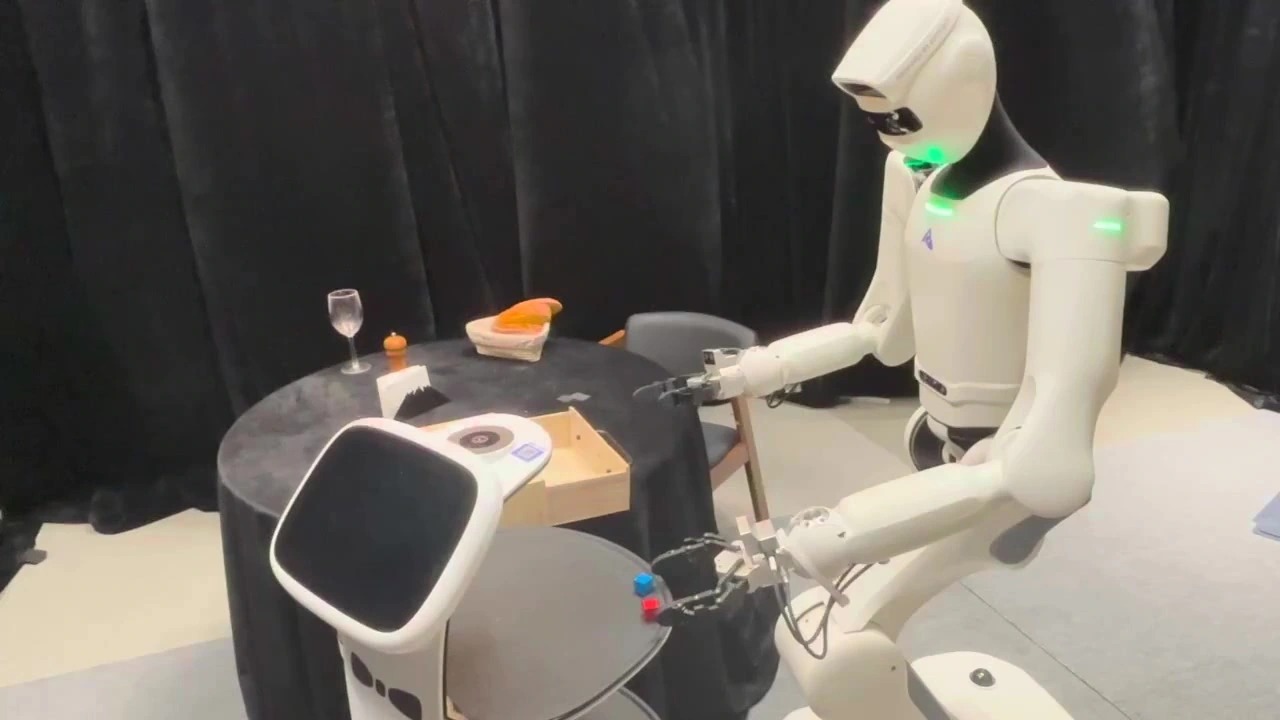
Runs on S1 by AstribotSource and note: S1A arxiv.org/pdf/2610.32965 · Retrieved 30 October 2026
Sources retrieved: 30 October 2026 (A, B, C, D, E)
- Model type
- Embodied reasoning World action modelSource and note: Model typeC github.com/alibaba-damo-academy/RynnUnify · Retrieved 30 October 2026Note. README: “Agentic interleaved thinking enhances embodied reasoning by using world modeling to imagine future scene dynamics”. Paper: “We extend RynnUnify to a world-action model (WAM) for robot control.”
- Inputs
- Camera LanguageSource and note: InputsA arxiv.org/pdf/2610.32965 · Retrieved 30 October 2026Note. Stated for the world-action extension: “The reasoner uses the task instruction, current observations, and visual memory to produce a subtask latent.” The robot training data: “The data include task instructions, three synchronized RGB views, robot actions”.
- Access
- Open weights (download)Source and note: AccessB huggingface.co/Alibaba-DAMO-Academy/RynnUnify-Base · Retrieved 30 October 2026Note. The Hugging Face repository RynnUnify-Base is public and not gated.
- Parameters
- 16BSource and note: ParametersB huggingface.co/Alibaba-DAMO-Academy/RynnUnify-Base · Retrieved 30 October 2026Note. Model card: “Model size 16B params”. README: “RynnUnify adopts a 16B unified embodied model comprising an 8B autoregressive reasoner and an 8B video generator.”
- Base model
- Cosmos3 NanoSource and note: Base modelD huggingface.co/Alibaba-DAMO-Academy/RynnUnify-Base/raw/main/README.md · Retrieved 30 October 2026Note. Model card header: “base_model: nvidia/Cosmos3-Nano”.
- Licence type
- Free, commercial useSource and note: Licence typeD huggingface.co/Alibaba-DAMO-Academy/RynnUnify-Base/raw/main/README.md · Retrieved 30 October 2026Note. Model card header of RynnUnify-Base: “license: apache-2.0”. The world-action checkpoint has its own licence: “license: other”.
Specifications
9/14 specifications disclosed 5 not stated
2 fields hidden 3 not-stated fields with a note stay ·
How to read the figuresShow guideClose
Not statedThe developer publishes nothing on it
Select a source marker for source details and notes.
Release1/1 disclosed
Released23 October 2026
Source and note: ReleasedE arxiv.org/abs/2610.32965 · Retrieved 30 October 2026Note. [A] “Submitted on 23 Oct 2026”
Input and output2/4 disclosed
Model typeEmbodied reasoning World action model
Source and note: Model typeC github.com/alibaba-damo-academy/RynnUnify · Retrieved 30 October 2026Note. README: “Agentic interleaved thinking enhances embodied reasoning by using world modeling to imagine future scene dynamics”. Paper: “We extend RynnUnify to a world-action model (WAM) for robot control.”
InputsCamera Language
Source and note: InputsA arxiv.org/pdf/2610.32965 · Retrieved 30 October 2026Note. Stated for the world-action extension: “The reasoner uses the task instruction, current observations, and visual memory to produce a subtask latent.” The robot training data: “The data include task instructions, three synchronized RGB views, robot actions”.
What it controlsNot stated
Source and note: What it controlsA arxiv.org/pdf/2610.32965 · Retrieved 30 October 2026Note. Stated for the extension only: “An action head reads the generator’s video features to predict action chunks.” The paper does not tie them to arms, hands or whole body.
Degrees of freedom controlledNot stated
Size and speed1/2 disclosed
Parameters16B
Source and note: ParametersB huggingface.co/Alibaba-DAMO-Academy/RynnUnify-Base · Retrieved 30 October 2026Note. Model card: “Model size 16B params”. README: “RynnUnify adopts a 16B unified embodied model comprising an 8B autoregressive reasoner and an 8B video generator.”
Control rateNot stated
Source and note: Control rateA arxiv.org/pdf/2610.32965 · Retrieved 30 October 2026Note. The paper gives a training-data rate, not a control rate: “each sample contains the current multi-view frame, 48 future frames, and 48 aligned actions at 20 Hz”.
Where it runs and what it is built on1/2 disclosed
On robot or cloudNot stated
Base modelCosmos3 Nano
Source and note: Base modelD huggingface.co/Alibaba-DAMO-Academy/RynnUnify-Base/raw/main/README.md · Retrieved 30 October 2026Note. Model card header: “base_model: nvidia/Cosmos3-Nano”.
Openness3/3 disclosed
AccessOpen weights (download)
Source and note: AccessB huggingface.co/Alibaba-DAMO-Academy/RynnUnify-Base · Retrieved 30 October 2026Note. The Hugging Face repository RynnUnify-Base is public and not gated.
Licence documentApache-2.0
Source and note: Licence documentD huggingface.co/Alibaba-DAMO-Academy/RynnUnify-Base/raw/main/README.md · Retrieved 30 October 2026Note. Model card header of RynnUnify-Base: “license: apache-2.0”. The separate world-action checkpoint RynnUnify-WAM-RoboCasa carries “license: other”.
Licence typeFree, commercial use
Source and note: Licence typeD huggingface.co/Alibaba-DAMO-Academy/RynnUnify-Base/raw/main/README.md · Retrieved 30 October 2026Note. Model card header of RynnUnify-Base: “license: apache-2.0”. The world-action checkpoint has its own licence: “license: other”.
The developer’s own claims1/2 disclosed
Learns new tasksNeeds retraining
Source and note: Learns new tasksA arxiv.org/pdf/2610.32965 · Retrieved 30 October 2026Note. Developer's training recipe for robots: “Robot adaptation uses approximately 1,600 hours of atomic-task trajectories and 177 hours of composite-task trajectories from RoboCasa365”.
Works across robotsNot stated
Source and note: Works across robotsA arxiv.org/pdf/2610.32965 · Retrieved 30 October 2026Note. The paper tests one real robot and one simulator: “We conduct real-world experiments on an Astribot S1 dual-arm mobile robot in indoor tabletop environments”.Yes only if the developer itself says the model runs on different robot models, for example robots from two manufacturers or two of one manufacturer’s models. Several units of the same robot do not count.
Notes
Alibaba DAMO Academy publishes RynnUnify as a 16B model made of an 8B reasoner and an 8B video generator.
Alibaba DAMO Academy published the RynnUnify paper on arXiv on 23 October 2026.
Sources
One line per source, not per figure: a source has one retrieval date.
- Aarxiv.org/pdf/2610.32965Retrieved 30 October 2026
- Bhuggingface.co/Alibaba-DAMO-Academy/RynnUnify-BaseRetrieved 30 October 2026
- Cgithub.com/alibaba-damo-academy/RynnUnifyRetrieved 30 October 2026
- Dhuggingface.co/Alibaba-DAMO-Academy/RynnUnify-Base/raw/main/README.mdRetrieved 30 October 2026
- Earxiv.org/abs/2610.32965Retrieved 30 October 2026