Shanghai AI Laboratory · robot AI model
InternW0-Δ
China · 2026
Sources retrieved: 2 November 2026 (A, B, C, D, E)
- Model type
- World action modelSource and note: Model typeC github.com/InternRobotics/InternW0-Delta · Retrieved 2 November 2026Note. GitHub README: “InternW0-delta (InternW0-Δ) is a unified world–action model that learns from robot and human demonstrations. It combines pretrained video dynamics, a frozen vision-language model, and training-only 4D supervision to generate robot actions.”
- What it controls
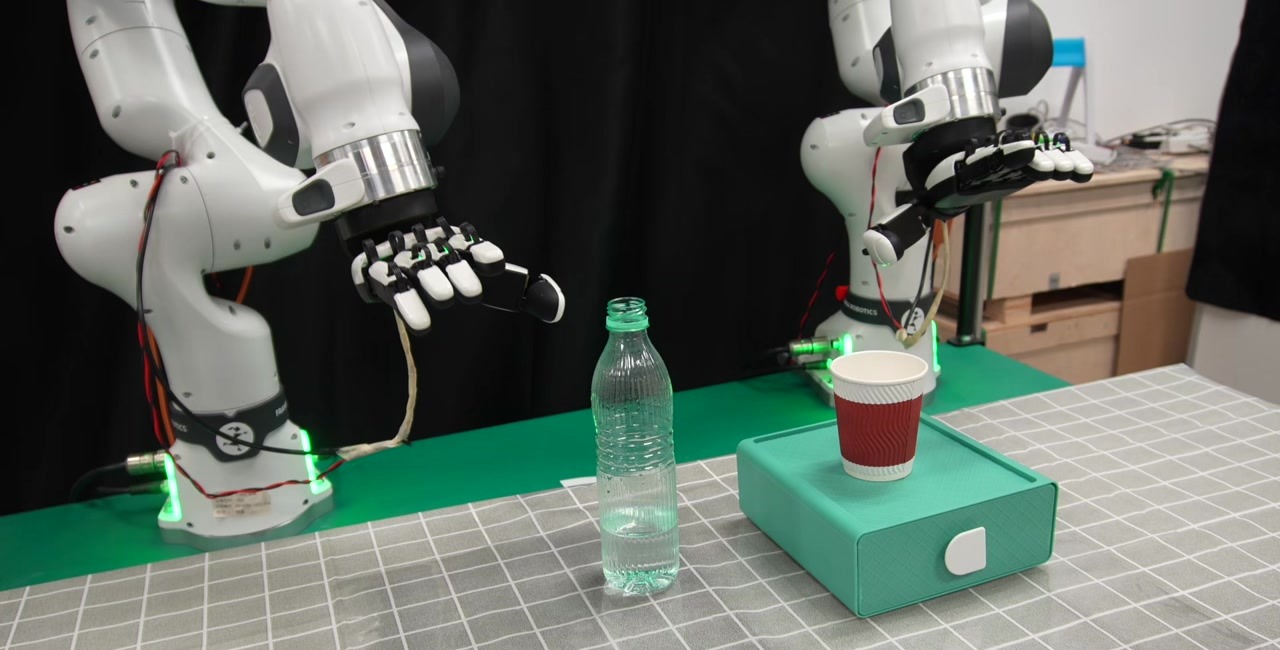
- Arms and handsSource and note: What it controlsA arxiv.org/html/2609.31394 · Retrieved 2 November 2026Note. Technical report, dexterous-hand setup: “Franka+XHand uses 6-dimensional end-effector commands per Franka arm together with 12-dimensional dexterous hand commands per hand”. The gripper setups use arm joint or end-effector targets.
- Inputs
- Camera Language Robot stateSource and note: InputsA arxiv.org/html/2609.31394 · Retrieved 2 November 2026Note. Technical report: “A frozen Wan VAE encodes sparse visual memory comprising anchor (A), recent (R), and current (C) observations”; “T5 instruction embeddings condition the video expert”; “current proprioception is independently projected for both experts”.
- Access
- Open weights (download)Source and note: AccessB github.com/InternRobotics/InternW0-Delta/blob/main/docs/models.md · Retrieved 2 November 2026Note. Model guide, public Hugging Face repositories for the pretrained and task checkpoints: “Download the policy for your task and the required backbone files below.”
- Base model
- Wan2.2-TI2V-5BSource and note: Base modelA arxiv.org/html/2609.31394 · Retrieved 2 November 2026Note. Technical report: “The video expert model is initialized using Wan2.2-TI2V-5B”. The frozen vision-language model: “The visual language encoder is initialized using RynnBrain1.1-2B”.
- Licence type
- Free, commercial useSource and note: Licence typeD huggingface.co/InternRobotics/InternW0-Delta-Base · Retrieved 2 November 2026Note. Model card header: “license: apache-2.0”.
Specifications
11/14 specifications disclosed 3 not stated
0 fields hidden 3 not-stated fields with a note stay ·
How to read the figuresShow guideClose
Not statedThe developer publishes nothing on itYesThe developer says it does
Select a source marker for source details and notes.
Release1/1 disclosed
Released25 September 2026
Source and note: ReleasedE arxiv.org/abs/2609.31394 · Retrieved 2 November 2026Note. [A] “Fri, 25 Sep 2026 15:24:25 UTC”
Input and output3/4 disclosed
Model typeWorld action model
Source and note: Model typeC github.com/InternRobotics/InternW0-Delta · Retrieved 2 November 2026Note. GitHub README: “InternW0-delta (InternW0-Δ) is a unified world–action model that learns from robot and human demonstrations. It combines pretrained video dynamics, a frozen vision-language model, and training-only 4D supervision to generate robot actions.”
InputsCamera Language Robot state
Source and note: InputsA arxiv.org/html/2609.31394 · Retrieved 2 November 2026Note. Technical report: “A frozen Wan VAE encodes sparse visual memory comprising anchor (A), recent (R), and current (C) observations”; “T5 instruction embeddings condition the video expert”; “current proprioception is independently projected for both experts”.
What it controlsArms and hands
Source and note: What it controlsA arxiv.org/html/2609.31394 · Retrieved 2 November 2026Note. Technical report, dexterous-hand setup: “Franka+XHand uses 6-dimensional end-effector commands per Franka arm together with 12-dimensional dexterous hand commands per hand”. The gripper setups use arm joint or end-effector targets.
Degrees of freedom controlledNot stated
Source and note: Degrees of freedom controlledA arxiv.org/html/2609.31394 · Retrieved 2 November 2026Note. The report states a shared action vector, not the joints of one robot: “all robot actions are mapped into a shared 80-dimensional action space”.
Size and speed1/2 disclosed
ParametersNot stated
Source and note: ParametersA arxiv.org/html/2609.31394 · Retrieved 2 November 2026Note. The report gives no total parameter count; it names the video expert: “The pretrained Wan2.2-TI2V-5B video expert and the ActionDiT action expert are coupled through 30 directed Mixture-of-Transformers (MoT) blocks”.
Control rate30Hz
Source and note: Control rateA arxiv.org/html/2609.31394 · Retrieved 2 November 2026Note. Action execution on the real robot (deployment setup): “a single NVIDIA RTX 5090 GPU with 32 GiB of memory and a control rate of 30 Hz”. Model round trip: “average controller-observed round-trip latency of 152.8 ms on a single NVIDIA RTX 5090 GPU”.
Where it runs and what it is built on1/2 disclosed
On robot or cloudNot stated
Source and note: On robot or cloudA arxiv.org/html/2609.31394 · Retrieved 2 November 2026Note. The report names the GPU used for inference, not where it sits relative to the robot: “a single NVIDIA RTX 5090 GPU with 32 GiB of memory and a control rate of 30 Hz”.
Base modelWan2.2-TI2V-5B
Source and note: Base modelA arxiv.org/html/2609.31394 · Retrieved 2 November 2026Note. Technical report: “The video expert model is initialized using Wan2.2-TI2V-5B”. The frozen vision-language model: “The visual language encoder is initialized using RynnBrain1.1-2B”.
Openness3/3 disclosed
AccessOpen weights (download)
Source and note: AccessB github.com/InternRobotics/InternW0-Delta/blob/main/docs/models.md · Retrieved 2 November 2026Note. Model guide, public Hugging Face repositories for the pretrained and task checkpoints: “Download the policy for your task and the required backbone files below.”
Licence documentApache 2.0
Source and note: Licence documentD huggingface.co/InternRobotics/InternW0-Delta-Base · Retrieved 2 November 2026Note. Model card header of the weights: “license: apache-2.0”. Code: “The code is released under the MIT License.”
Licence typeFree, commercial use
Source and note: Licence typeD huggingface.co/InternRobotics/InternW0-Delta-Base · Retrieved 2 November 2026Note. Model card header: “license: apache-2.0”.
The developer’s own claims2/2 disclosed
Learns new tasksNeeds retraining
Source and note: Learns new tasksA arxiv.org/html/2609.31394 · Retrieved 2 November 2026Note. Developer claim: the pretrained model “then adapts the resulting checkpoint to target embodiments and tasks through post-training”.
Works across robotsYes
Source and note: Works across robotsA arxiv.org/html/2609.31394 · Retrieved 2 November 2026Note. Developer claim: “The same pretrained checkpoint is post-trained separately for the gripper-based and dexterous hands interfaces.”Yes only if the developer itself says the model runs on different robot models, for example robots from two manufacturers or two of one manufacturer’s models. Several units of the same robot do not count.
Notes
The InternW0-Δ paper places the model in the same InternW series as InternW0.
The InternW0-Δ technical report was submitted to arXiv on 25 September 2026.
Sources
One line per source, not per figure: a source has one retrieval date.
- Aarxiv.org/html/2609.31394Retrieved 2 November 2026
- Bgithub.com/InternRobotics/InternW0-Delta/blob/main/docs/models.mdRetrieved 2 November 2026
- Cgithub.com/InternRobotics/InternW0-DeltaRetrieved 2 November 2026
- Dhuggingface.co/InternRobotics/InternW0-Delta-BaseRetrieved 2 November 2026
- Earxiv.org/abs/2609.31394Retrieved 2 November 2026