SCalf
A quadruped robot from China, first released 2010.
Sources retrieved: 6 September 2026 (A)
- Status
- Discontinued
- Applications
- Indicative price
- Not stated
- Intended use, per the manufacturer
- Hydraulic quadruped locomotion-control research platform; results on omnidirectional motion control, gait planning and moving-target estimation were later used as a reference by other Chinese research groups.Source and note: Intended use, per the manufacturerA sohu.com/a/429444355_120472831 · Retrieved 6 September 2026
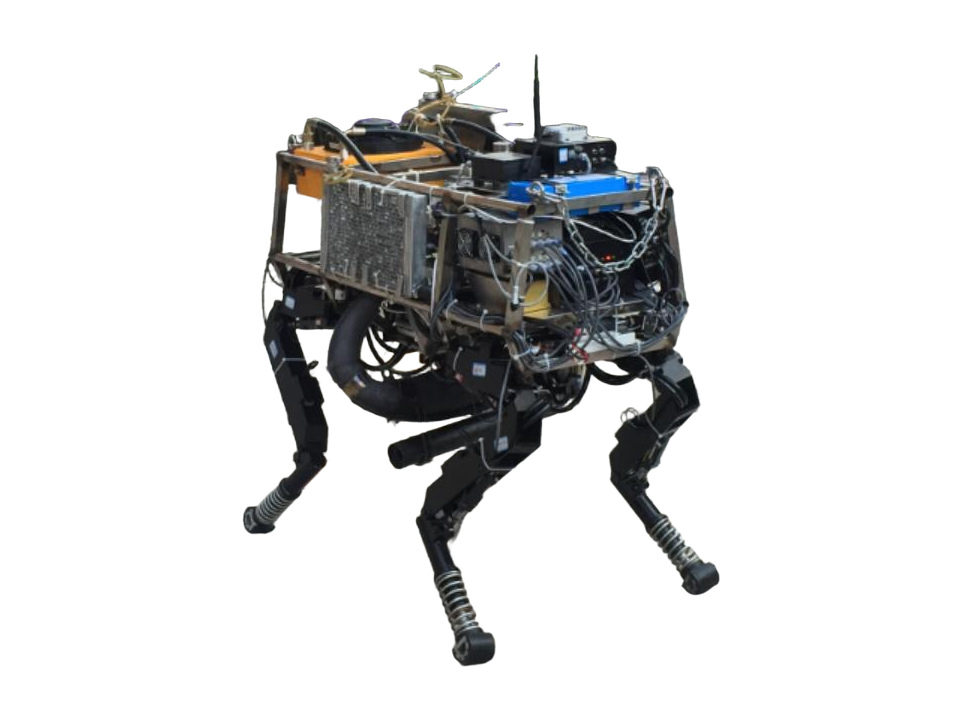
Manufacturer's own photo.
Specifications
2/33 specifications disclosed 31 not stated
31 fields hidden
Not statedThe manufacturer states nothing about this field.NoStated: the robot does not have this.A marker with an asterisk (*) also carries a caveat.
Select a source marker for source details and notes.
Physical2/14 disclosed
Power0/5 disclosed
Sensing and autonomy0/6 disclosed
Payload and expansion0/3 disclosed
Commercial0/1 disclosed
Compliance & certifications0/4 disclosed
Against the field
Each strip holds every robot of this type in the guide that states the figure, one bar per group of values. Further right means a larger figure, not a better robot.
Degrees of freedom
12DoF
76 quadrupeds state degrees of freedom
15 state a higher figure, 4 a lower one. 56 more state exactly the same figure.
Max speed
approximately 4.32km/happroximately 2.68mphOur conversion from 1.2 m/s. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
113 quadrupeds state a top speed
77 state a higher figure, 7 a lower one. 1 more states exactly the same figure.
Notes
SCalf-1 was the first Chinese hydraulic quadruped robot to achieve high-speed trot-gait walking, using an external hydraulic power station.
Developed at Shandong University's Center for Robotics; the work was later published in the journal ROBOT, and the same group founded Shandong Youbaote Intelligent Robot Co.
Sources
One line per source, not per figure: a source has one retrieval date.
- Asohu.com/a/429444355_120472831Secondary. Retrieved 6 September 2026