National University of Singapore · robot AI model
OpenWAM-α
Singapore · 2026
Sources retrieved: 2 November 2026 (A, B, C, D)
- Model type
- World action modelSource and note: Model typeB github.com/OpenWAM-Official/OpenWAM · Retrieved 2 November 2026Note. Developer wording: “An open pretrained WAM that applies these principles at scale”.
- What it controls
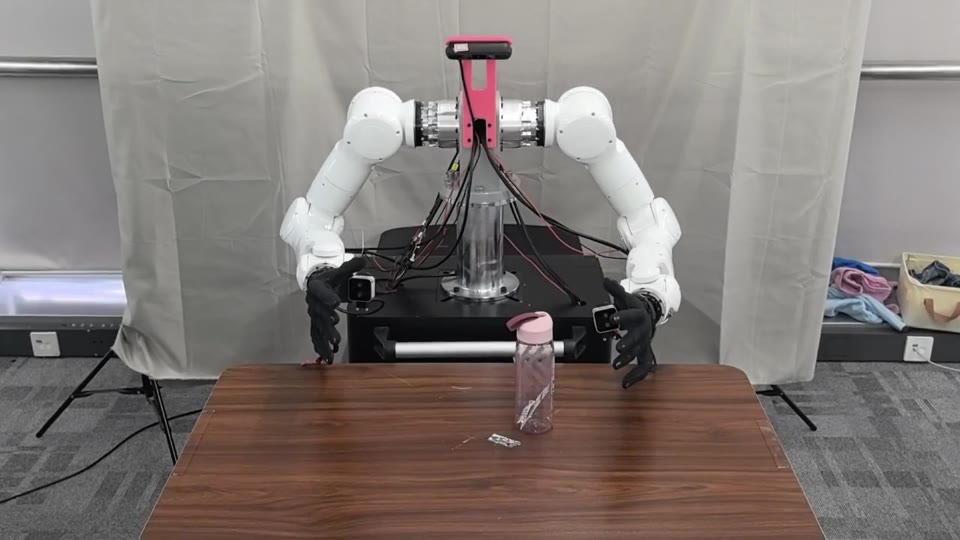
- Arms and handsSource and note: What it controlsA arxiv.org/pdf/2609.07398 · Retrieved 2 November 2026Note. The action vector: “an 80-dimensional vector with fixed slot semantics, comprising two mirrored 34-D arm blocks”, each with end-effector pose, gripper and a dexterous hand.
- Inputs
- Camera Language Robot stateSource and note: InputsA arxiv.org/pdf/2609.07398 · Retrieved 2 November 2026Note. Technical report: “all camera views tiled into one canvas”; “the robot state at the start of the window supplies the proprioception token”. Language: “Maps the instruction into a 4096-dim context that both streams consume through their own cross-attention”.
- Access
- Open weights (download)Source and note: AccessB github.com/OpenWAM-Official/OpenWAM · Retrieved 2 November 2026Note. Developer wording: “[2026/09/06] 🤗 We release all pretrained and finetuned models on huggingface”.
- Base model
- Wan2.2-TI2V-5BSource and note: Base modelC huggingface.co/OpenWAM/OpenWAM-Alpha-Pretrain-Foundation-Model · Retrieved 2 November 2026Note. Model card: “a Wan2.2-TI2V-5B video backbone with its native Wan-VAE encoder”.
- Licence type
- Free, commercial useSource and note: Licence typeD openwam-official.github.io · Retrieved 2 November 2026Note. Developer wording: “We release the full stack: infrastructure, evaluation protocols, pretrained models, and data recipes”.
Specifications
10/14 specifications disclosed 4 not stated
2 fields hidden 2 not-stated fields with a note stay ·
How to read the figuresShow guideClose
Not statedThe developer publishes nothing on itYesThe developer says it does
Select a source marker for source details and notes.
Release1/1 disclosed
Input and output3/4 disclosed
Size and speed0/2 disclosed
Where it runs and what it is built on1/2 disclosed
Openness3/3 disclosed
The developer’s own claims2/2 disclosed
Notes
OpenWAM-α is the pretrained model of the OpenWAM research stack, written by authors from seven universities, the first of them the National University of Singapore.
The OpenWAM project released its code and models on 6 September 2026.
The OpenWAM Hugging Face organisation lists 46 models: the pretrained foundation model and checkpoints fine-tuned for single benchmarks and robots.
Sources
One line per source, not per figure: a source has one retrieval date.
- Aarxiv.org/pdf/2609.07398Retrieved 2 November 2026
- Bgithub.com/OpenWAM-Official/OpenWAMRetrieved 2 November 2026
- Chuggingface.co/OpenWAM/OpenWAM-Alpha-Pretrain-Foundation-ModelRetrieved 2 November 2026
- Dopenwam-official.github.ioMain source. Retrieved 2 November 2026