Key figures as stated by the manufacturer
0 of 6 stated · 6 gapsDemonstratorThe manufacturer states none of the 6 key figures.
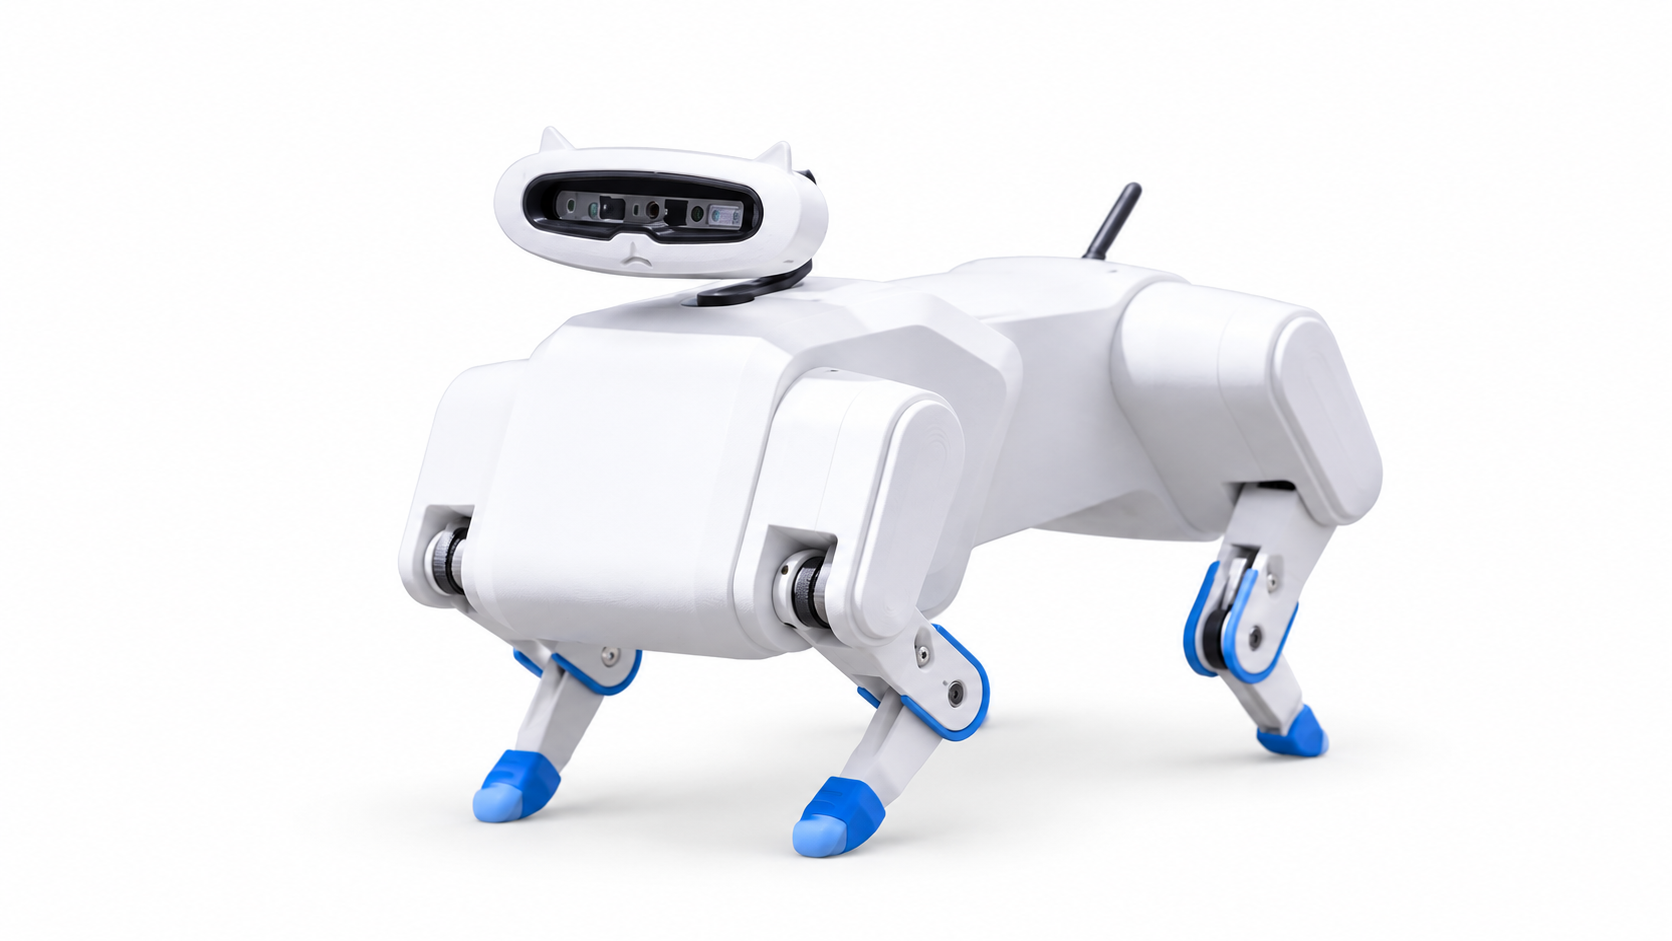
Manufacturer's own photo.
Intended use, per the manufacturer
The manufacturer’s words
The four-legged robotic system Bert is a platform for researching biological locomotion. The purpose of the system is to understand locomotor patterns and transfer them from nature to robotic systems... working towards a highly mobile, legged exploration robot.
Source: dlr.de · Retrieved
This category is not our assessment.
Every field in the schema
1 of 33 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | not stated | |
| Length | not stated | |
| Width | not stated | |
| Height | not stated | |
| Degrees of freedom | 12DoF | A NoteFour-legged platform with serial-elastic actuated joints (3 DoF per leg). |
| Payload, walking | not stated | |
| Payload, standing | not stated | |
| Max speed | not stated | |
| Max slope | not stated | |
| Single obstacle | not stated | |
| Stair step, continuous | not stated | |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | |
| Runtime | not stated | |
| Hot-swap battery | not stated | |
| Charge time | not stated | |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | not stated | |
| Cameras | not stated | |
| Onboard compute | not stated | |
| ROS 2 | not stated | |
| SDK languages | not stated | |
| Autonomy level | not stated | |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | |
| Data ports | not stated | |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Stair step and payload each exist in two variants. Only compare fields with the same label.
Notes
- A four-legged research platform from the Institute of Robotics and Mechatronics at the German Aerospace Center (DLR).
- Built for biological locomotion research and planetary exploration, using serial-elastic joints and energy-efficient gaits; demonstrated in the Surface Avatar space missions.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for Berthttps://www.dlr.de/en/rm/research/robotic-systems/legged
Sources
- A Manufacturer product page. www.dlr.de/en/rm/research/robotic-systems/legged · Retrieved
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.