Magneto
A quadruped robot from Australia, first released 2018.
Sources retrieved: 6 September 2026 (A)
- Status
- Demonstrator
- Applications
- Indicative price
- Not stated
- Intended use, per the manufacturer
- Magneto represents the next generation of maintenance and inspection robots that can minimise risk and increase safety in the industrial workforce, particularly around confined space entry.Source and note: Intended use, per the manufacturerA csiro.au/en/research/technology-space/robotics/magneto · Retrieved 6 September 2026
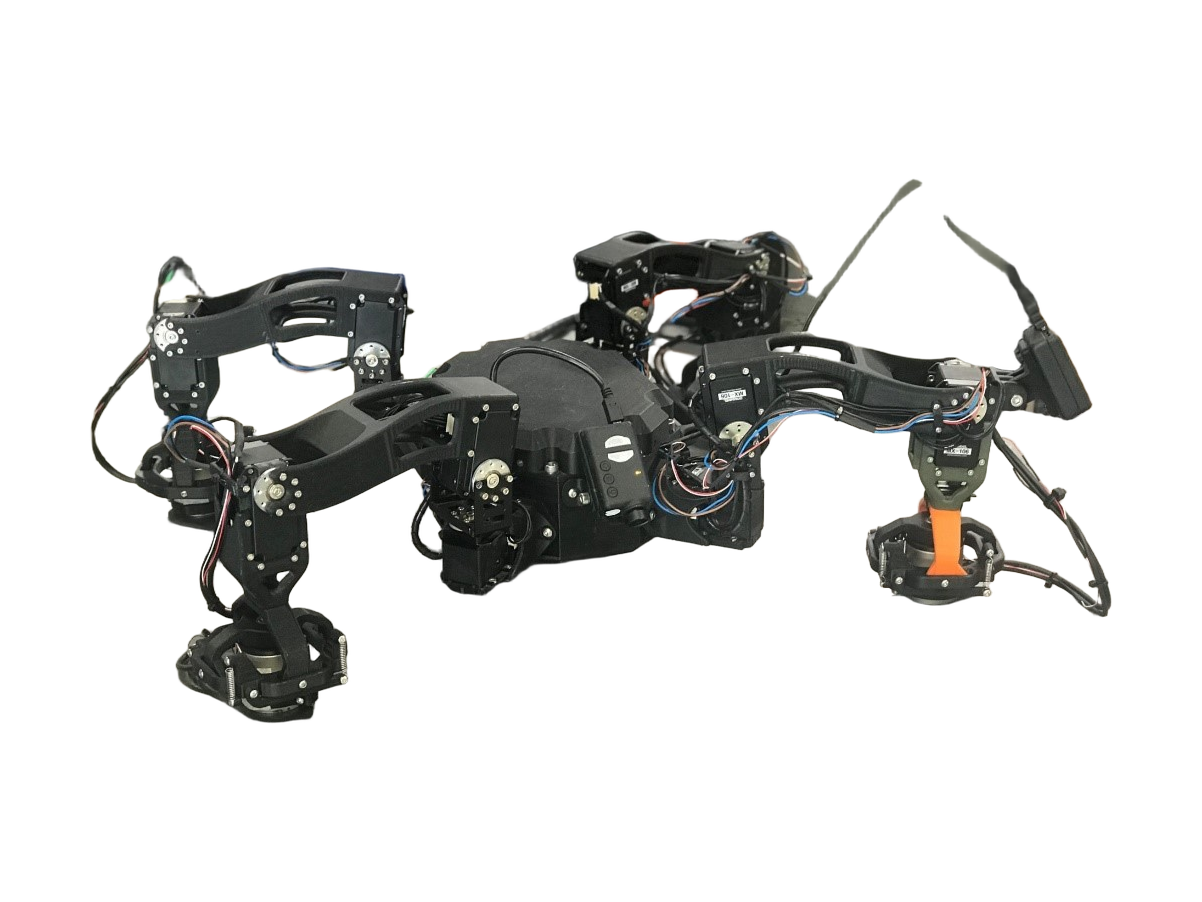
Manufacturer's own photo.
Specifications
1/33 specifications disclosed 32 not stated
32 fields hidden
Not statedThe manufacturer states nothing about this field.NoStated: the robot does not have this.A marker with an asterisk (*) also carries a caveat.
Select a source marker for source details and notes.
Physical0/14 disclosed
Power0/5 disclosed
Sensing and autonomy1/6 disclosed
Payload and expansion0/3 disclosed
Commercial0/1 disclosed
Compliance & certifications0/4 disclosed
Notes
A climbing/inspection robot with permanent electromagnetic feet from CSIRO's Data61, first published at IROS 2018; commercialized with Nexxis, and won an award at the 2019 Sprint Robotics Conference.
Sources disagree on its joint count: the original paper describes 3-DOF limbs plus a compliant magnetic foot, while Nexxis' own page separately says 'five degrees of freedom' overall.
Sources
One line per source, not per figure: a source has one retrieval date.
- Acsiro.au/en/research/technology-space/robotics/magnetoMain source. Retrieved 6 September 2026